Related Experiment Video
Updated: Aug 3, 2025

A Robotic Platform to Study the Foreflipper of the California Sea Lion
Published on: January 10, 2017
A versatile jellyfish-like robotic platform for effective underwater propulsion and manipulation
Tianlu Wang1,2, Hyeong-Joon Joo3, Shanyuan Song1,4
1Physical Intelligence Department, Max Planck Institute for Intelligent Systems, Stuttgart 70569, Germany.

Abstract:
Underwater devices are critical for environmental applications. However, existing prototypes typically use bulky, noisy actuators and limited configurations. Consequently, they struggle to ensure noise-free and gentle interactions with underwater species when realizing practical functions. Therefore, we developed a jellyfish-like robotic platform enabled by a synergy of electrohydraulic actuators and a hybrid structure of rigid and soft components. Our 16-cm-diameter noise-free prototype could control the fluid flow to propel while manipulating objects to be kept beneath its body without physical contact, thereby enabling safer interactions. Its against-gravity speed was up to 6.1 cm/s, substantially quicker than other examples in literature, while only requiring a low input power of around 100 mW. Moreover, using the platform, we demonstrated contact-based object manipulation, fluidic mixing, shape adaptation, steering, wireless swimming, and cooperation of two to three robots. This study introduces a versatile jellyfish-like robotic platform with a wide range of functions for diverse applications.
Related Concept Videos
 01:11
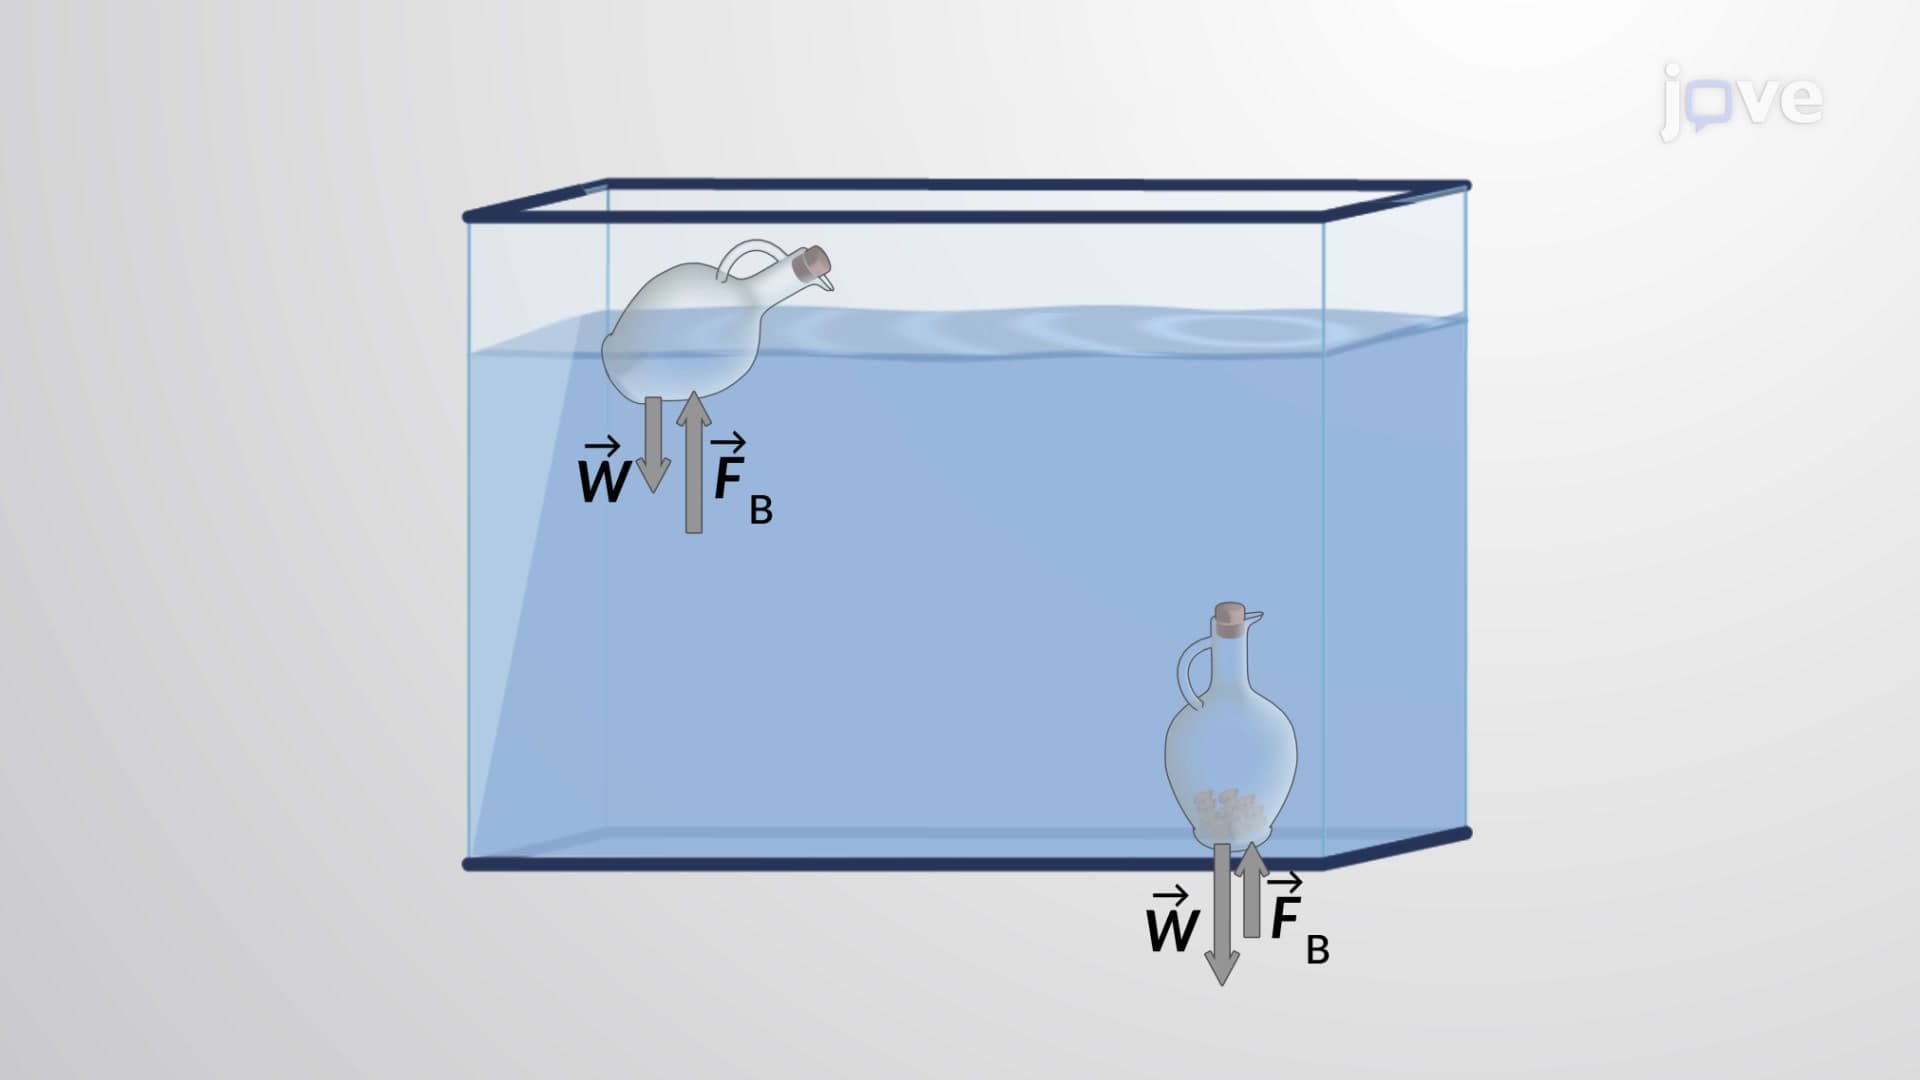
Buoyancy and Stability for Submerged and Floating Bodies
 00:59
Buoyancy
 01:39
Mechanism of Filopodia Formation
Their main function is to guide migrating cells during normal tissue morphogenesis or cancer metastasis by recognizing and making initial contacts with the extracellular matrix. However, they can also act as stationary cell anchors or help to establish communication...
 01:23
Surface Appendages of Archaea
 01:16
Cell Motility through Blebbing
Blebbing Through the Matrix
In multicellular...