Related Experiment Video
Updated: May 20, 2026
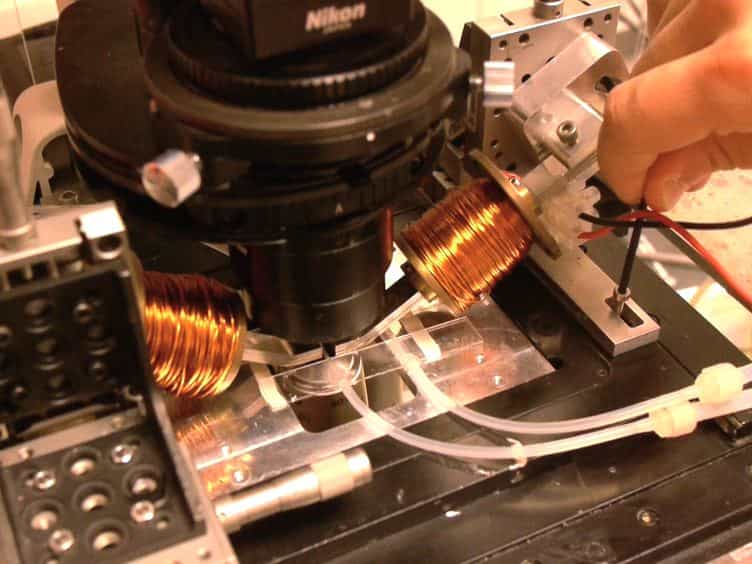

Remote Magnetic Actuation of Micrometric Probes for in situ 3D Mapping of Bacterial Biofilm Physical Properties
Published on: May 2, 2014
A Data-Driven Inverse Design Methodology for Magnetic Soft Millirobots Navigating in Confined Spaces
Ziyu Ren1, Hong Wang2, Chak Wang Tse2
1School of Mechanical Engineering and Automation, Beihang University, Beijing, China.

Abstract:
Magnetic soft millirobots enable untethered locomotion in narrow environments. However, their design remains largely intuition-driven due to complex interactions among soft-body deformation, magnetic actuation, and environmental contact. Here, we propose an uncertainty-aware, data-efficient inverse design methodology tailored for contact-rich, non-smooth environments. It integrates a physics-based Cosserat rod model with Gaussian Process-based Bayesian optimization to automate robot design for confined-space crawling. To mitigate sim-to-real discrepancies, domain randomization is incorporated by explicitly modeling contact uncertainty. Channel segmentation focusing on critical geometric bottlenecks enhances efficiency and accuracy, halving optimization time and increasing R2 by nearly an order of magnitude in a serpentine channel. Optimized robots consistently outperform arbitrarily selected baseline designs, achieving stable crawling across heterogeneous conditions without failures such as coiling or jamming. When applied to coronary artery-mimicking geometries, the optimized design reached 2.66 mm/s, nearly doubling the average baseline speed of 1.42 mm/s. Validation in an artery-mimicking channel with 2.5 mm out-of-plane undulations further demonstrates the reliability of the optimization framework; notably, the optimized design maintained uninterrupted motion while 25% of baseline designs got stuck. This work establishes an uncertainty-aware inverse design methodology for task-driven magnetic soft millirobot design, paving the way toward automated design-to-deployment pipelines for real-world applications.
Related Concept Videos
 01:13
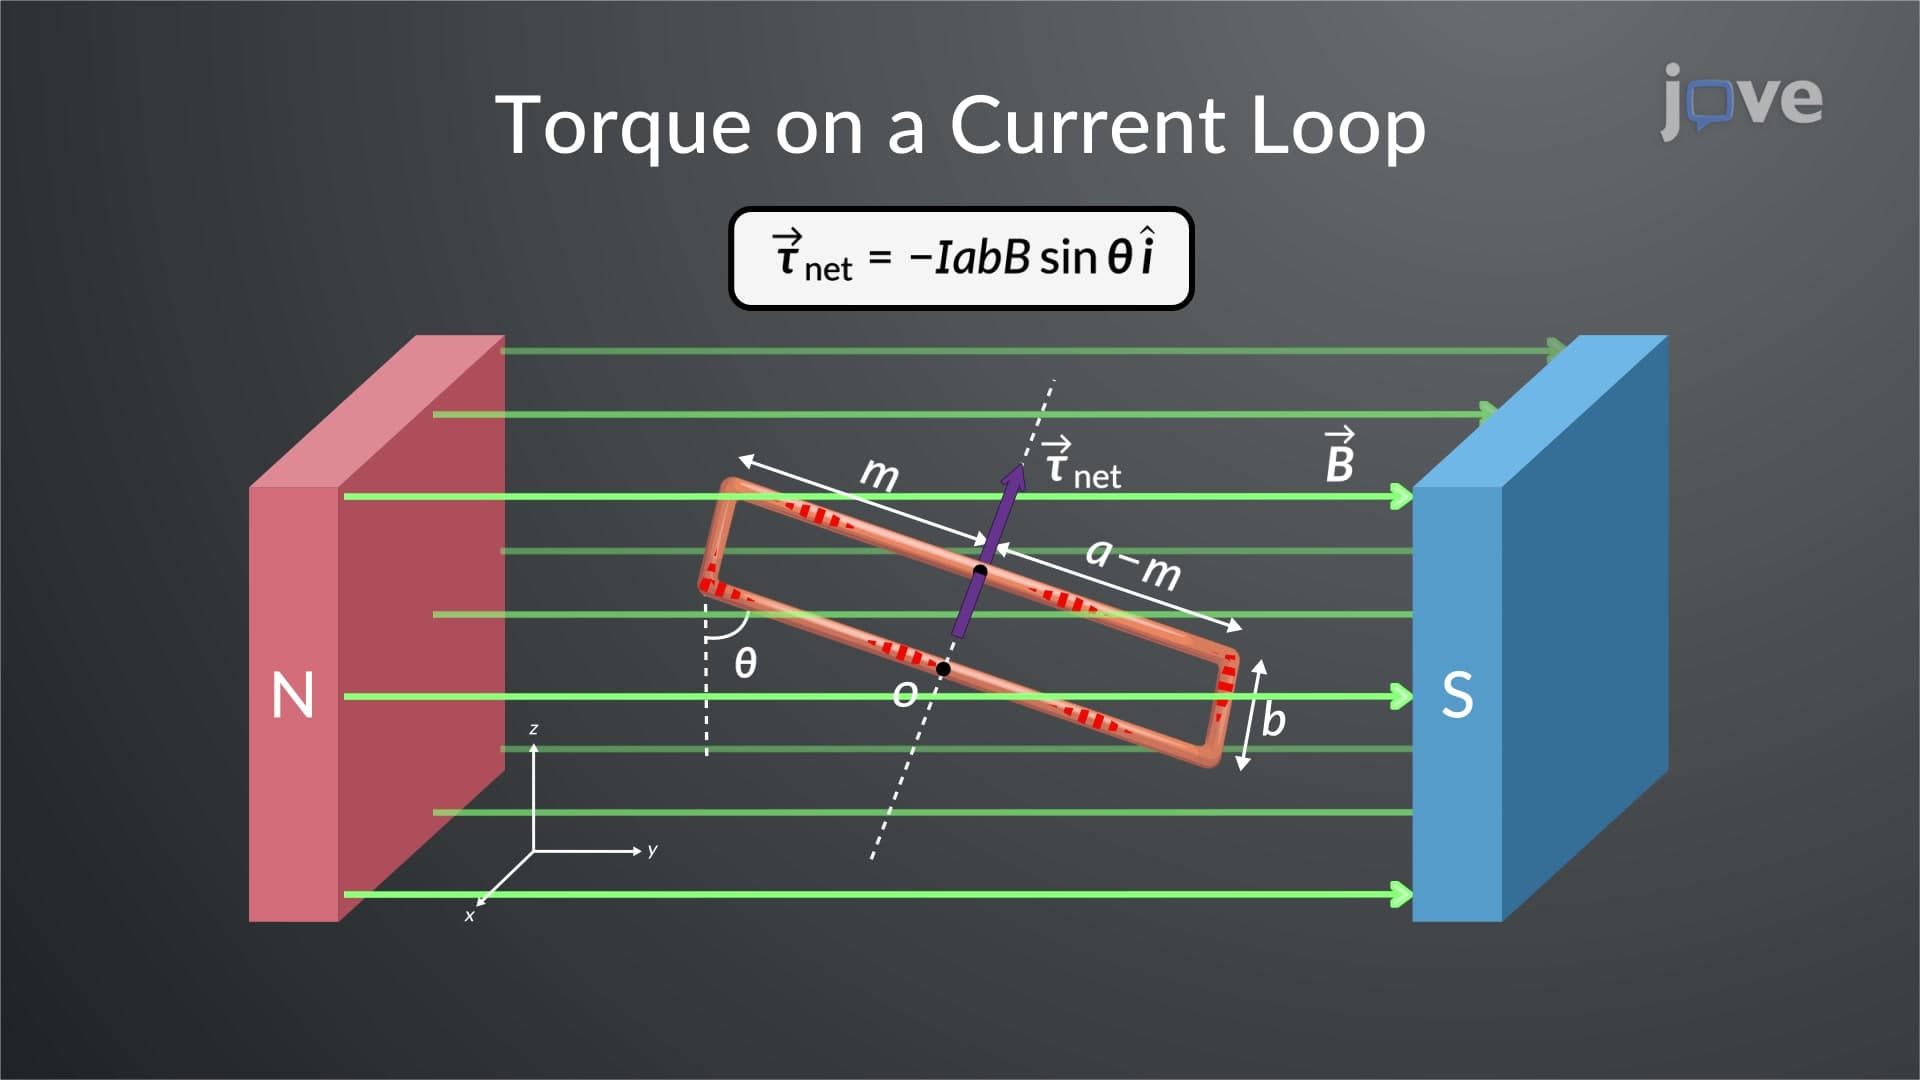
Torque On A Current Loop In A Magnetic Field
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...