Related Experiment Video
Updated: Jul 14, 2026


Rod-based Fabrication of Customizable Soft Robotic Pneumatic Gripper Devices for Delicate Tissue Manipulation
Published on: August 2, 2016
Soft and lightweight fabric enables powerful and high-range pneumatic actuation
Zhuang Zhang1,2, Yongzhou Long1, Genliang Chen1,3
1State Key Laboratory of Mechanical Systems and Vibration, and Shanghai Key Laboratory of Digital Manufacturing for Thin-Walled Structures, Shanghai Jiao Tong University, Shanghai, 200240, China.

Abstract:
Soft structures and actuation allow robots, conventionally consisting of rigid components, to perform more compliant, adaptive interactions similar to living creatures. Although numerous functions of these types of actuators have been demonstrated in the literature, their hyperelastic designs generally suffer from limited workspaces and load-carrying capabilities primarily due to their structural stretchability factor. Here, we describe a series of pneumatic actuators based on soft but less stretchable fabric that can simultaneously perform tunable workspace and bear a high payload. The motion mode of the actuator is programmable, combinable, and predictable and is informed by rapid response to low input pressure. A robotic gripper using three fabric actuators is also presented. The gripper demonstrates a grasping force of over 150 N and a grasping range from 70 to 350 millimeters. The design concept and comprehensive guidelines presented would provide design and analysis foundations for applying less stretchable yet soft materials in soft robots to further enhance their practicality.
Related Concept Videos
 01:03
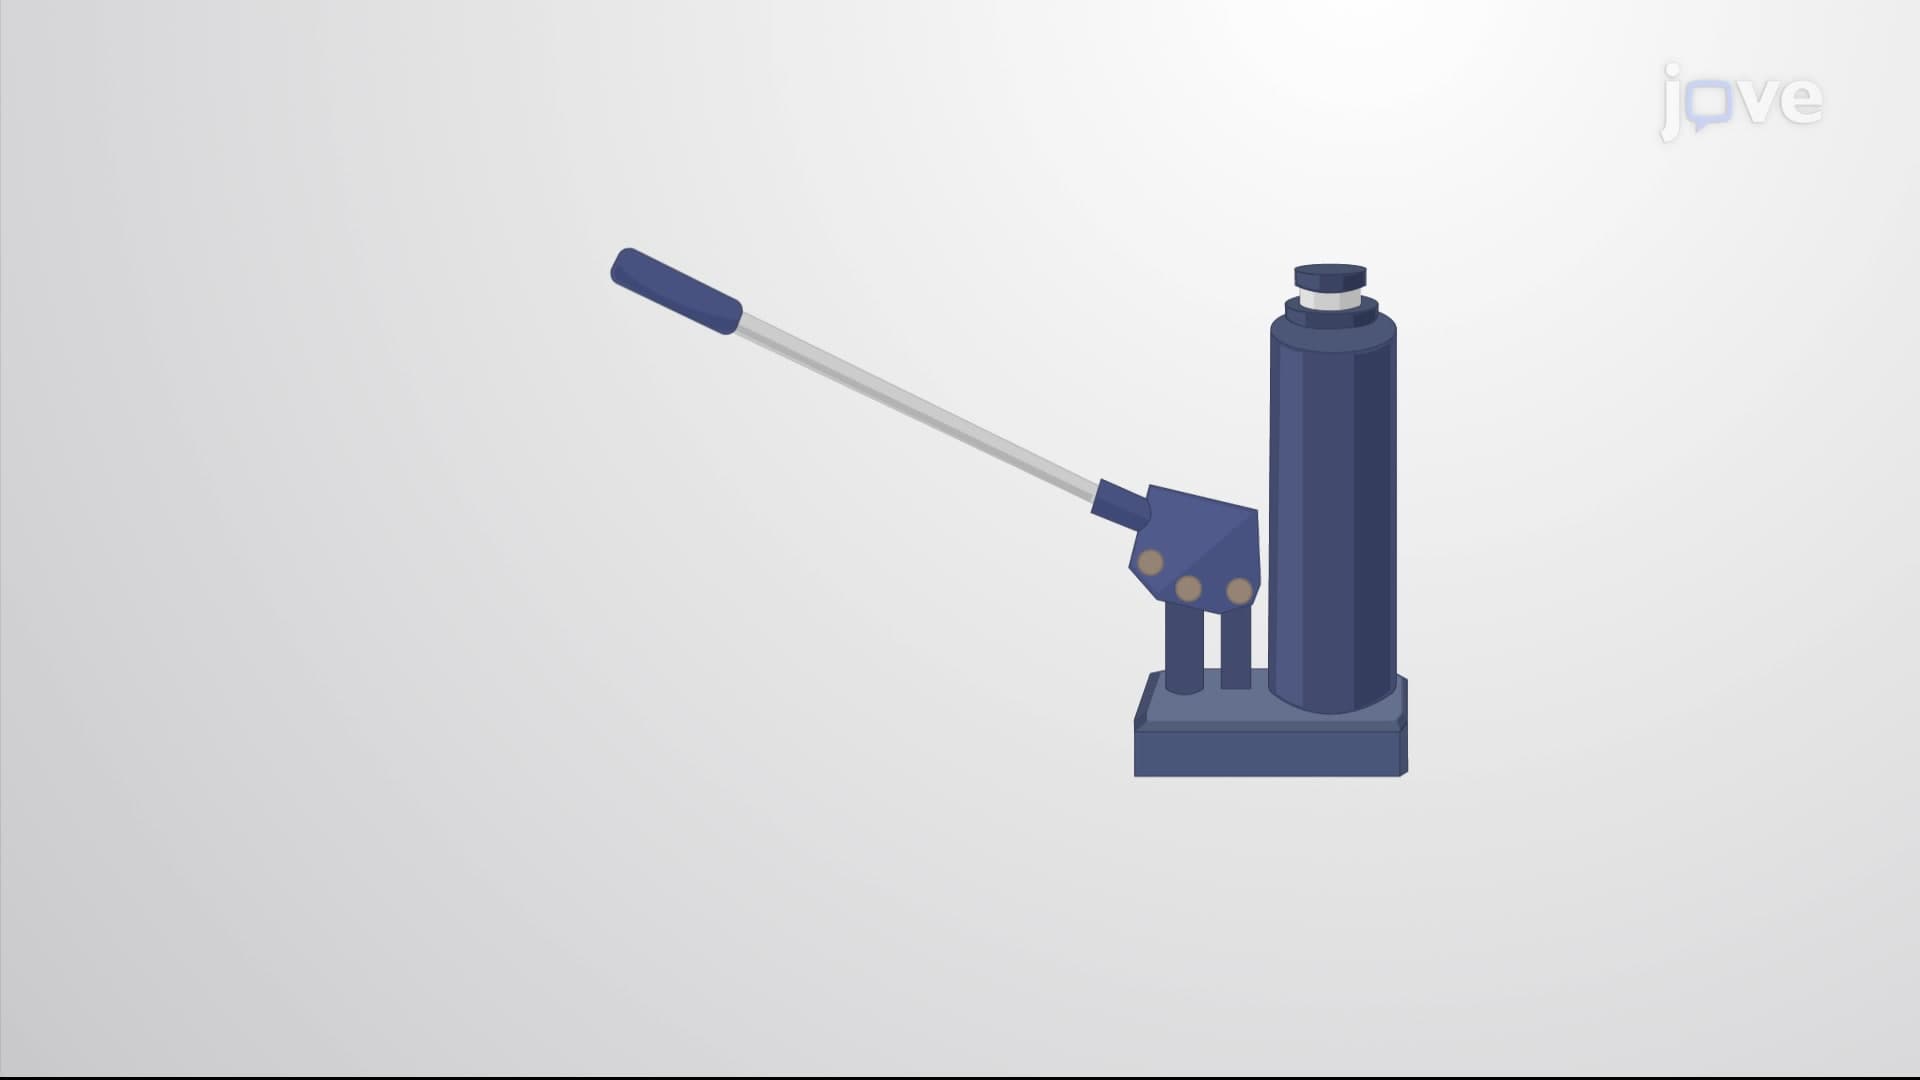
Application of Pascal's Law
Hydraulic systems are used to operate automotive brakes, hydraulic jacks, and numerous other mechanical systems. We can derive a relationship between the forces in a simple hydraulic system by applying...
 01:22
Mechanical Systems