Related Experiment Video
Updated: Aug 1, 2025

A Swin Transformer-Based Model for Thyroid Nodule Detection in Ultrasound Images
Published on: April 21, 2023
Convolutional neural network with data augmentation for object classification in automotive ultrasonic sensing
Jona Eisele1, André Gerlach1, Marcus Maeder2
1Corporate Research (CR), Robert Bosch GmbH, Robert-Bosch-Campus 1, Renningen 71272, Germany.

Abstract:
Today's low-cost automotive ultrasonic sensors perform distance measurements of obstacles within the close range of vehicles. For future parking assist systems and autonomous driving applications, the performance of the sensors should be further increased. This paper examines the processing of sensor data for the classification of different object classes and traversability of obstacles using a single ultrasonic sensor. The acquisition of raw time signals, transformation into time-frequency images, and classification using machine learning methods are described. Stationary and dynamic measurements at a velocity of 0.5 m/s of various objects have been carried out in a semi-anechoic chamber and on an asphalt parking space. We propose a scalogram-based signal processing chain and a convolutional neural network, which outperforms a LeNet-5-like baseline. Additionally, several methods for offline and online data augmentation are presented and evaluated. It is shown that carefully selected augmentation methods are useful to train more robust models. Accuracies of 90.1% are achieved for the classification of seven object classes in the laboratory and 66.4% in the outdoor environment. Traversability is correctly classified at an accuracy of 96.4% and 91.5%, respectively.

Related Concept Videos
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 01:30
Classification of Signals
A continuous-time signal holds a value at every instant in time, representing information seamlessly. In contrast, a discrete-time signal holds values only at specific moments, often denoted as x(n), where...
 01:31
Classification of Systems-II
 01:24
Imaging Studies II: Ultrasonography
 01:26
Classification of Systems-I
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
 01:17
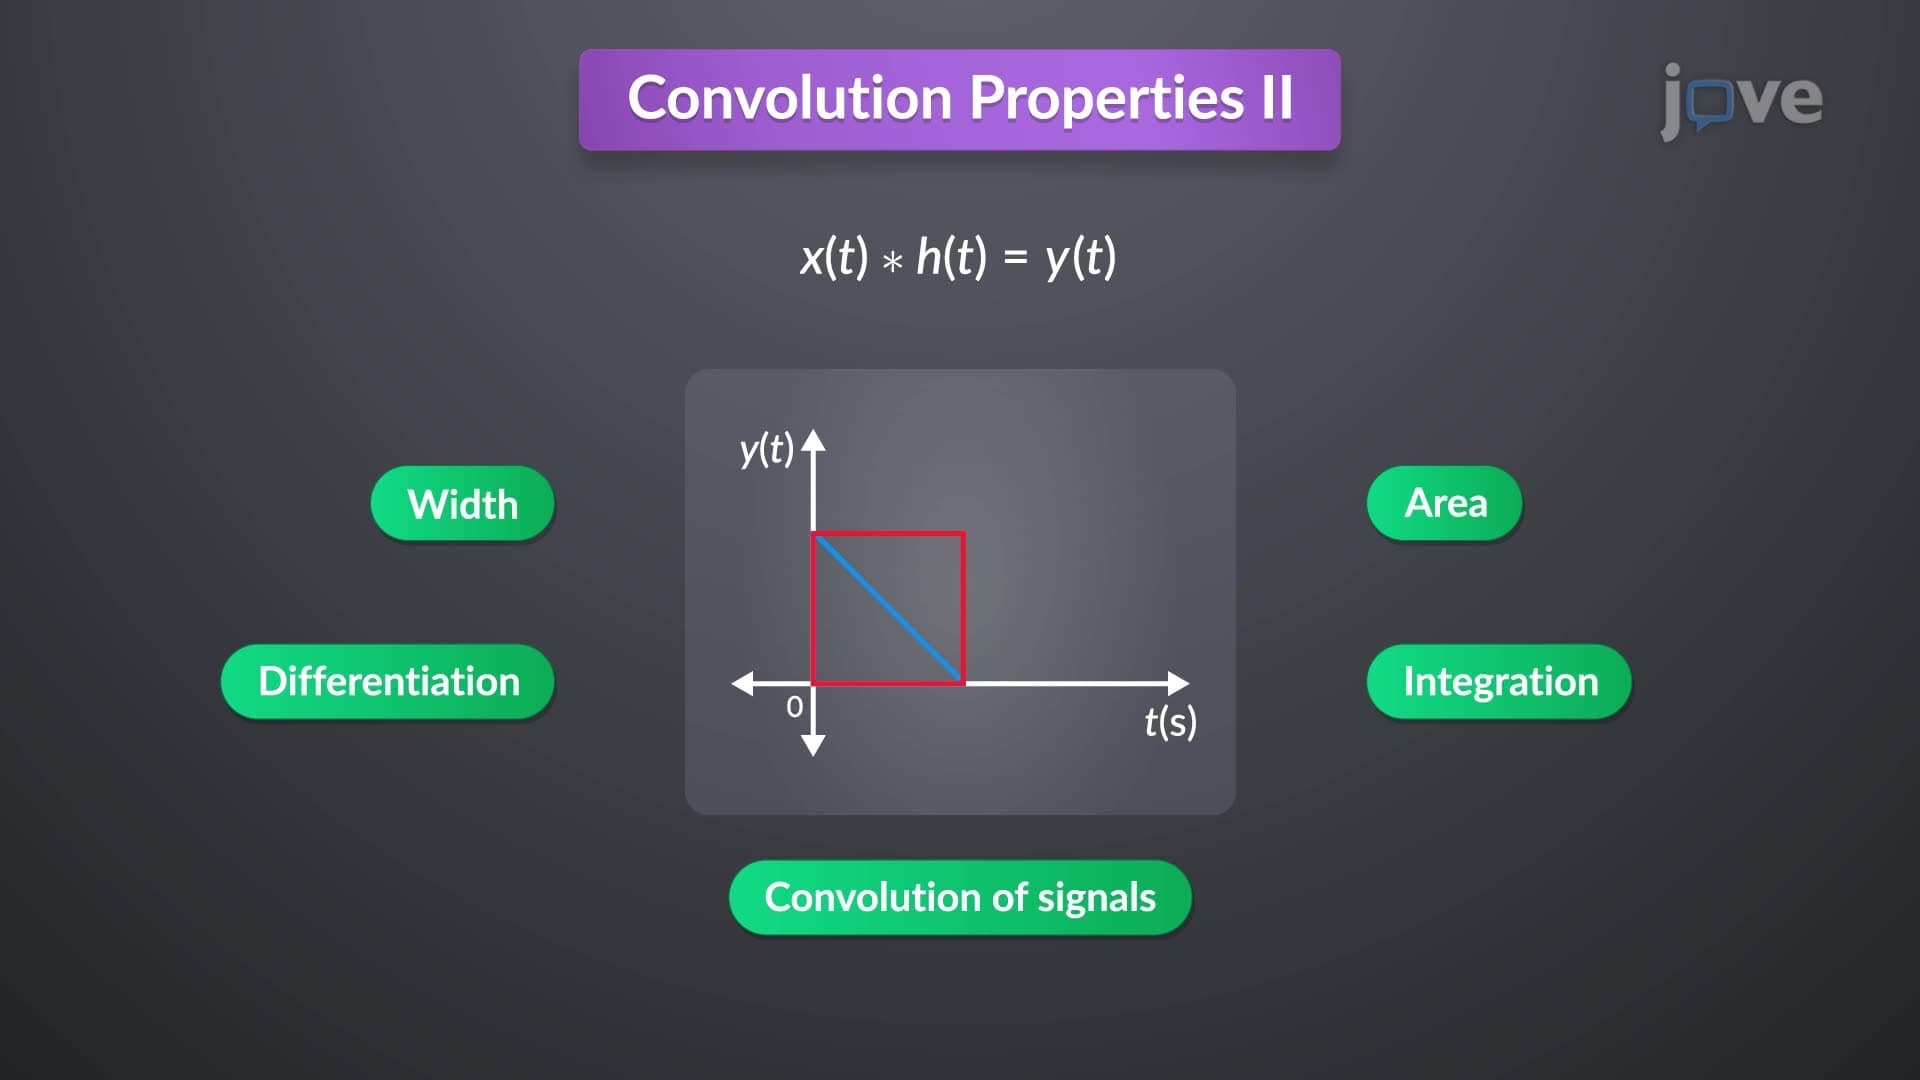
Convolution Properties II
The width property indicates that if the durations of input signals are T1 and T2, then the width of the output response equals the sum of both durations, irrespective of the shapes of the two functions. For instance, convolving two rectangular pulses with durations of 2 seconds and 1 second results in a function with a width of 3 seconds.
The area property asserts that the area under the...