Related Experiment Video
Updated: Aug 1, 2025

Author Spotlight: Efficient Image Recognition Using Directional Gradient Histogram Technique and Support Vector Machines
Published on: January 5, 2024
Predicting Sliding Angles on Random Pit-Distributed Textures Using Probabilistic Neural Networks
Li Wang1,2, Haidou Wang1,3, Yuelan Di2
1College of Materials Science and Chemical Engineering, Harbin Engineering University, Harbin 150090, Heilongjiang, China.

Abstract:
The three-phase contact line best reflects the sliding ability of droplets on solid surfaces. Most studies on the sliding angle (SA) of superhydrophobic surfaces are limited to regularly arranged microtextured surfaces, lacking definite models and effective methods for a complex surface of a random texture. In this study, random pits with an area ratio of 19% were generated on 1 mm × 1 mm subregions, and the subregions formed arrays on a sample surface of 10 mm × 10 mm to obtain a randomly distributed microtexture surface with no pit overlaps. Although the contact angle (CA) of randomly pitted texture was the same, the SA was different. The SA of surfaces was affected by the pit location. The location of random pits increased the complexity of the three-phase contact line movement. The continuity of the three-phase contact angle (T) can reveal the rolling mechanism of the random pit texture and predict the SA, but the relationship between the T and SA is a relatively poor linear relation (R2 = 74%), and the SA of the random pit texture can only be roughly estimated. The quantized pit coordinates and SA were used as the input and output labels for the PNN model, respectively, and the accuracy of the model convergence was 90.2%.
Related Concept Videos
 01:32
Probability Distributions
A discrete probability distribution is a probability distribution of discrete random variables. It can be categorized into binomial probability distribution and Poisson...
 01:03
Prediction Intervals
However, the point estimate is most likely not the exact value of the population parameter, but close to it. After calculating point estimates, we construct interval estimates, called confidence intervals or prediction intervals. This prediction interval comprises a range of values unlike the point estimate and is a better predictor of the observed sample value, y.
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:17
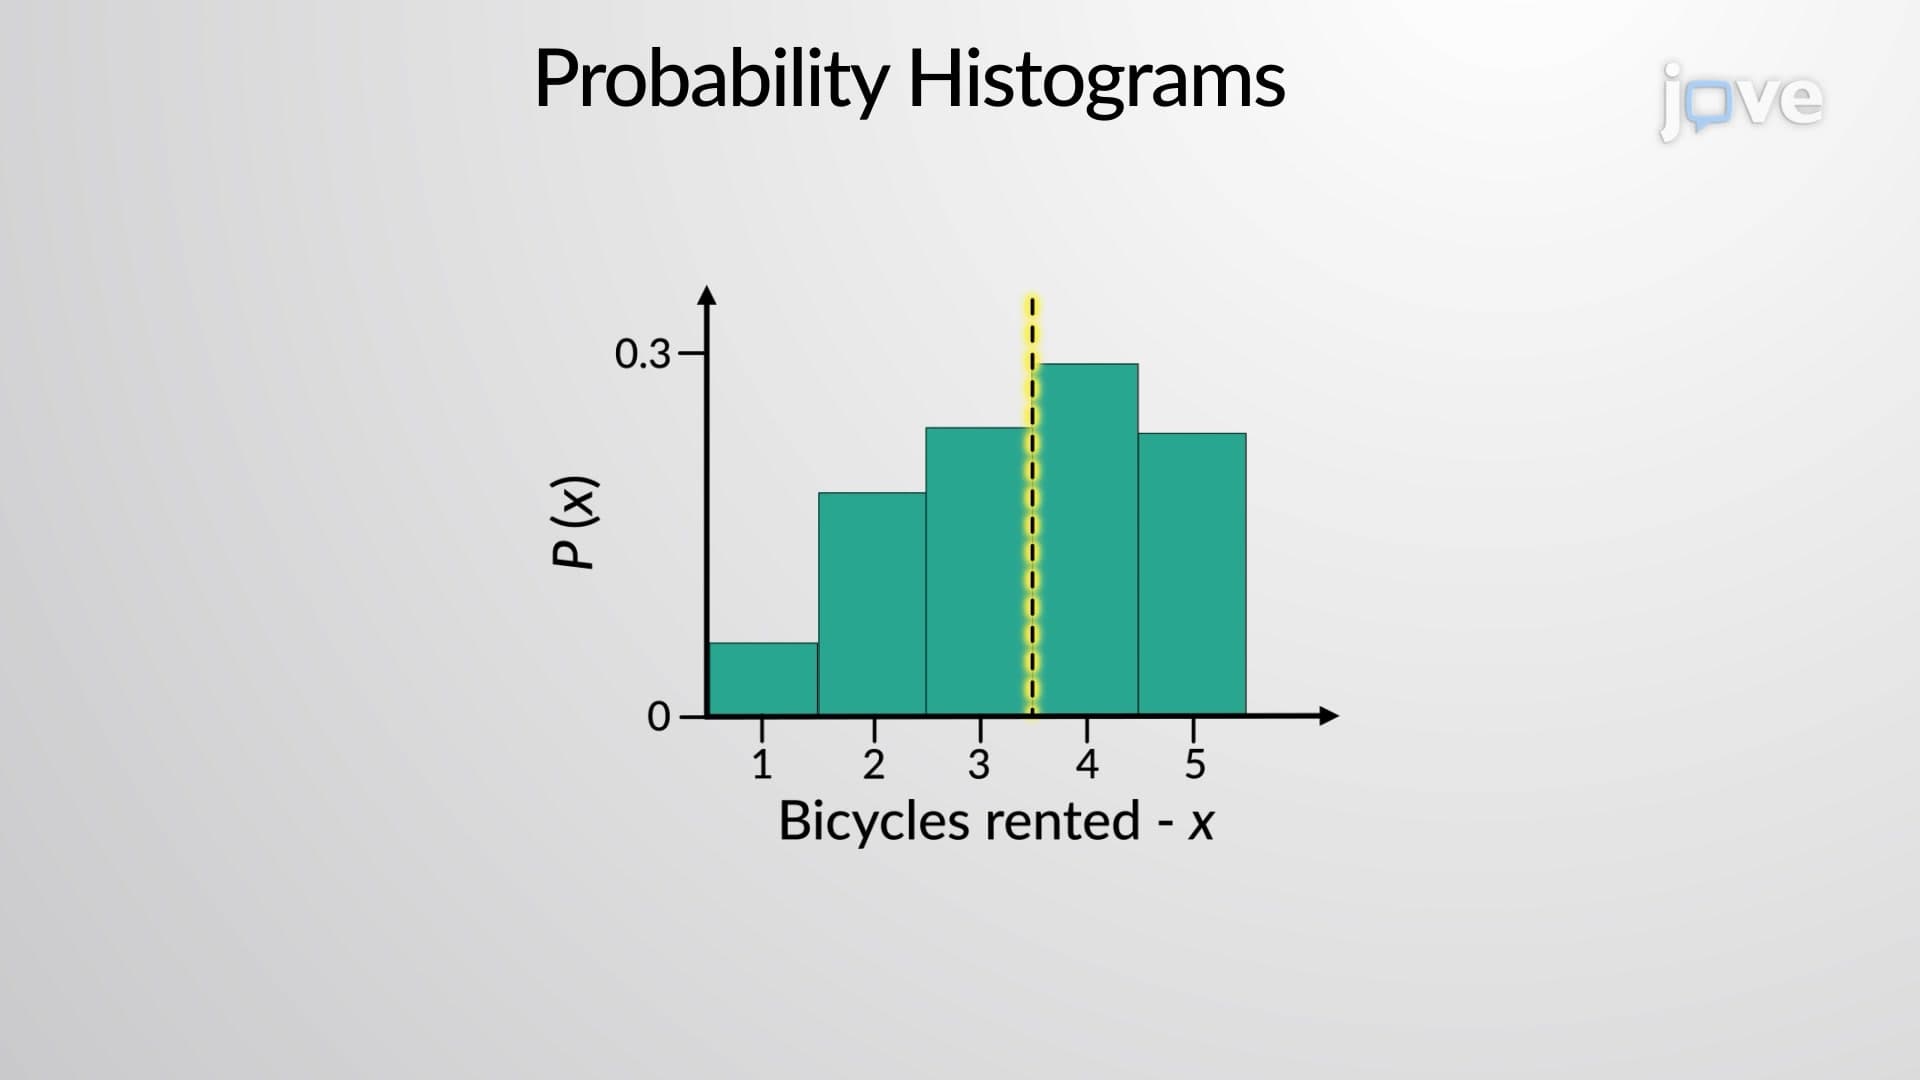
Probability Histograms
 01:25
Shape and Texture of Coarse Aggregate
 01:49
Probability Laws