Novel adaptive law for super-twisting controller: USV tracking control under disturbances

Enrique Alvaro-Mendoza1, Alejandro Gonzalez-Garcia2, Herman Castañeda3
1Department of Electrical Engineering, Facultad de Ingeniería Mecánica y Eléctrica, Universidad Autónoma de Nuevo León, San Nicolás de los Garza, Mexico.

Abstract:
A novel adaptive super-twisting control algorithm, for Unmanned Surface Vehicles (USV) tracking control is presented. The proposed adaptive law is obtained using a Lyapunov approach, to analyze the system closed-loop stability. Furthermore, several conditions are given to guarantee robustness in presence of unknown bounded disturbances/uncertainties, chattering mitigation and the finite-time convergence. This adaptive control strategy has the advantage that the controller gains, which are in terms of a single control parameter, requires adjusting a small number of parameters compared with other adaptive strategies, moreover and its dynamics is smooth, improving the controller performance. To assess the proposed control methodology effectiveness, a trajectory tracking control is designed and implemented on an unmanned surface vehicle under the action of bounded unknown uncertainties and external perturbations. Numerical simulations and experimental results conducted with a vessel prototype demonstrate the performance and advantages under payload variations and external environmental conditions. Finally, a comparative study between the proposed approach with other adaptive super-twisting works has been conducted.


Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
Transfer Function in Control Systems
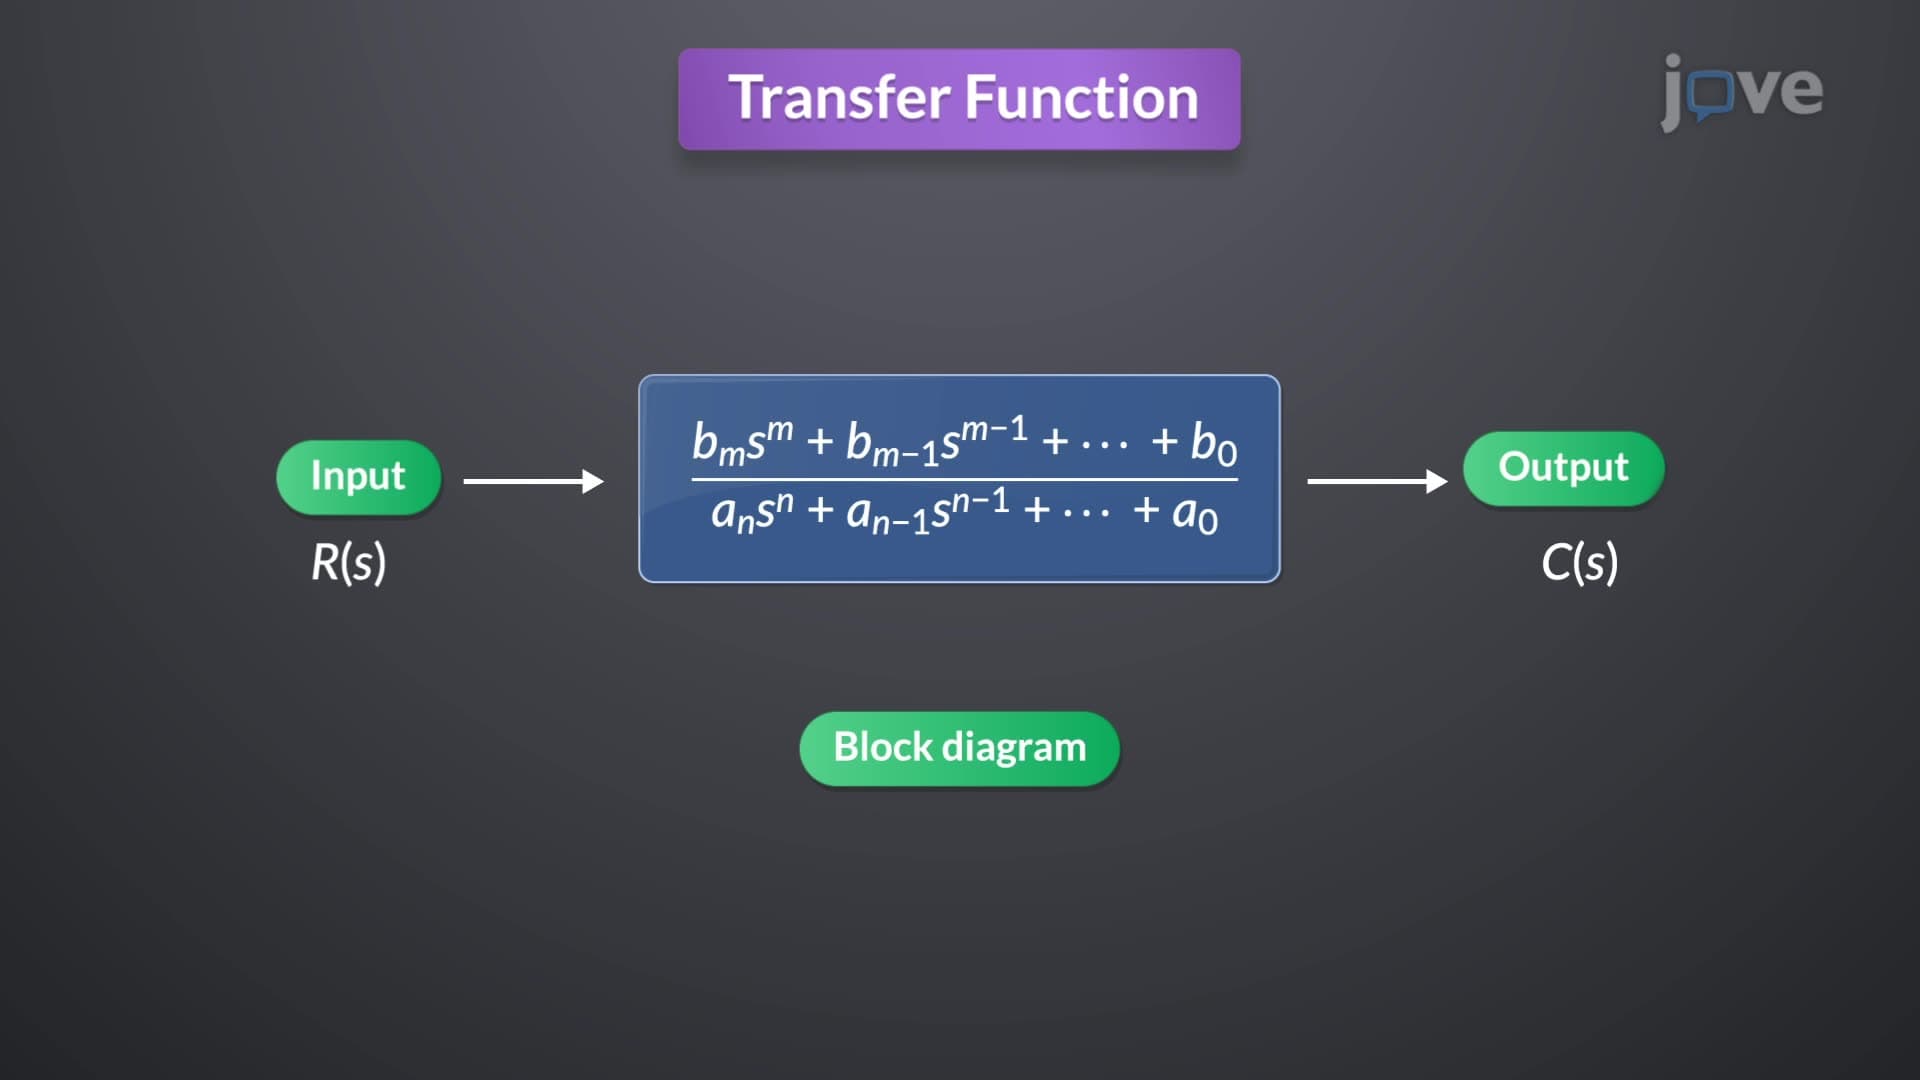
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...