Related Experiment Video
Updated: Oct 28, 2026

An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
A fractional-order fixed-time attractive and noise-tolerant zeroing neural network and its application to robotic
Shaoting Cao1, Jie Jin2, Shiqiang Chen3
1Sanya Institute of Hunan University of Science and Technology, Sanya, 572024, Hainan, China; School of Information and Electrical Engineering, Hunan University of Science and Technology, Xiangtan 411201, China.

Abstract:
Real-time and high-precision solving of time-varying problems is of great significance in fields such as robotic control and signal processing. As an efficient online method for solving time-varying problems, the Zeroing neural network (ZNN) has been extensively investigated. However, traditional integer-order ZNN models have inherent limitations in shaping convergence dynamics and accommodating non-local memory effects. To address these issues, a fractional-order fixed-time attractive and noise-tolerant Zeroing neural network (FO-FTNTZNN) is proposed, and its fixed-time attractivity in the Mittag-Leffler sense under noise-free conditions and its robust stability under bounded noise disturbances are rigorously demonstrated using a non-smooth fractional-order Lyapunov function. Furthermore, the attraction characteristics and anti-interference performance of the FO-FTNTZNN in both noise-free and noisy environments are further verified by multiple sets of numerical simulation experiments. Finally, the proposed FO-FTNTZNN model is successfully applied to the trajectory tracking control problem of a robotic manipulator. In summary, the proposed FO-FTNTZNN model provides a unified fractional-order framework for time-varying problem solving and robotic control, integrating fixed-time attractivity and bounded-noise robustness, and demonstrates its practical potential through numerical simulations and robotic trajectory tracking. A fractional-order parameter analysis is further provided as a supporting sensitivity study to characterize the memory-dependent dynamic behavior and transient response of the proposed framework.
Related Concept Videos
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires careful...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:24
PI Controller: Design
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:21
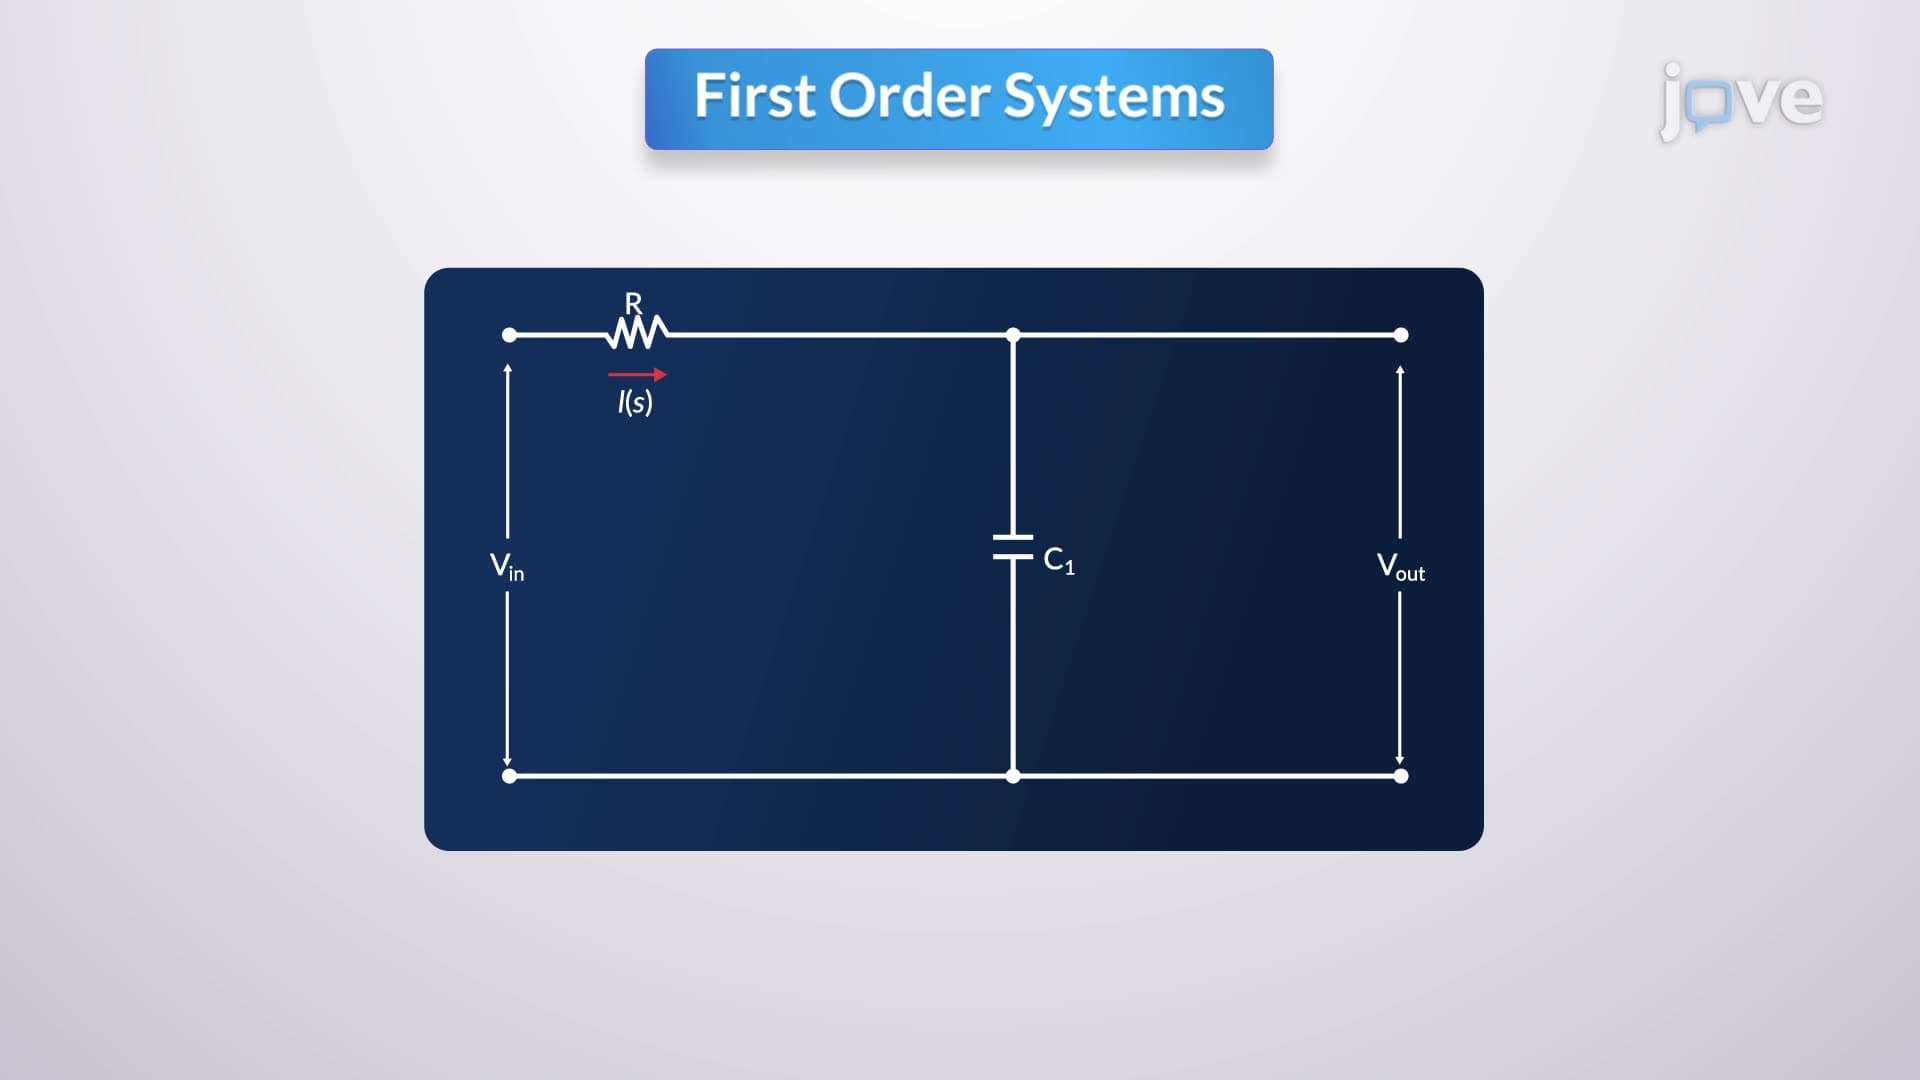
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...