Related Experiment Video
Updated: Jul 27, 2025


Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Development and Experimental Evaluation of a Novel Portable Haptic Robotic Exoskeleton Glove System for Patients with
Wenda Xu1, Yunfei Guo2, Cesar Bravo3
1Department of Mechanical Engineering, Virginia Tech, Blacksburg, VA, 24061 USA.

Abstract:
This paper presents the development and experimental evaluation of a portable haptic exoskeleton glove system designed for people who suffer from brachial plexus injuries to restore their lost grasping functionality. The proposed glove system involves force perception, linkage-driven finger mechanism, and personalized voice control to achieve various grasping functionality requirements. The fully integrated system provides our wearable device with lightweight, portable, and comfortable characterization for grasping objects used in daily activities. Rigid articulated linkages powered by Series Elastic Actuators (SEAs) with slip detection on the fingertips provide stable and robust grasp for multiple objects. The passive abduction-adduction motion of each finger is also considered to provide better grasping flexibility for the user. The continuous voice control with bio-authentication also provides a hands-free user interface. The experiments with different objects verify the functionalities and capabilities of the proposed exoskeleton glove system in grasping objects with various shapes and weights used in activities of daily living (ADLs).
More Related Videos
 03:55
Author Spotlight: Enhancing Grasping Abilities for Hemiplegic Patients with Flexible Robotic Limbs
Published on: October 27, 2023
 09:14
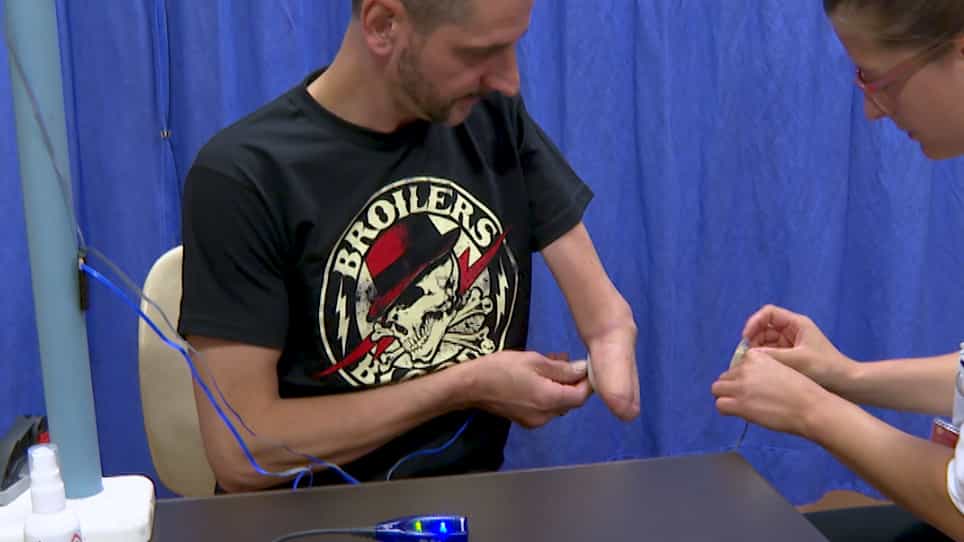
Surface Electromyographic Biofeedback as a Rehabilitation Tool for Patients with Global Brachial Plexus Injury Receiving Bionic Reconstruction
Published on: September 28, 2019