Related Experiment Video
Updated: Jul 26, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Data-Driven Optimal Bipartite Consensus Control for Second-Order Multiagent Systems via Policy Gradient Reinforcement

Abstract:
This article investigates the optimal bipartite consensus control (OBCC) problem for unknown second-order discrete-time multiagent systems (MASs). First, the coopetition network is constructed to describe the cooperative and competitive relationships between agents, and the OBCC problem is proposed by the tracking error and related performance index function. Based on the distributed policy gradient reinforcement learning (RL) theory, a data-driven distributed optimal control strategy is obtained to guarantee the bipartite consensus of all agents' position and velocity states. In addition, the offline data sets ensure the learning efficiency of the system. These data sets are generated by running the system in real time. Besides, the designed algorithm is an asynchronous version, which is essential to solve the challenge caused by the computational ability difference between nodes in MASs. Then, by means of the functional analysis and Lyapunov theory, the stability of the proposed MASs and the convergence of the learning process are analyzed. Furthermore, an actor-critic structure containing two neural networks is used to implement the proposed methods. Finally, a numerical simulation shows the effectiveness and validity of the results.


Related Concept Videos
 01:18
Second Order systems II
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:09
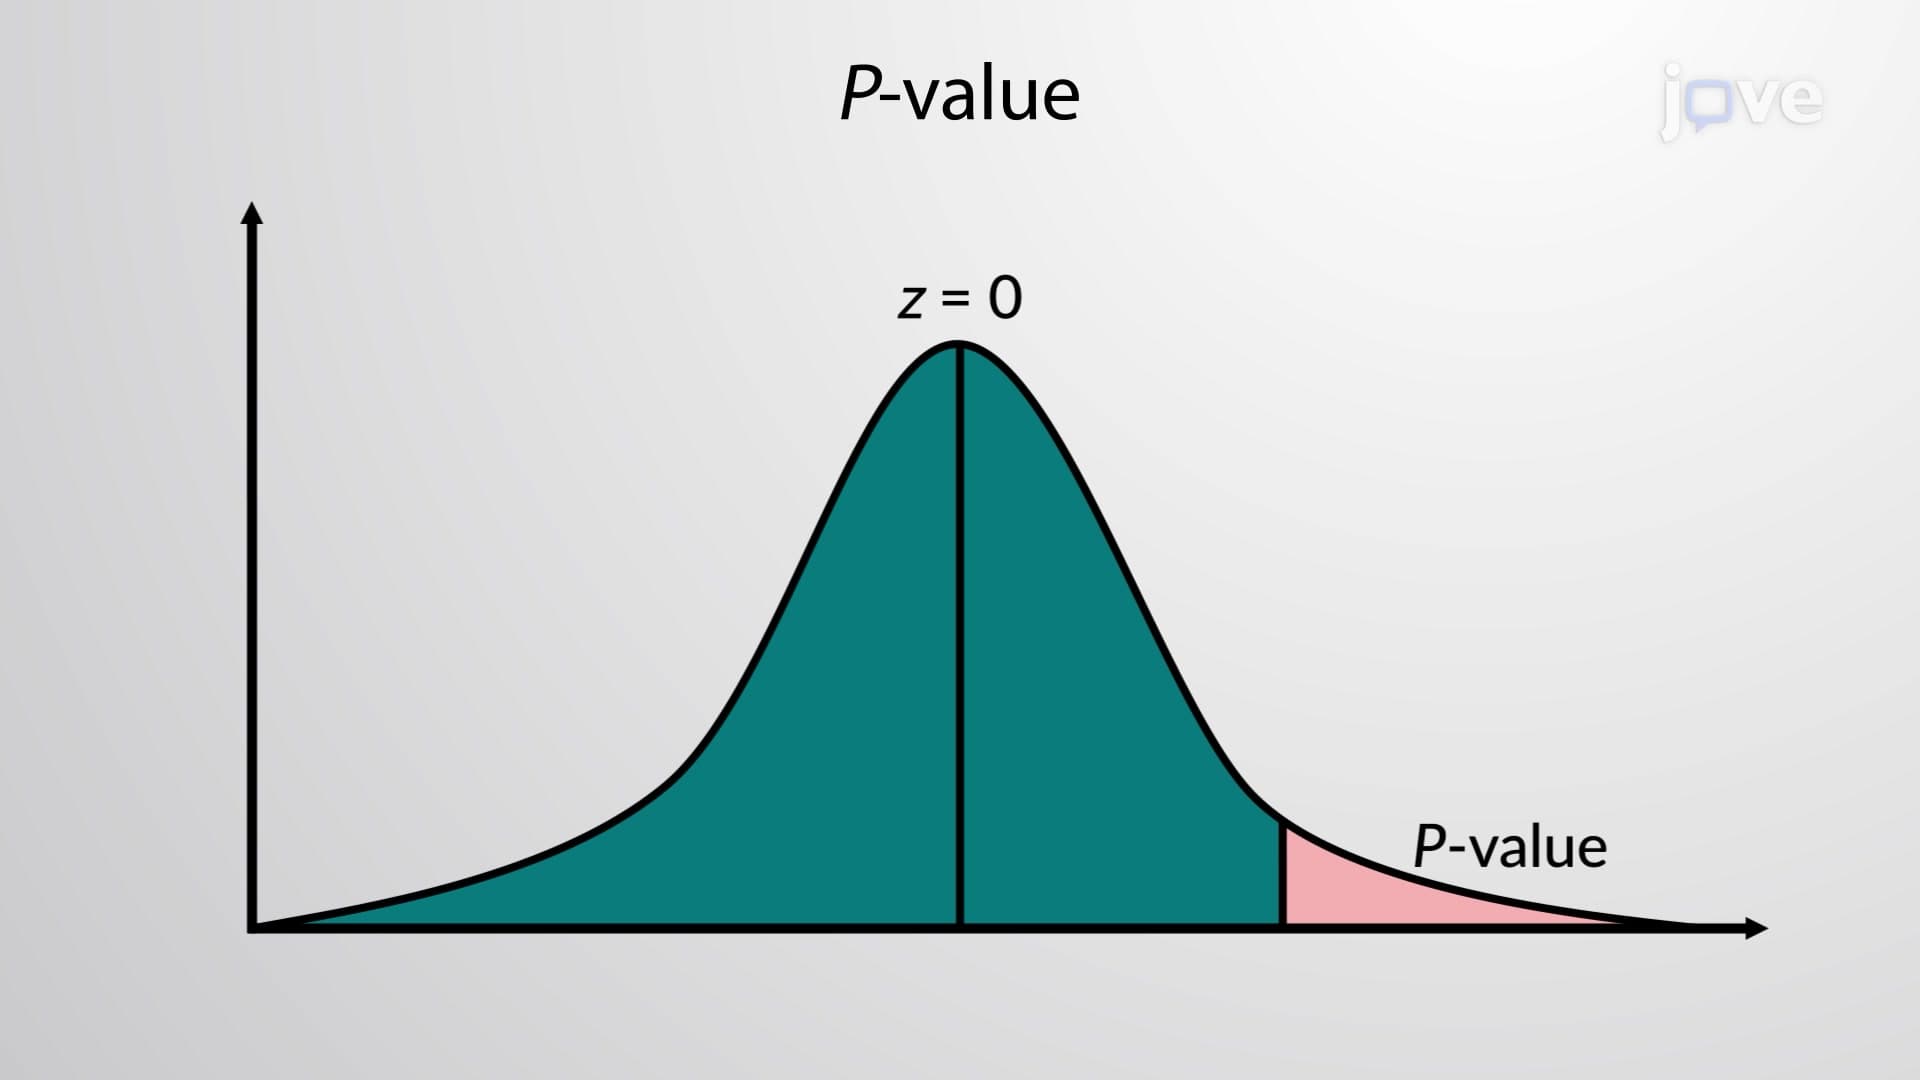
Decision Making: P-value Method
First, a specific claim about the population parameter is proposed. The claim is based on the research question and is stated in a simple form. Further, an opposing statement to the claim is also stated. These statements can act as null and alternative hypotheses: a null hypothesis would be a neutral statement while the alternative hypothesis can...