Related Experiment Video
Updated: Jul 23, 2025

Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Contact feedback helps snake robots propel against uneven terrain using vertical bending
1Department of Mechanical Engineering, Johns Hopkins University, Baltimore, MD 21218, United States of America.

Abstract:
Snakes can bend their elongate bodies in various forms to traverse various environments. We understand well how snakes use lateral body bending to push against asperities on flat ground for propulsion, and snake robots can do so effectively. However, snakes can also use vertical bending to push against uneven terrain of large height variation for propulsion, and they can adjust this bending to adapt to novel terrain presumably using mechano-sensing feedback control. Although some snake robots can traverse uneven terrain, few have used vertical bending for propulsion, and how to control this process in novel environments is poorly understood. Here we systematically studied a snake robot with force sensors pushing against large bumps using vertical bending to understand the role of sensory feedback control. We compared a feedforward controller and four feedback controllers that use different sensory information and generate distinct bending patterns and body-terrain interaction. We challenged the robot with increasing backward load and novel terrain geometry that break its contact with the terrain. We further varied how much the feedback control modulated body bending to conform to or push against the terrain to test their effects. Feedforward propagation of vertical bending generated large propulsion when the bending shape matched terrain geometry. However, when perturbations caused loss of contact, the robot easily lost propulsion or had motor overload. Contact feedback control resolved these issues by helping the robot regain contact. Yet excessive conformation interrupted shape propagation and excessive pushing stalled motors frequently. Unlike that using lateral bending, for propulsion generation using vertical bending, body weight that can help maintain contact with the environment but may also overload motors. Our results will help snake robots better traverse uneven terrain with large height variation and can inform how snakes use sensory feedback to control vertical body bending for propulsion.

Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:15
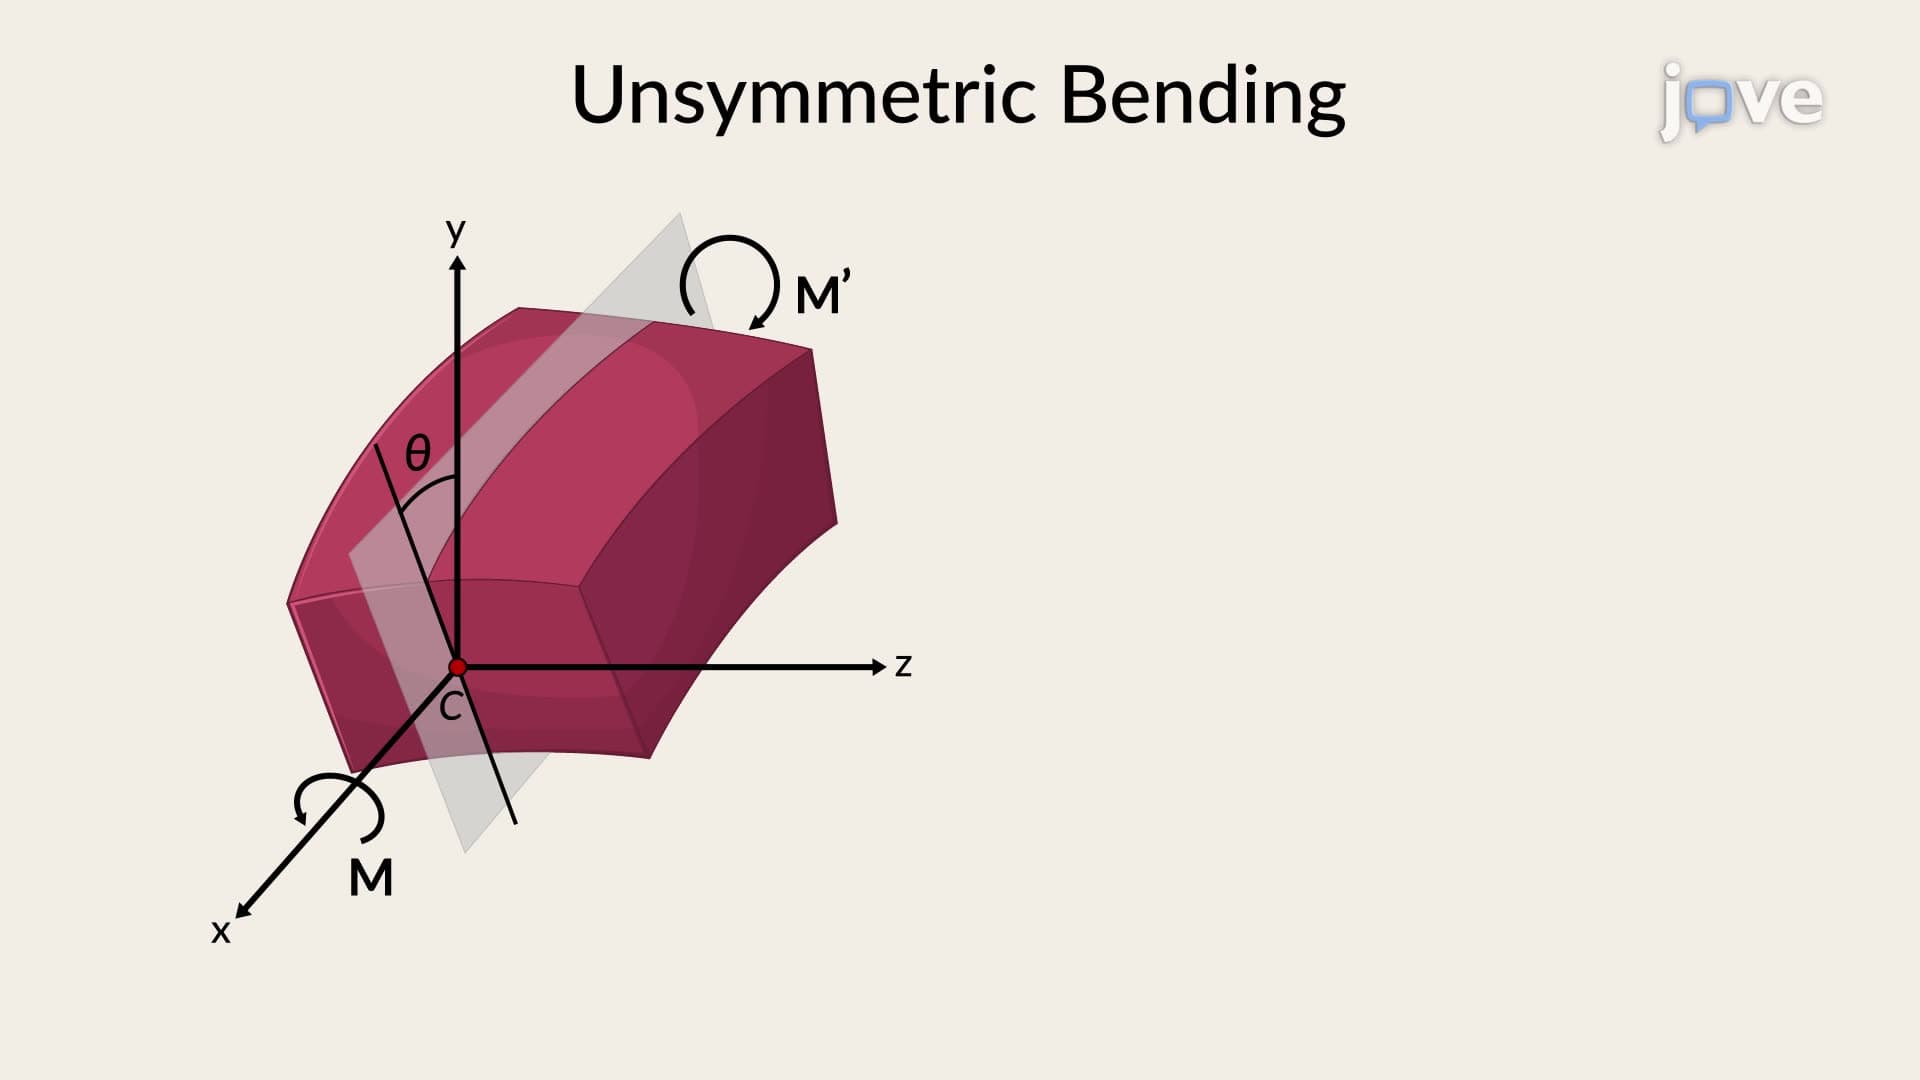
Unsymmetric Bending - Angle of Neutral Axis
When a bending moment is applied at an angle θ concerning the vertical axis of a symmetrical member, it can be resolved into components along the member's principal...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:18
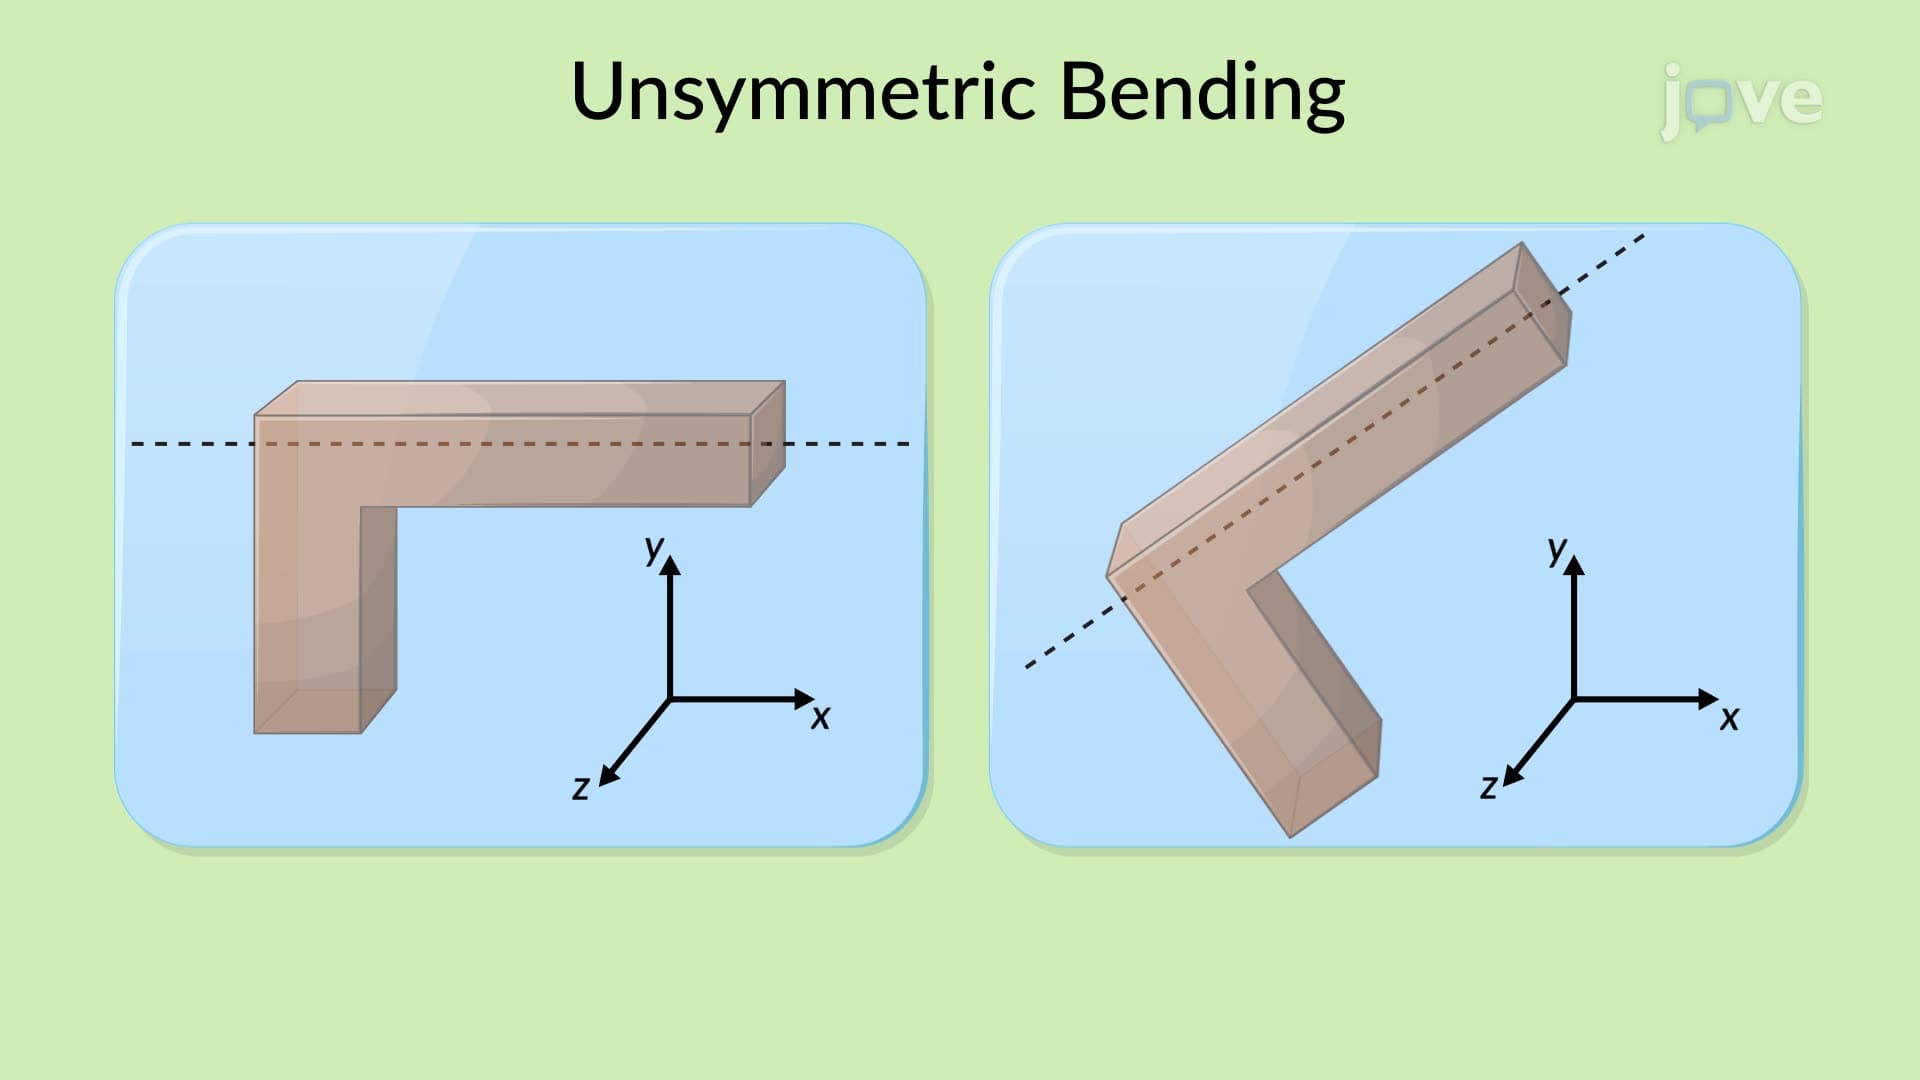
Unsymmetric Bending
 01:16
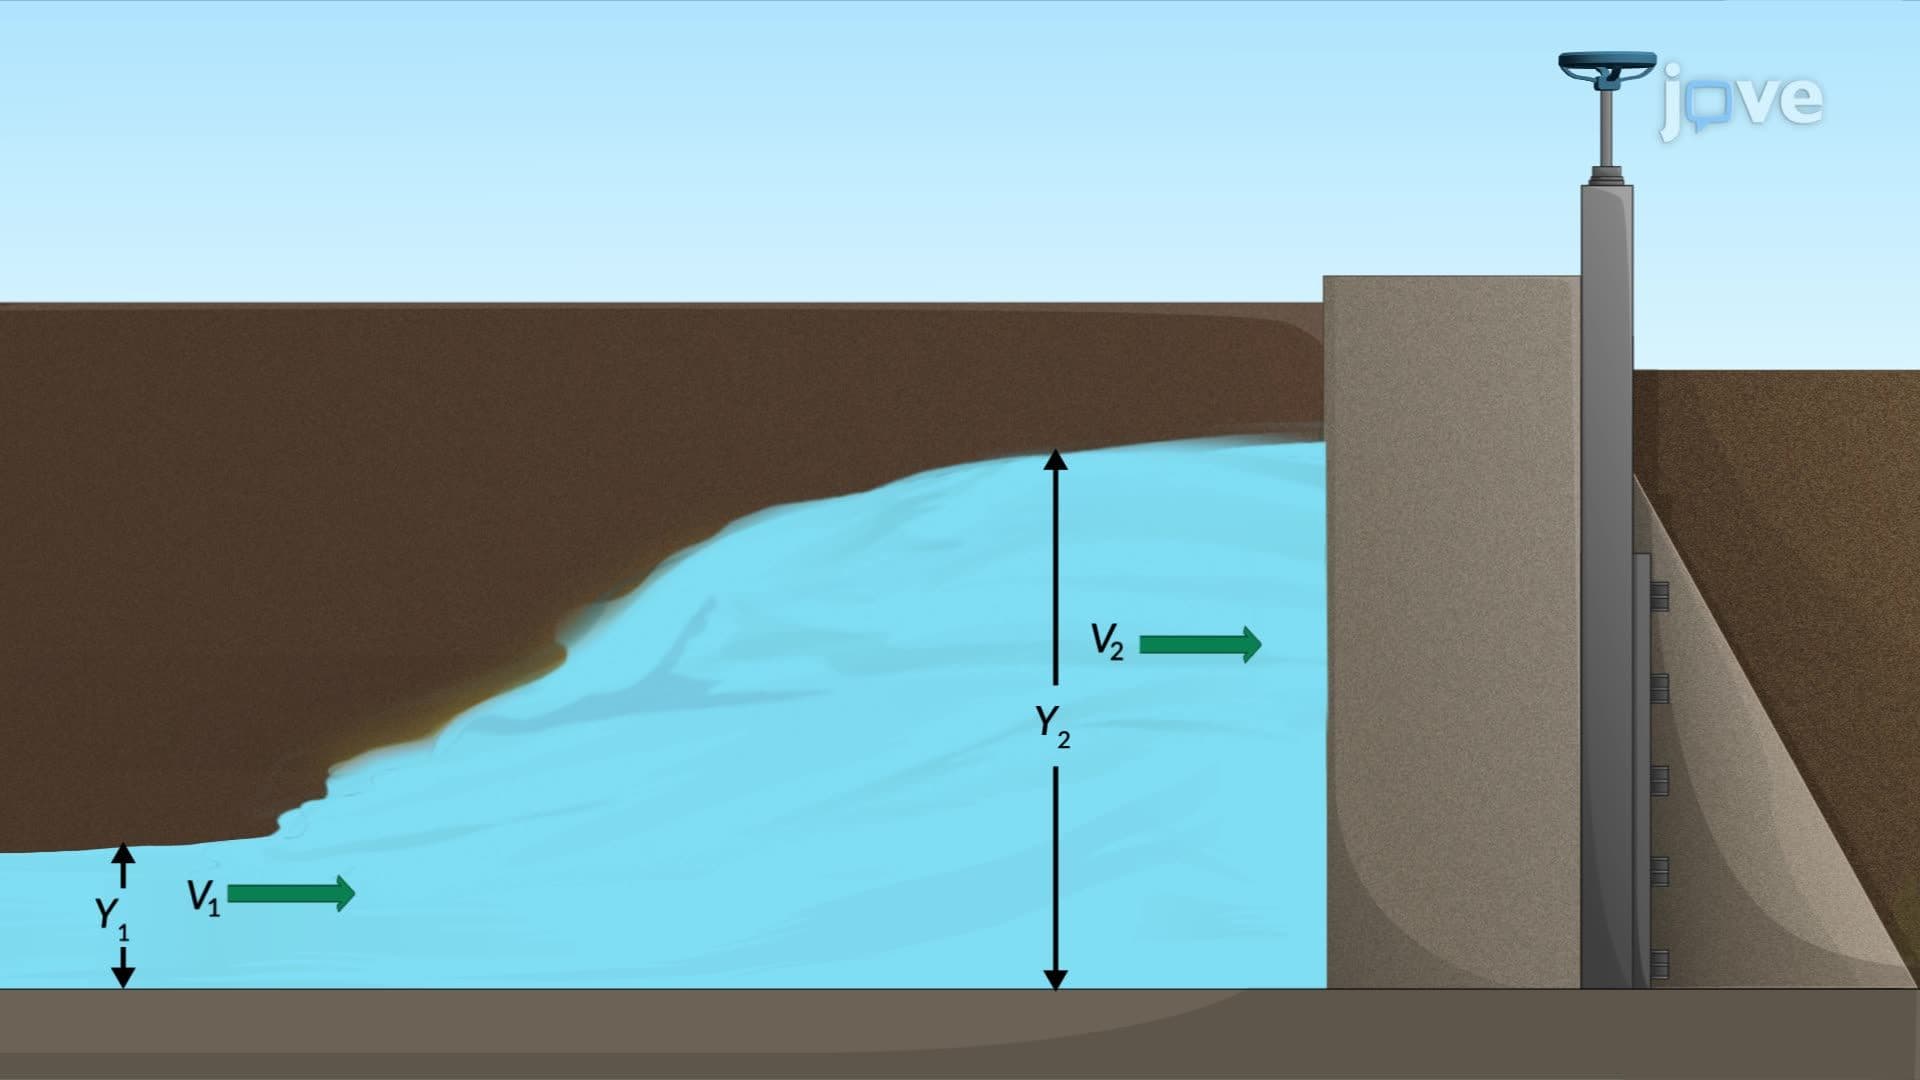
Hydraulic Jump: Problem Solving
 01:09
Bending of Material: Problem Solving