Related Experiment Video
Updated: Jul 22, 2025

Tracking Infiltration Front Depth Using Time-lapse Multi-offset Gathers Collected with Array Antenna Ground Penetrating Radar
Published on: May 1, 2018
Adaptive Formation Tracking Control of Multiple Vertical Takeoff and Landing UAVs With Bearing-Only Measurements

Abstract:
This article studies the leader-following formation tracking control problem of multiple vertical takeoff and landing (VTOL) unmanned aerial vehicles (UAVs) subject to uncertain parameters, in which the target formation configuration is defined by using the interneighbors' bearing vectors. An adaptive formation control algorithm with bearing-only measurements is proposed under a hierarchical control framework. More specifically, a saturated adaptive distributed control force is developed in the position loop with bearing-only measurements. Since the bearing vectors with respect to the neighbors can be directly measured by low-cost onboard cameras, the proposed formation algorithm can be implemented without interagent communication. Subsequently, in the attitude loop, an adaptive hybrid control scheme via two modified Rodrigues parameters (MRPs) sets is proposed, which achieves the command attitude tracking globally and also avoids the unwinding problem of MRPs. Based on the Lyapunov stability analysis and hybrid theory, we prove that the overall closed-loop error system is globally asymptotically stable. Finally, we provide a numerical example to demonstrate the effectiveness of the proposed control algorithm.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:19
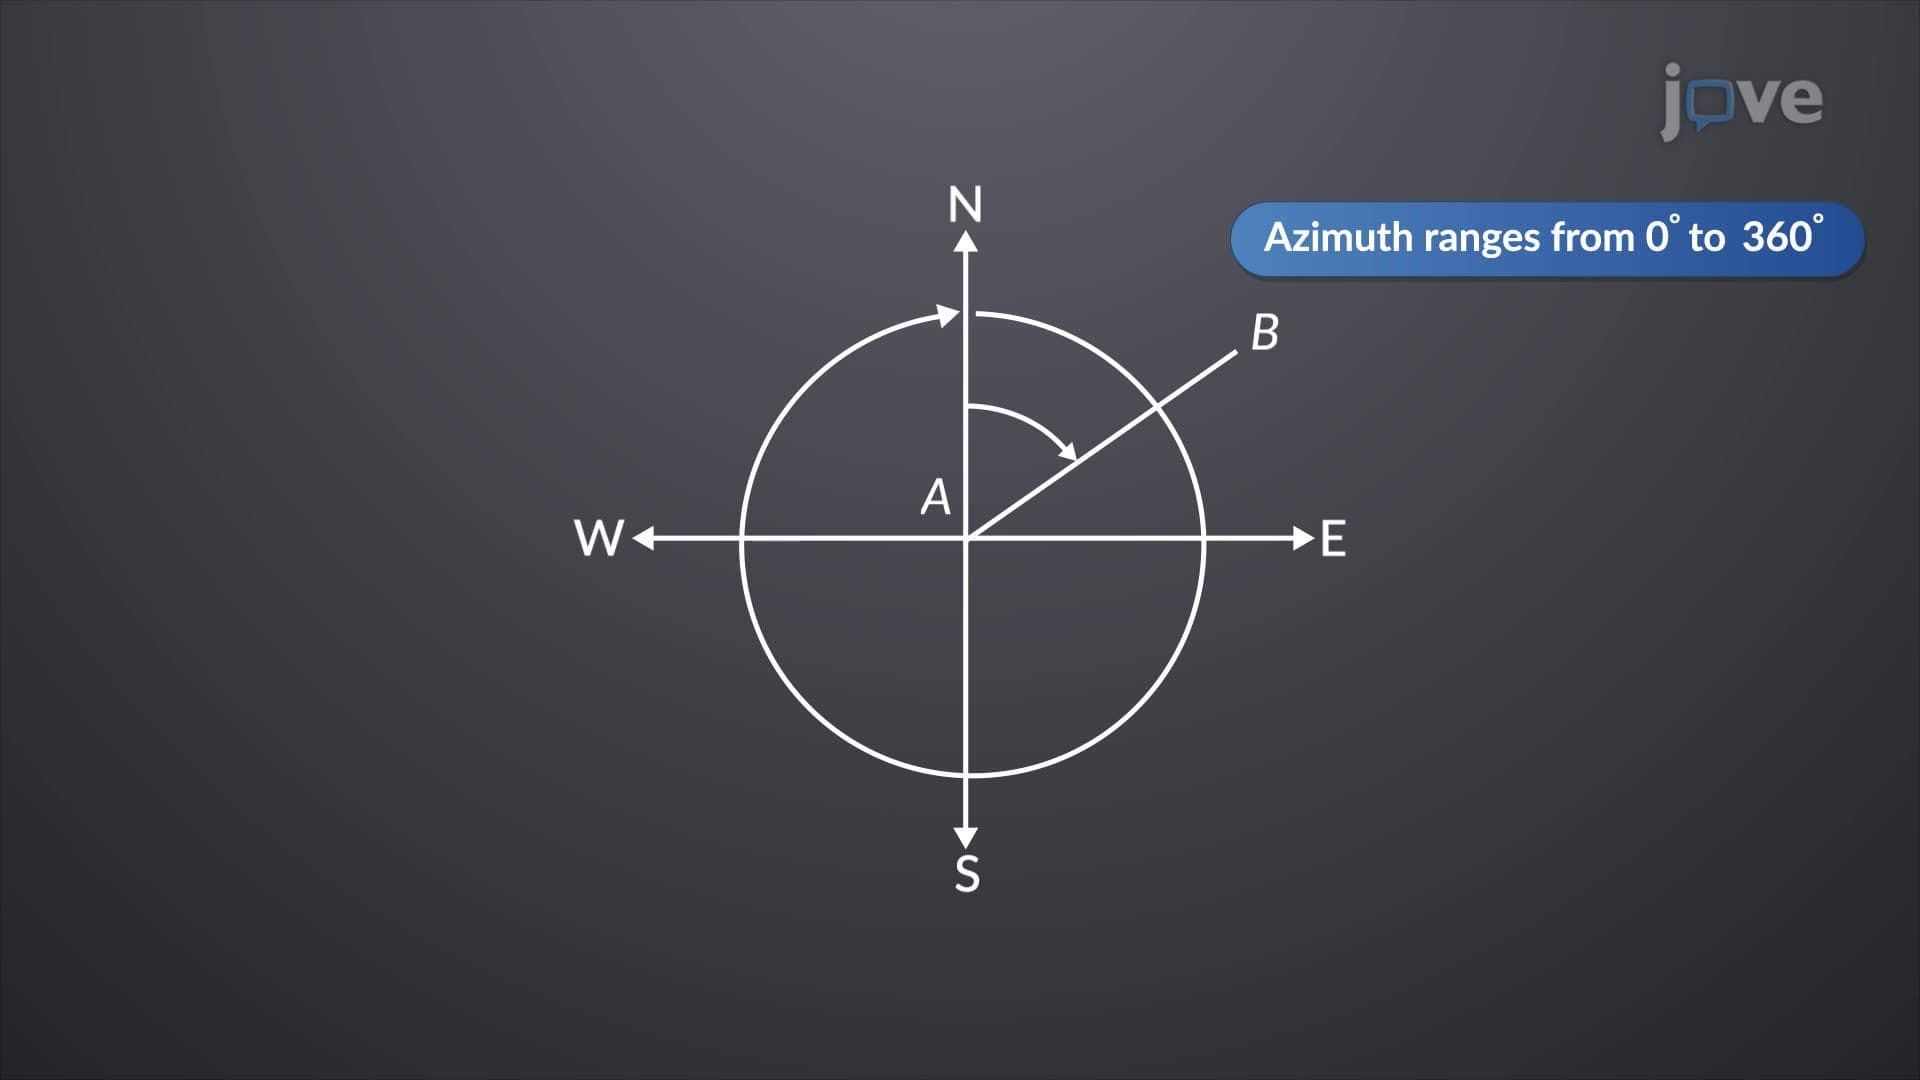
Azimuths and Bearings
 01:30
Types of Global Positioning System Surveys
 01:28
Field Application of Global Positioning System
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:18
Distance Measurements by Taping