Related Experiment Video
Updated: Jul 22, 2025


Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Multimodal Locomotion in a Soft Robot Through Hierarchical Actuation
1Department of Mechanical and Aerospace Engineering, University of California San Diego, San Diego, California, USA.

Abstract:
Soft and continuum robots present the opportunity for extremely large ranges of motion, which can enable dexterous, adaptive, and multimodal locomotion behaviors. However, as the number of degrees of freedom (DOF) of a robot increases, the number of actuators should also increase to achieve the full actuation potential. This presents a dilemma in mobile soft robot design: physical space and power requirements restrict the number and type of actuators available and may ultimately limit the movement capabilities of soft robots with high-DOF appendages. Restrictions on actuation of continuum appendages ultimately may limit the various movement capabilities of soft robots. In this work, we demonstrate multimodal behaviors in an underwater robot called "Hexapus." A hierarchical actuation design for multiappendage soft robots is presented in which a single high-power motor actuates all appendages for locomotion, while smaller low-power motors augment the shape of each appendage. The flexible appendages are designed to be capable of hyperextension for thrust, and flexion for grasping with a peak pullout force of 32 N. For propulsion, we incorporate an elastic membrane connected across the base of each tentacle, which is stretched slowly by the high-power motor and released rapidly through a slip-gear mechanism. Through this actuation arrangement, Hexapus is capable of underwater locomotion with low cost of transport (COT = 1.44 at 16.5 mm/s) while swimming and a variety of multimodal locomotion behaviors, including swimming, turning, grasping, and crawling, which we demonstrate in experiment.


Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:11
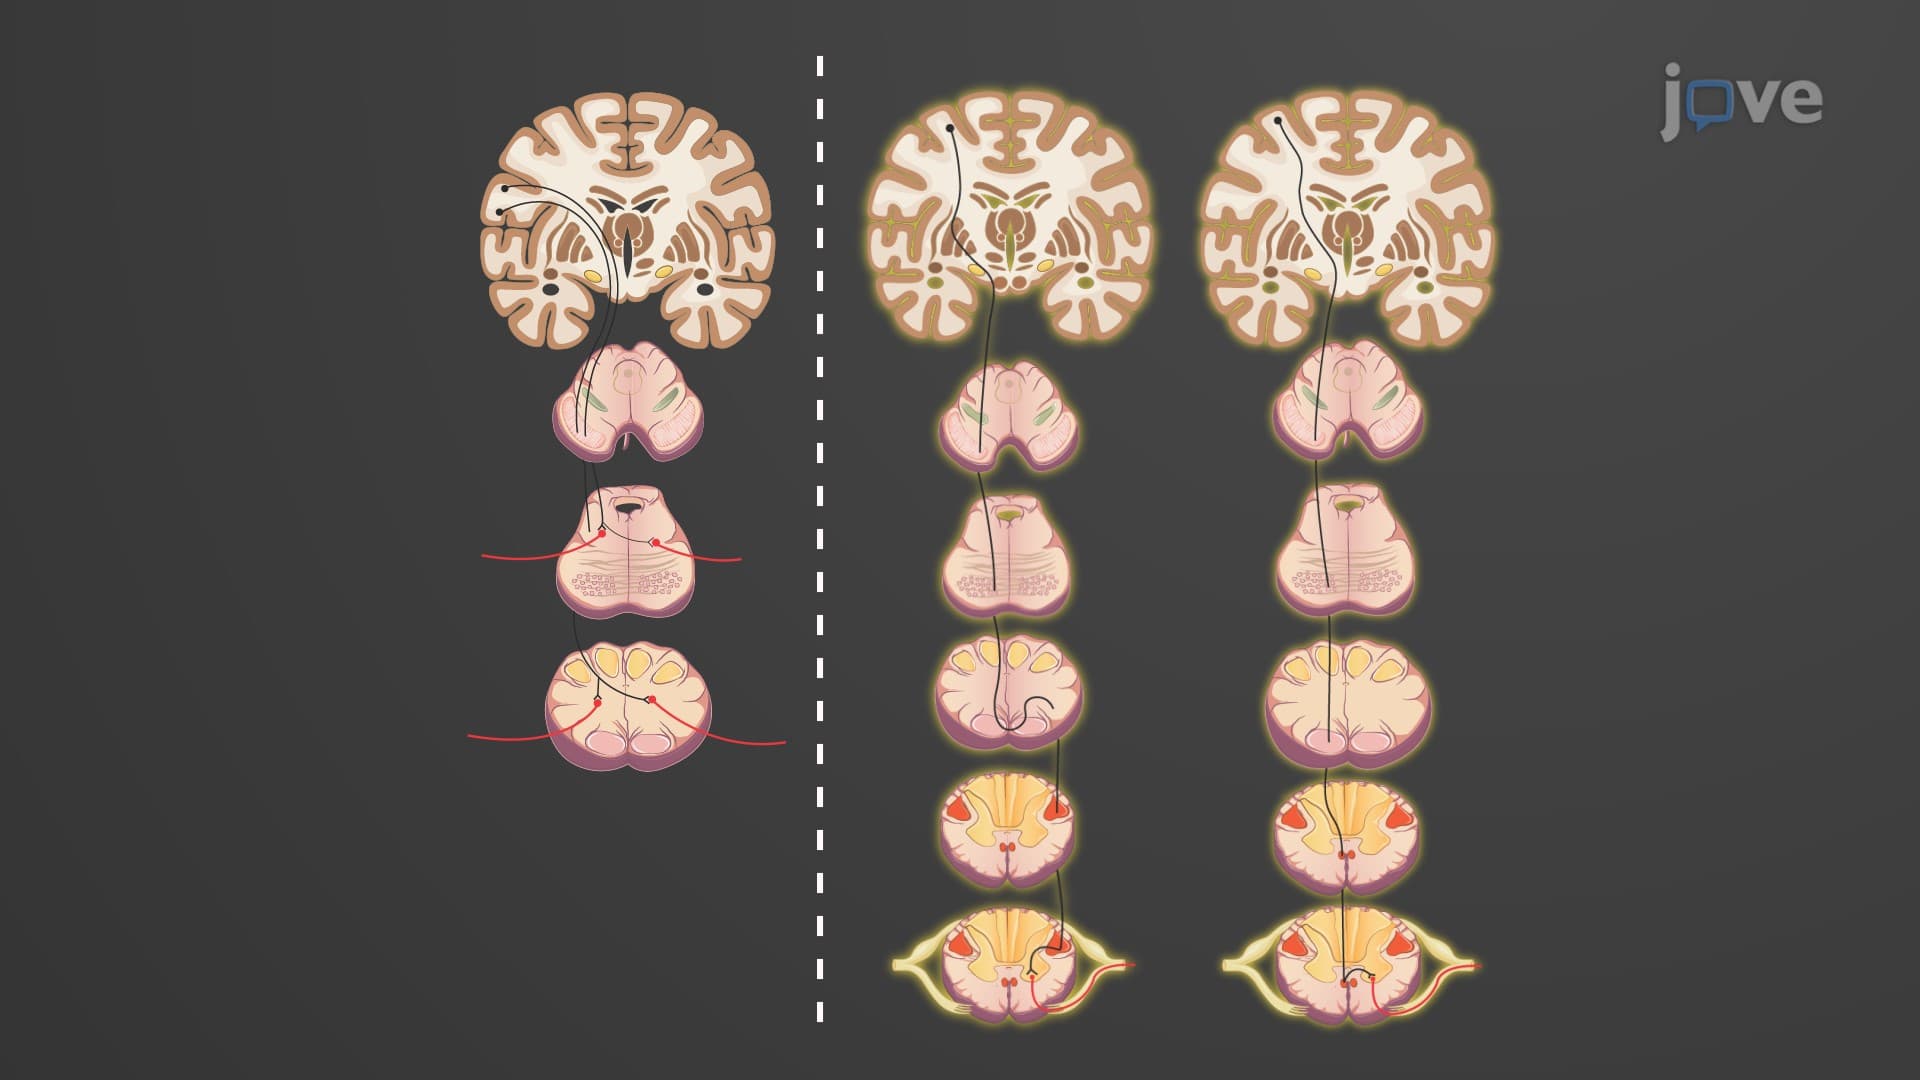
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement....