$ \mathcal{L}_{2}-\mathcal{L}_{\infty} $ control for memristive NNs with non-necessarily differentiable time-varying delay
Related Experiment Video
Updated: Jul 21, 2025
Assembly and Characterization of Biomolecular Memristors Consisting of Ion Channel-doped Lipid Membranes
Published on: March 9, 2019
1School of Computer Science and Technology, Anhui University of Technology, Ma'anshan 243032, China.

Abstract:
This paper investigates $ \mathcal{L}_{2}-\mathcal{L}_{\infty} $ control for memristive neural networks (MNNs) with a non-necessarily differentiable time-varying delay. The objective is to design an output-feedback controller to ensure the $ \mathcal{L}_{2}-\mathcal{L}_{\infty} $ stability of the considered MNN. A criterion on the $ \mathcal{L}_{2}-\mathcal{L}_{\infty} $ stability is proposed using a Lyapunov functional, the Bessel-Legendre inequality, and the convex combination inequality. Then, a linear matrix inequalities-based design scheme for the required output-feedback controller is developed by decoupling nonlinear terms. Finally, two examples are presented to verify the proposed $ \mathcal{L}_{2}-\mathcal{L}_{\infty} $ stability criterion and design method.
Related Concept Videos
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:30
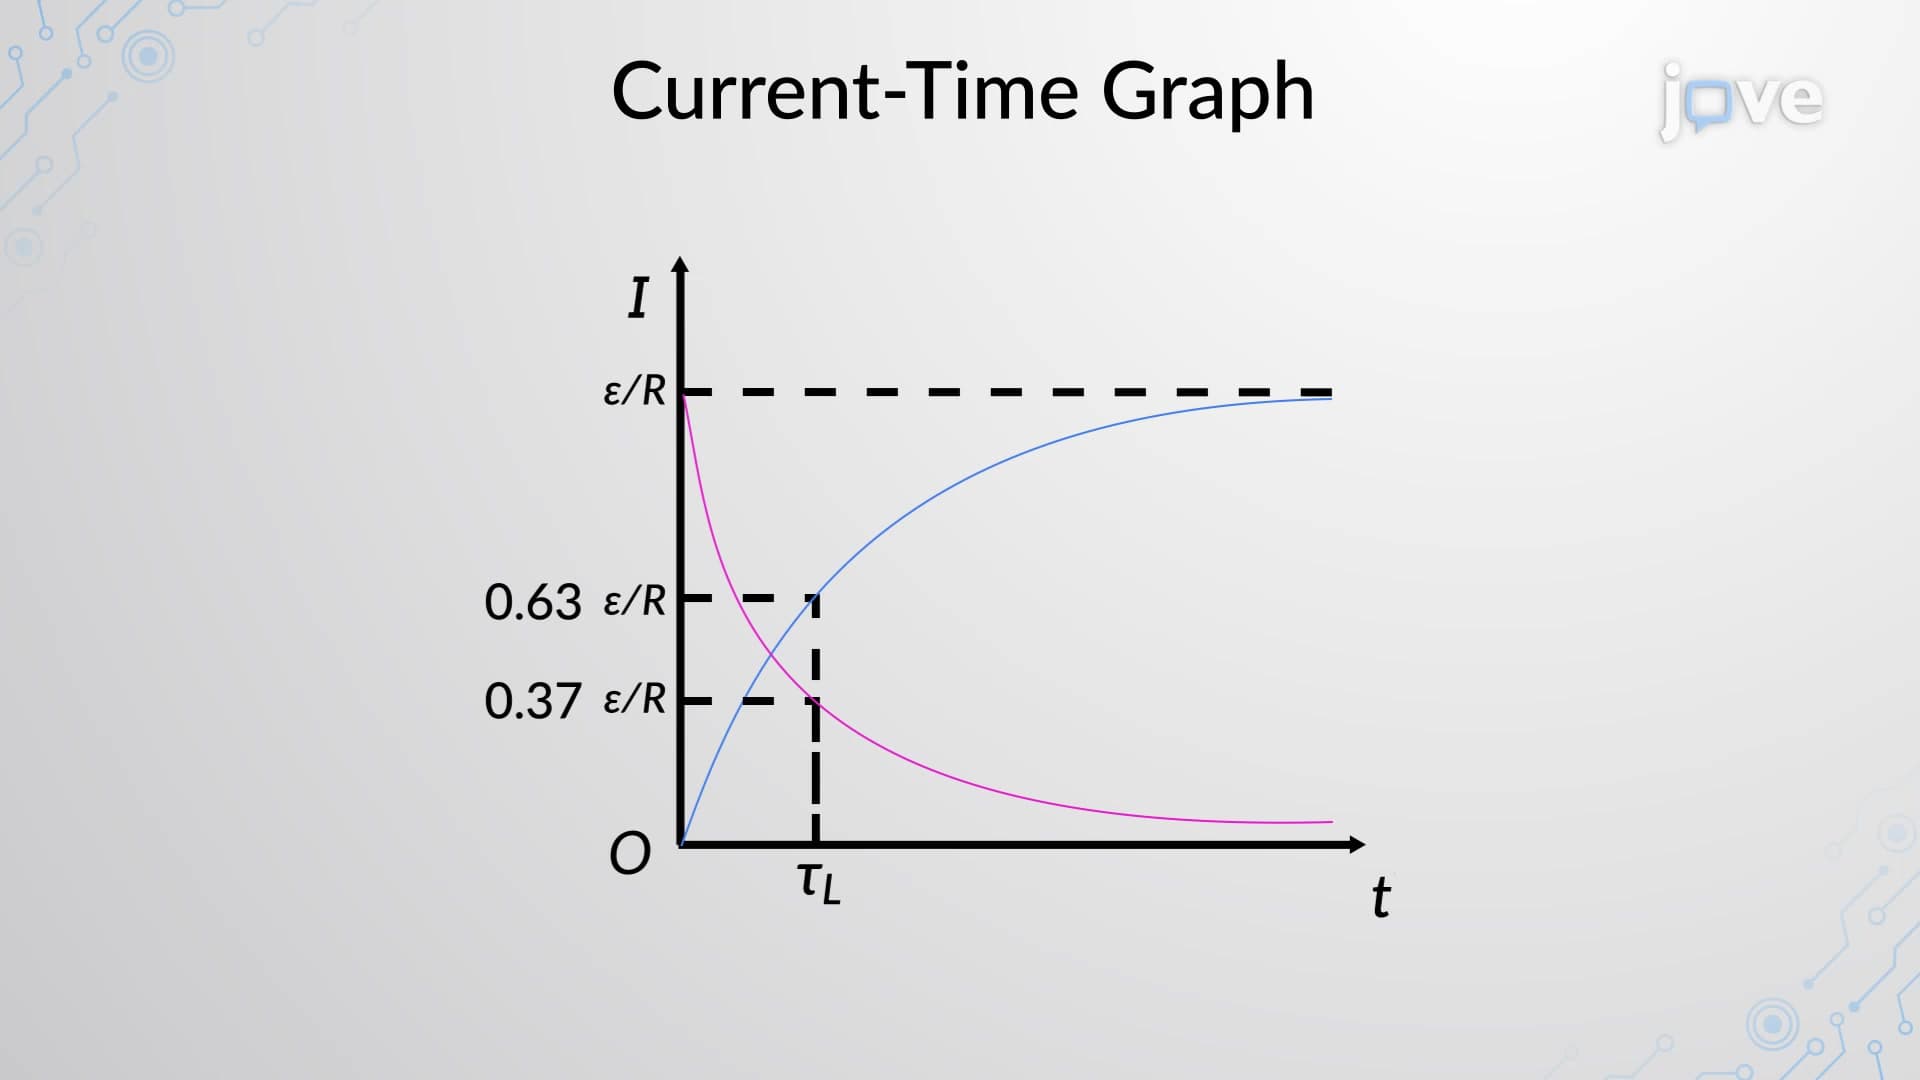
Current Growth And Decay In RL Circuits
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
 01:22
Phase-lead and Phase-lag Controllers