Related Experiment Video
Updated: Jul 20, 2025


Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
A Transformer-Based Neural Network for Gait Prediction in Lower Limb Exoskeleton Robots Using Plantar Force
Jiale Ren1,2, Aihui Wang1, Hengyi Li2
1School of Electronic and Information, Zhongyuan University of Technology, Zhengzhou 451191, China.

Abstract:
Lower limb exoskeleton robots have shown significant research value due to their capabilities of providing assistance to wearers and improving physical motion functions. As a type of robotic technology, wearable robots are directly in contact with the wearer's limbs during operation, necessitating a high level of human-robot collaboration to ensure safety and efficacy. Furthermore, gait prediction for the wearer, which helps to compensate for sensor delays and provide references for controller design, is crucial for improving the the human-robot collaboration capability. For gait prediction, the plantar force intrinsically reflects crucial gait patterns regardless of individual differences. To be exact, the plantar force encompasses a doubled three-axis force, which varies over time concerning the two feet, which also reflects the gait patterns indistinctly. In this paper, we developed a transformer-based neural network (TFSformer) comprising convolution and variational mode decomposition (VMD) to predict bilateral hip and knee joint angles utilizing the plantar pressure. Given the distinct information contained in the temporal and the force-space dimensions of plantar pressure, the encoder uses 1D convolution to obtain the integrated features in the two dimensions. As for the decoder, it utilizes a multi-channel attention mechanism to simultaneously focus on both dimensions and a deep multi-channel attention structure to reduce the computational and memory consumption. Furthermore, VMD is applied to networks to better distinguish the trends and changes in data. The model is trained and tested on a self-constructed dataset that consists of data from 35 volunteers. The experimental results show that FTSformer reduces the mean absolute error (MAE) up to 10.83%, 15.04% and 8.05% and the mean squared error (MSE) by 20.40%, 29.90% and 12.60% compared to the CNN model, the transformer model and the CNN transformer model, respectively.
More Related Videos
 05:25
Author Spotlight: Assessing Brain Activity in Robotic-Assisted Lower Limb Rehabilitation Using fNIRS
Published on: June 7, 2024
 06:00
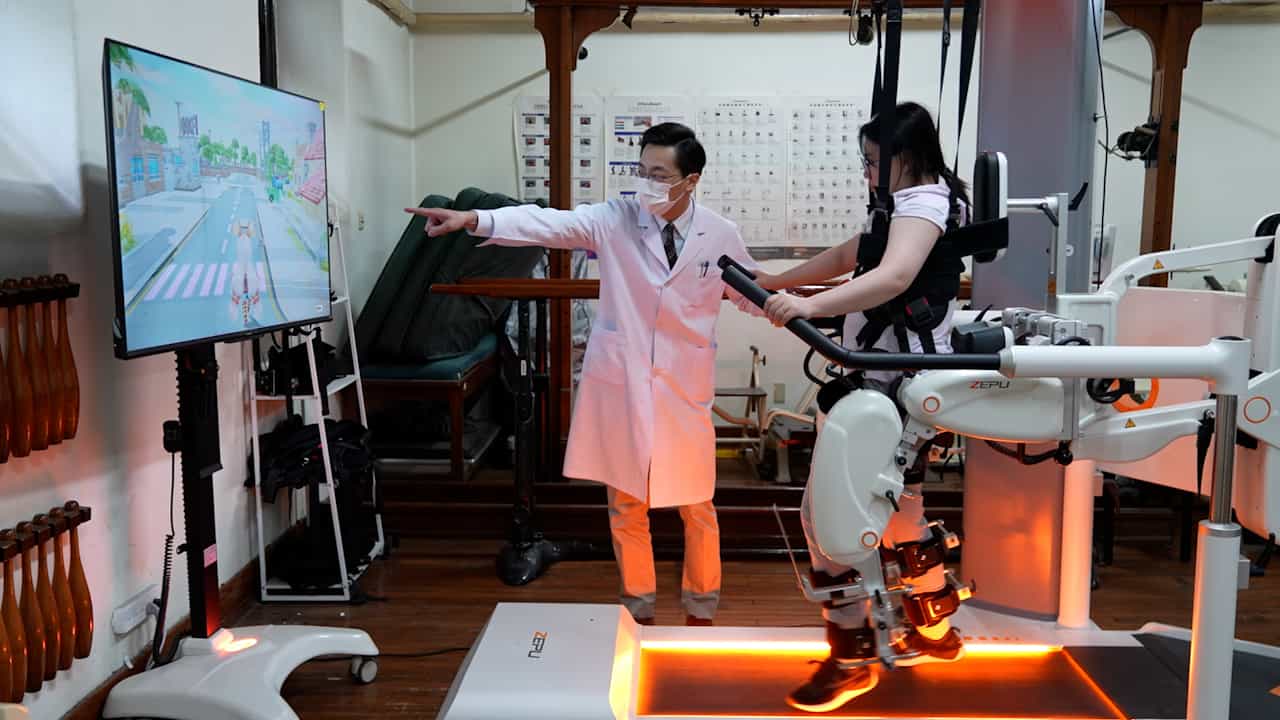
A Rehabilitation Program of Exoskeleton-assisted Body Weight-Supported Treadmill Training with Non-immersive Virtual Reality for Stroke Patients
Published on: May 16, 2025