Continuous shared control of a mobile robot with brain-computer interface and autonomous navigation for daily assistance
Related Experiment Video
Updated: Jul 18, 2025

Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
Baoguo Xu1, Deping Liu1, Muhui Xue1
1State Key Laboratory of Bioelectronics, Jiangsu Key Laboratory of Remote Measurement and Control, School of Instrument Science and Engineering, Southeast University, Nanjing 210096, China.

Abstract:
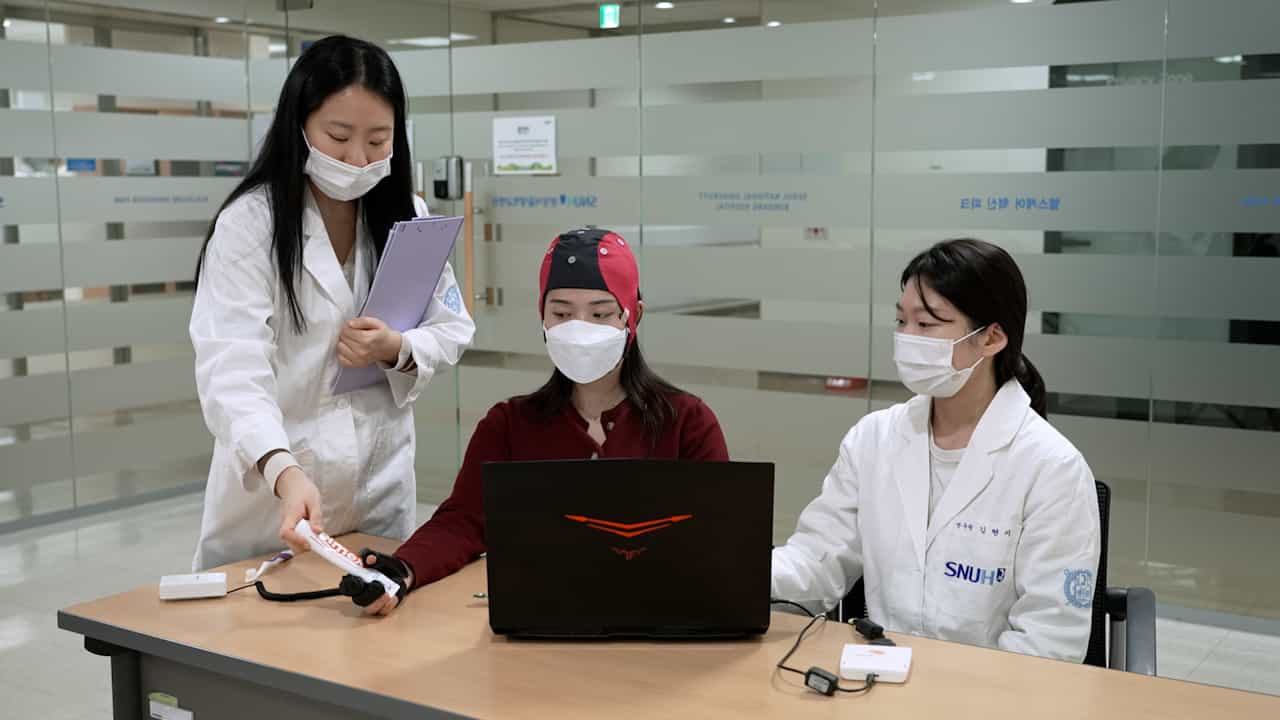
Although the electroencephalography (EEG) based brain-computer interface (BCI) has been successfully developed for rehabilitation and assistance, it is still challenging to achieve continuous control of a brain-actuated mobile robot system. In this study, we propose a continuous shared control strategy combining continuous BCI and autonomous navigation for a mobile robot system. The weight of shared control is designed to dynamically adjust the fusion of continuous BCI control and autonomous navigation. During this process, the system uses the visual-based simultaneous localization and mapping (SLAM) method to construct environmental maps. After obtaining the global optimal path, the system utilizes the brain-based shared control dynamic window approach (BSC-DWA) to evaluate safe and reachable trajectories while considering shared control velocity. Eight subjects participated in two-stage training, and six of these eight subjects participated in online shared control experiments. The training results demonstrated that naïve subjects could achieve continuous control performance with an average percent valid correct rate of approximately 97 % and an average total correct rate of over 80 %. The results of online shared control experiments showed that all of the subjects could complete navigation tasks in an unknown corridor with continuous shared control. Therefore, our experiments verified the feasibility and effectiveness of the proposed system combining continuous BCI, shared control, autonomous navigation, and visual SLAM. The proposed continuous shared control framework shows great promise in BCI-driven tasks, especially navigation tasks for brain-driven assistive mobile robots and wheelchairs in daily applications.
More Related Videos

Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:22
Autonomic Nervous System
The ANS comprises two main divisions: the sympathetic and parasympathetic divisions. These divisions function antagonistically to maintain a dynamic...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...