Related Experiment Video
Updated: Jul 18, 2025


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Structural Optimization Design of a Six-Degrees-of-Freedom Serial Robot with Integrated Topology and Dimensional
Jiguang Jia1,2, Xuan Sun1,2
1College of Mechanic and Control Engineering, Guilin University of Technology, Guilin 541004, China.

Abstract:
In the structural design of serial robots, topology and dimensional parameters design are independent, making it challenging to achieve synchronous optimization design between the two. To address this issue, a topology-and-dimension-parameter integrated optimization method (TPOM) is proposed by setting critical variables to connect topology layout and dimensional features. Firstly, the topology layout is extracted by the edge detection technique. Structural manufacturability reconstruction is conducted by measuring the dimensions of the layout through a program. Additionally, for the reconstructed structural layout, critical variables are set using three-dimensional software (SOLIDWORKS2021). The experiments primarily involve critical variables, quality, and deformation as variables. Then, the response surface methodology is selected to construct the stiffness-mass metamodel, and based on this, the structural deformation is analyzed. Lastly, the multi-objective genetic algorithm (MOGA) is employed to optimize the critical variables, and an optimized structure is established for validation. The results indicate that the proposed method (TPOM) reduces the mass of the structure by 15% while maintaining its stiffness. In addition, the deformation of the whole structure is less than 0.352 mm, which meets the requirements of industrial applications. Through quantitative analysis of the experimental results, the feasibility and superiority of the proposed method have been demonstrated.


Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:16
Design of Transmission Shafts
 01:30
Machines: Problem Solving II
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:23
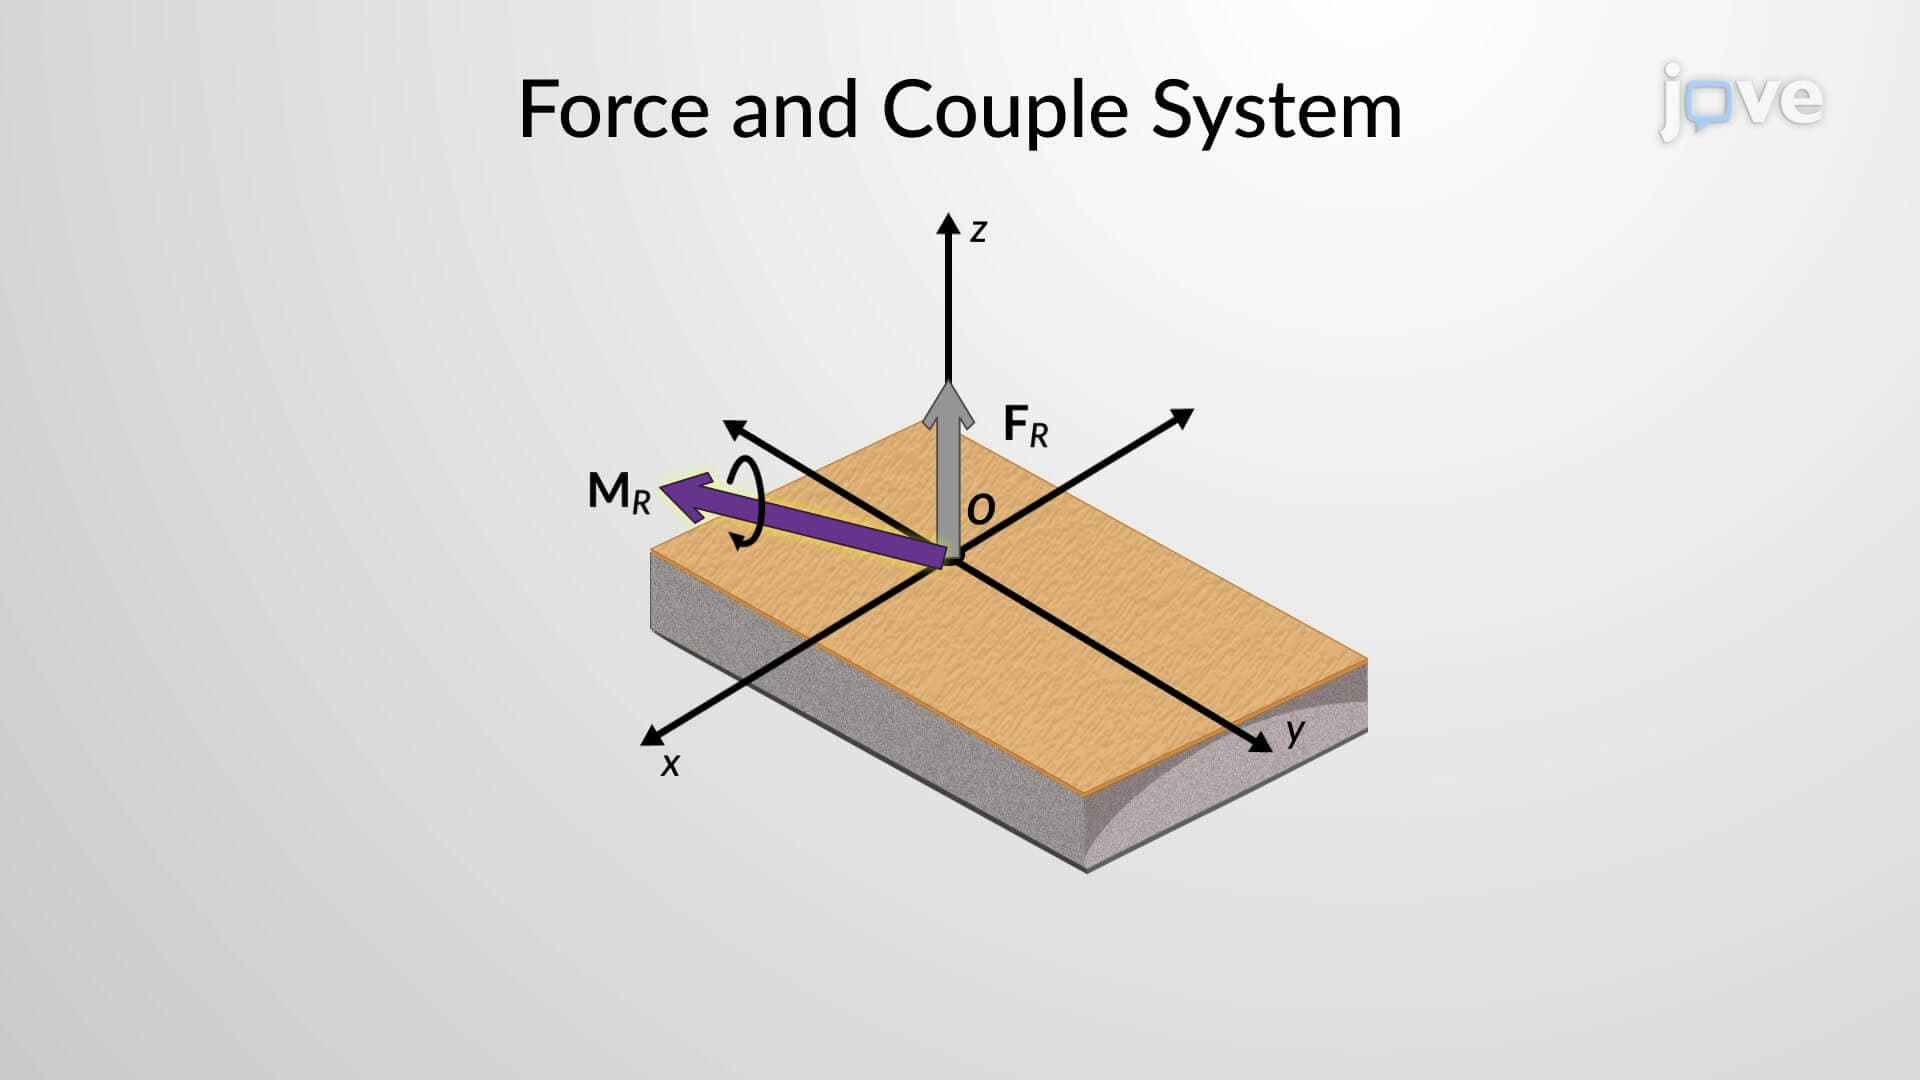
Simplification of a Force and Couple System: II