Related Experiment Video
Updated: Jul 17, 2025
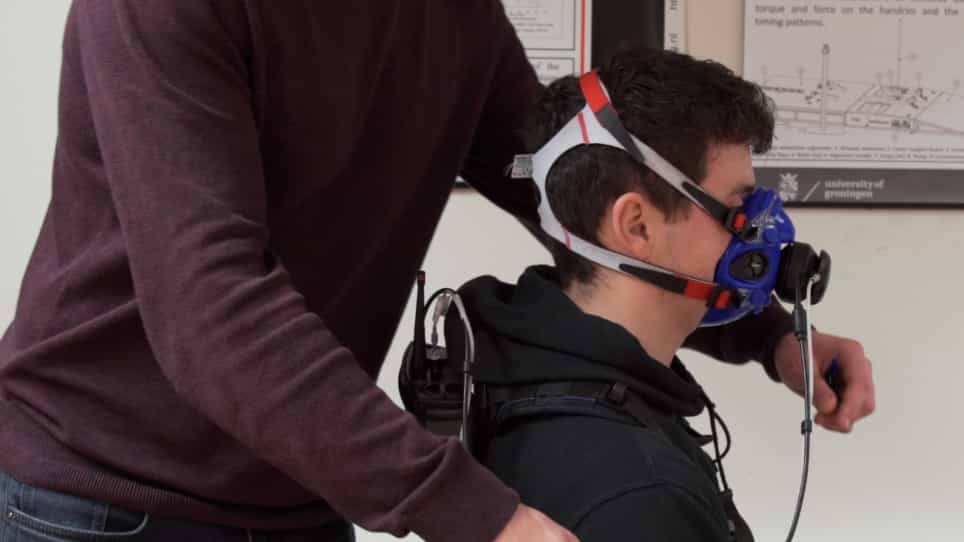

Determining and Controlling External Power Output During Regular Handrim Wheelchair Propulsion
Published on: February 5, 2020
Locomotion rhythm makes power and speed
A Bejan1, U Gunes2, H Almahmoud3,4
1Department of Mechanical Engineering and Materials Science, Duke University, Durham, NC, 27708-0300, USA. abejan@duke.edu.

Abstract:
This article addresses two questions, why certain animals (frogs, breaststroke swimmers, hovering fliers, jellyfish) push rapidly against the surrounding fluid and then reach forward slowly, and whether this rhythm of propulsion is a manifestation of the universal phenomenon of design evolution in nature. Emphasis is on the distribution of time periods of locomotion in which, during the driving phase of cyclic movement (the motive stroke, phases 1 and 2, in alternating sequence with the dissipative stroke, phase 3), the work is generated (phase 1) and dissipated (phase 2). The relative lengths of the characteristic times t1 and t2 of the phases 1 and 2, are predicted. The relative duration of the proposed three phases of a cycle is the 'rhythm'. The analysis is based on a model of how the effective cross-sections of the stroking body parts impact the surrounding medium, water, or air, and the total power required to account for the kinetic energy losses during phases 2 and 3, which are due to drag forces posed by the surrounding medium. The body configuration (limbs' cross-sections) determines the limbs' velocities that maximize mean power, and the times t1 and t2 within the motive stroke. Emphasis is placed on the freedom to change the evolving design. Freedom is represented in two ways: the number of degrees of freedom in changing the dimensions of the model and its deformation in time, and the effect that evolutionary changes have on the access that the body has to its available space. Freedom to change the locomotion design leads to greater power and speed.
More Related Videos
 10:28
Kinematics and Ground Reaction Force Determination: A Demonstration Quantifying Locomotor Abilities of Young Adult, Middle-aged, and Geriatric Rats
Published on: February 22, 2011
 10:52
Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
Related Concept Videos
 01:10
Relative Motion Analysis - Acceleration
 01:21
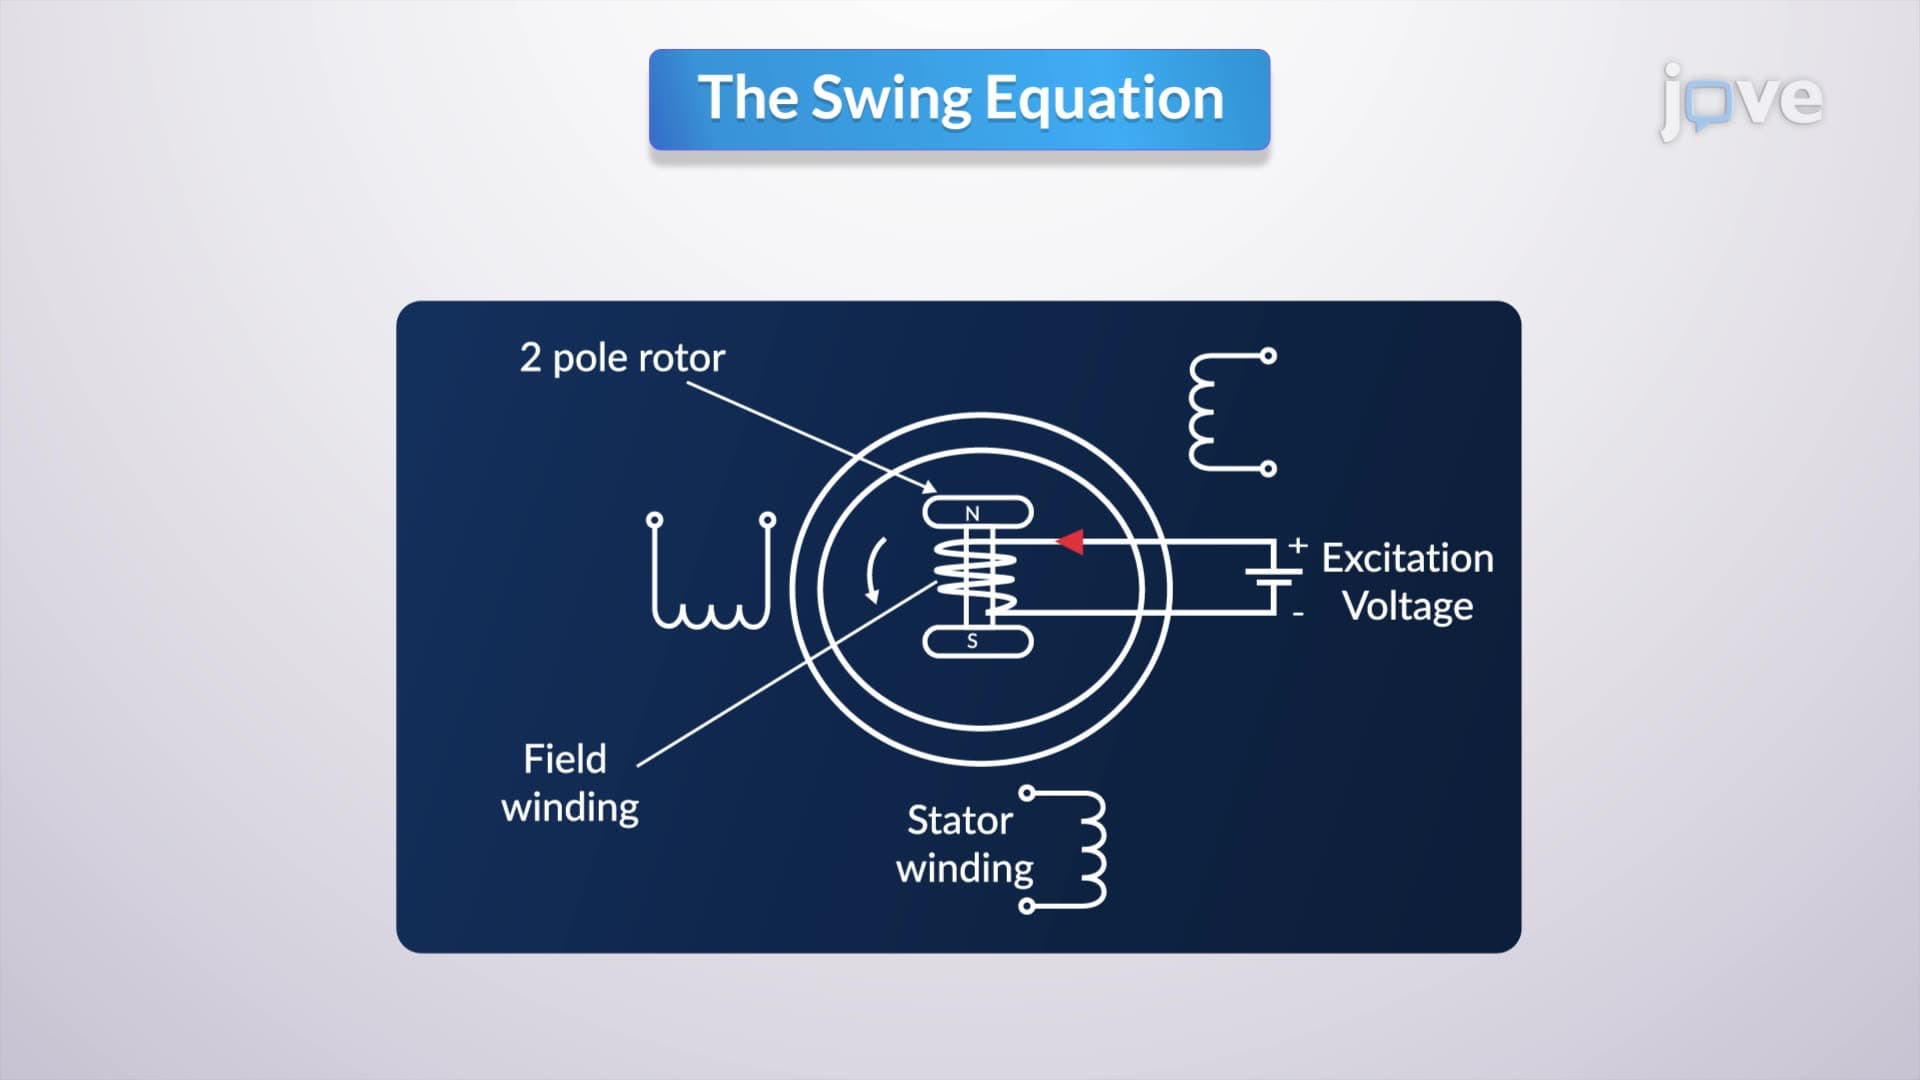
The Swing Equation
In a steady-state operation, the mechanical torque (Τm) supplied to the generator is balanced by the electrical torque...
 00:57
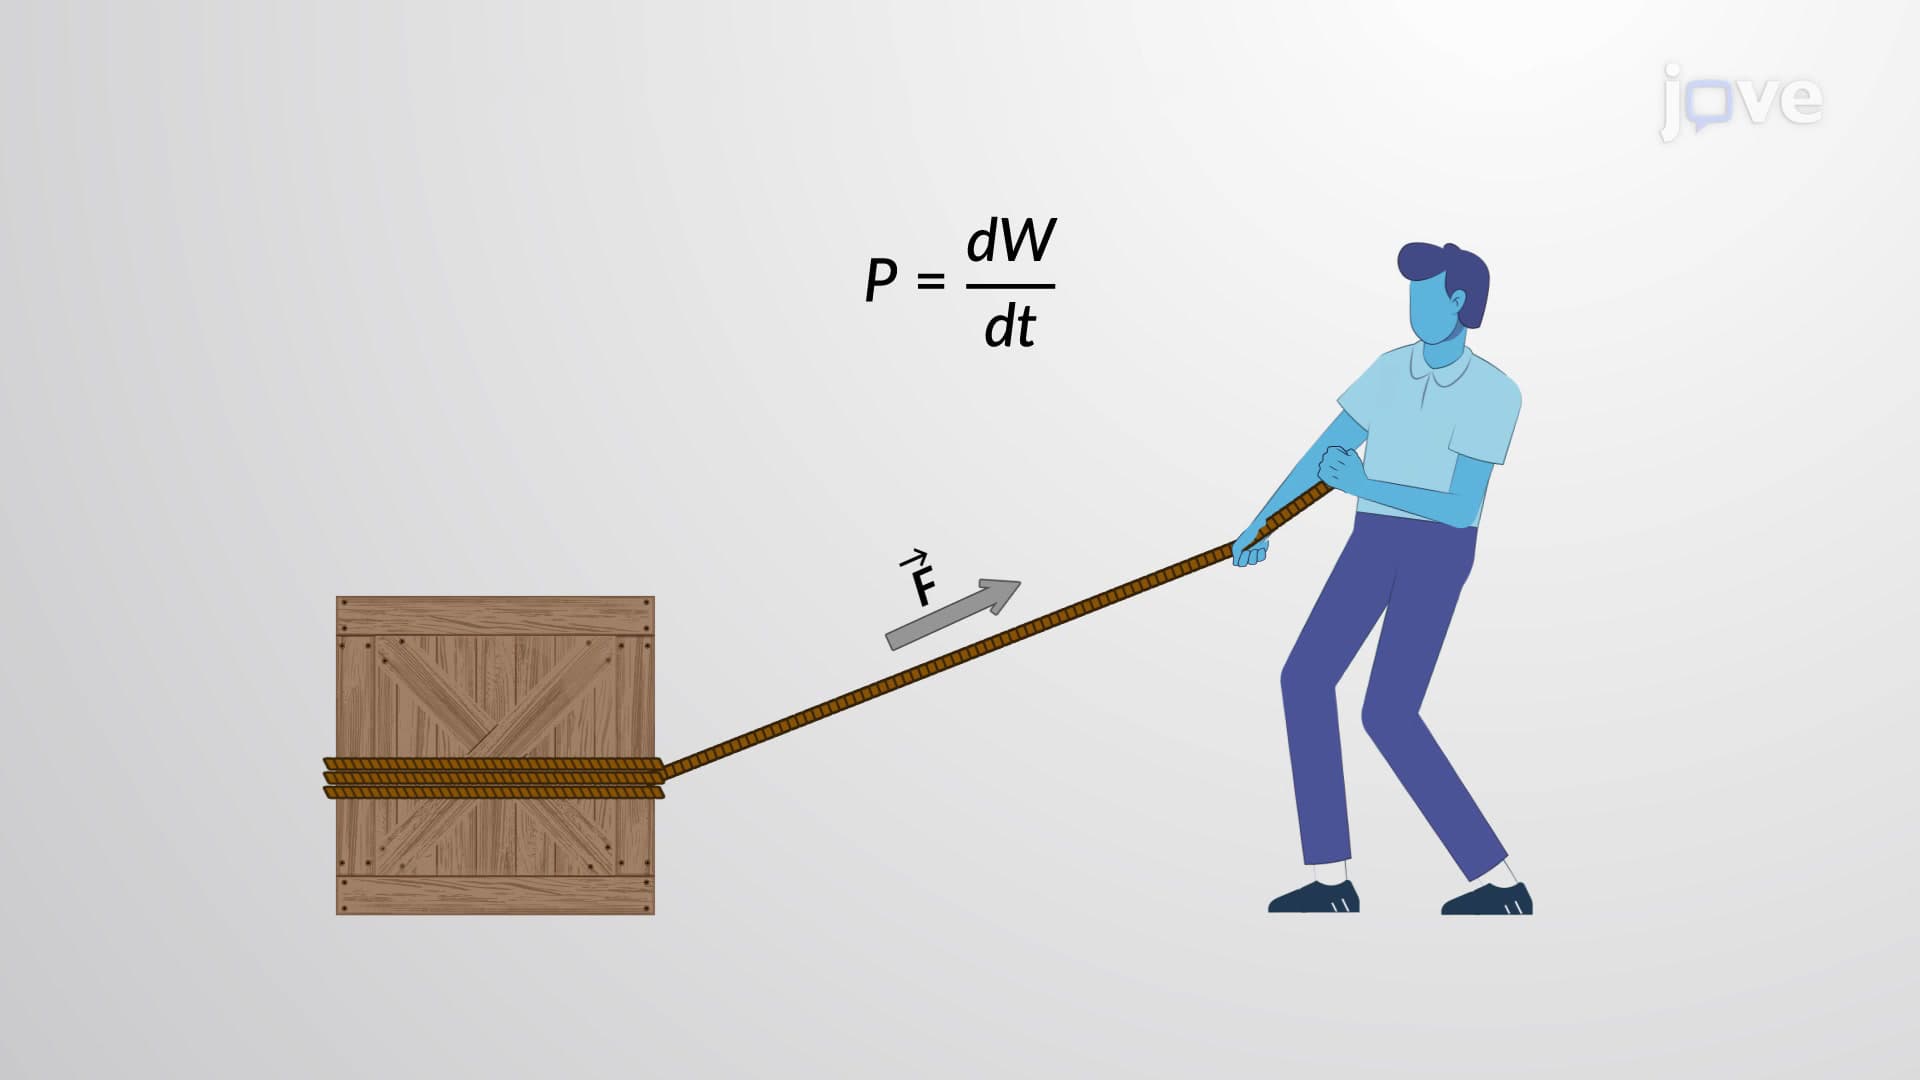
Power Expended by a Constant Force
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:27
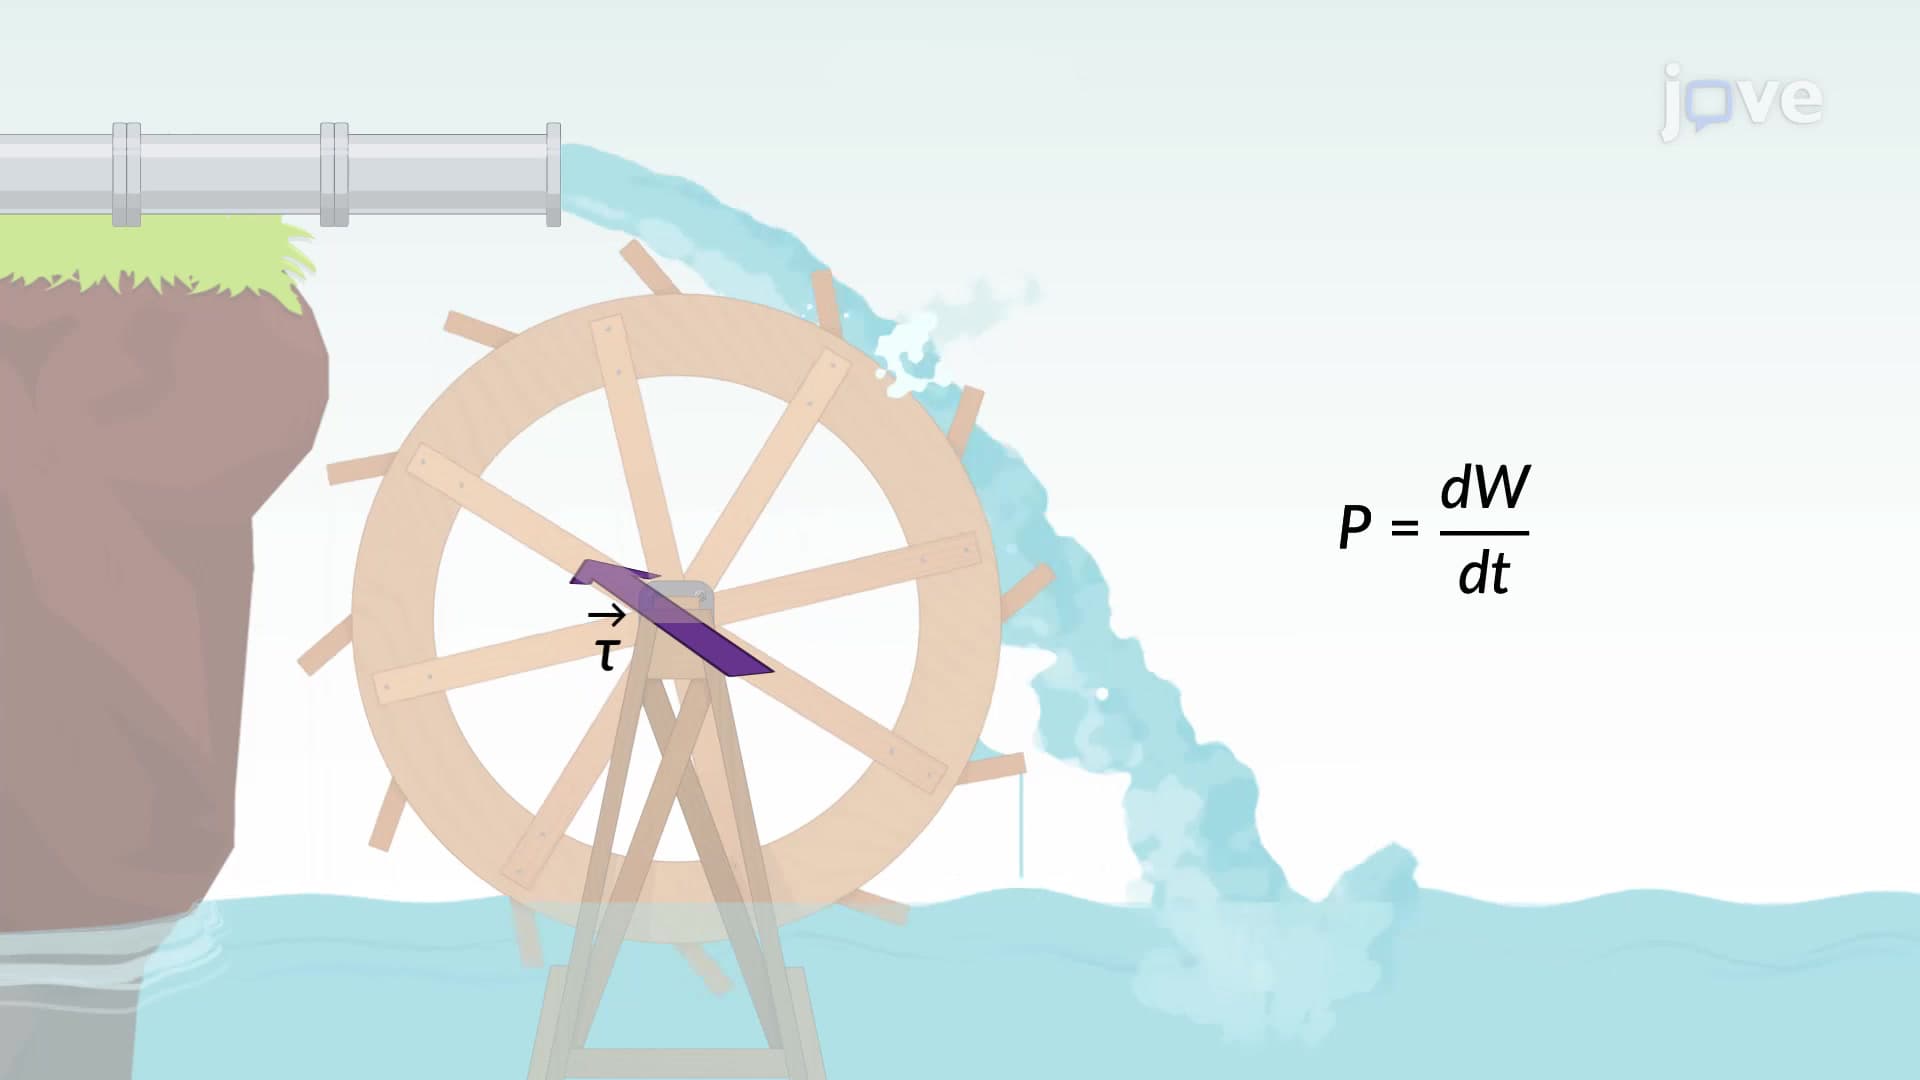
Work and Power for Rotational Motion
Similarly, the power delivered to a system that is rotating about a fixed axis...
 01:08
Power