Related Experiment Video
Updated: Jul 17, 2025

Operant Learning of Drosophila at the Torque Meter
Published on: June 16, 2008
Champion-level drone racing using deep reinforcement learning
Elia Kaufmann1, Leonard Bauersfeld2, Antonio Loquercio2
1Robotics and Perception Group, University of Zurich, Zürich, Switzerland. ekaufmann@ifi.uzh.ch.

Abstract:
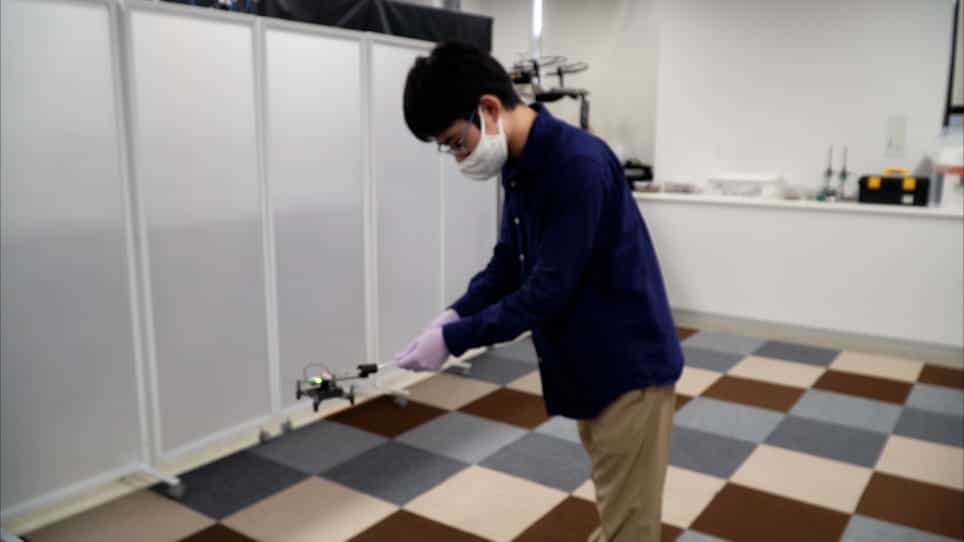
First-person view (FPV) drone racing is a televised sport in which professional competitors pilot high-speed aircraft through a 3D circuit. Each pilot sees the environment from the perspective of their drone by means of video streamed from an onboard camera. Reaching the level of professional pilots with an autonomous drone is challenging because the robot needs to fly at its physical limits while estimating its speed and location in the circuit exclusively from onboard sensors1. Here we introduce Swift, an autonomous system that can race physical vehicles at the level of the human world champions. The system combines deep reinforcement learning (RL) in simulation with data collected in the physical world. Swift competed against three human champions, including the world champions of two international leagues, in real-world head-to-head races. Swift won several races against each of the human champions and demonstrated the fastest recorded race time. This work represents a milestone for mobile robotics and machine intelligence2, which may inspire the deployment of hybrid learning-based solutions in other physical systems.
More Related Videos
Related Concept Videos
 01:23
Reinforcement
Positive reinforcement occurs when a behavior is followed by the presentation of a rewarding stimulus, increasing the frequency of that behavior. For example:
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:12
Observational Learning
 01:24
Reinforcement Schedules
Once a behavior is learned,...
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 01:17
Rolling Resistance: Problem Solving