Related Experiment Video
Updated: Jul 16, 2025

Author Spotlight: Three-Dimensional Cephalometric Landmark Annotation Demonstration on Human Cone Beam Computed Tomography Scans
Published on: September 8, 2023
The life and legacy of John Robert Cobb: the man behind the angle
Kathleen S Botterbush1, Justin K Zhang2, Pranav S Chimakurty1
11Department of Surgery, Division of Neurological Surgery, Saint Louis University School of Medicine, St. Louis, Missouri; and.

Insights
Dr. John Robert Cobb pioneered scoliosis care by establishing the first specialty clinic and developing key surgical innovations like the Cobb angle. His work significantly advanced spine surgery and scoliosis treatment.
Area of Science:
- Spine Surgery
- Orthopedics
- Medical History
Background:
- Dr. John Robert Cobb's fellowship at the Hospital for Special Surgery in 1934.
- The challenge to establish the first scoliosis specialty clinic.
- Cobb's critical review of existing scoliosis treatments and meticulous record-keeping.
Purpose of the Study:
- To provide a comprehensive analysis of Dr. John R. Cobb's life and career.
- To examine his significant contributions to spine surgery and scoliosis care.
- To highlight the lasting impact of his innovations, such as the Cobb angle.
Main Methods:
- Historical analysis of Dr. Cobb's career and academic legacy.
- Review of his meticulous records of diagnoses, treatments, and radiographs.
- Examination of the historical context of his contributions to spine surgery.
Main Results:
- Establishment of the first scoliosis specialty clinic.
- Development of the Cobb angle and Cobb elevator, crucial tools in spine surgery.
- Significant advancements in the understanding and treatment of scoliosis.
Conclusions:
- Dr. John R. Cobb's work laid foundational principles for modern scoliosis treatment.
- His innovations continue to be highly relevant in contemporary spine surgery.
- This analysis offers the first comprehensive look at Cobb's life, career, and legacy.
Abstract:
In 1934, Dr. John Robert Cobb moved to New York to serve as the Gibney Orthopedic Fellow at the Hospital for the Ruptured and Crippled, now known as the Hospital for Special Surgery. In this role, Cobb was faced with a unique task that would shape not only his personal career but also the fields of scoliosis and spine care: to design the first scoliosis specialty clinic. He critically reviewed the treatment methods for scoliosis outlined by prior pioneers in spine surgery and kept his own meticulous records of diagnoses, treatments, and radiographs. Cobb's work culminated in major contributions to spine surgery that are highly relevant to this day, including the Cobb angle and the Cobb elevator. In this detailed analysis of the career and academic legacy of Dr. John R. Cobb, the authors examine in detail the historical events surrounding Cobb's great contributions to spine surgery and their lasting impact on our specialty, as well as unique aspects of his personal life. This historical vignette constitutes the first comprehensive analysis of the life, career, and academic legacy of Dr. John R. Cobb, the man behind the angle.
Related Concept Videos
 01:15
Unsymmetric Bending - Angle of Neutral Axis
When a bending moment is applied at an angle θ concerning the vertical axis of a symmetrical member, it can be resolved into components along the member's principal...
 01:13
Angle of Twist: Problem Solving
 01:16
Perpendicular-Axis Theorem
Consider a circular disc of mass M and radius R lying along an x-y plane. The origin lies at the center of the disc, and the z-axis is perpendicular to the disc's plane. All three axes coincide at the disc's center. The moment of inertia of this...
 01:29
Life Histories
 01:11
Angular Momentum about an Arbitrary Axis
The velocity of a mass element comprises its translational velocity and the relative velocity instigated by the body's rotation. Substituting the velocity equation into...
 01:13
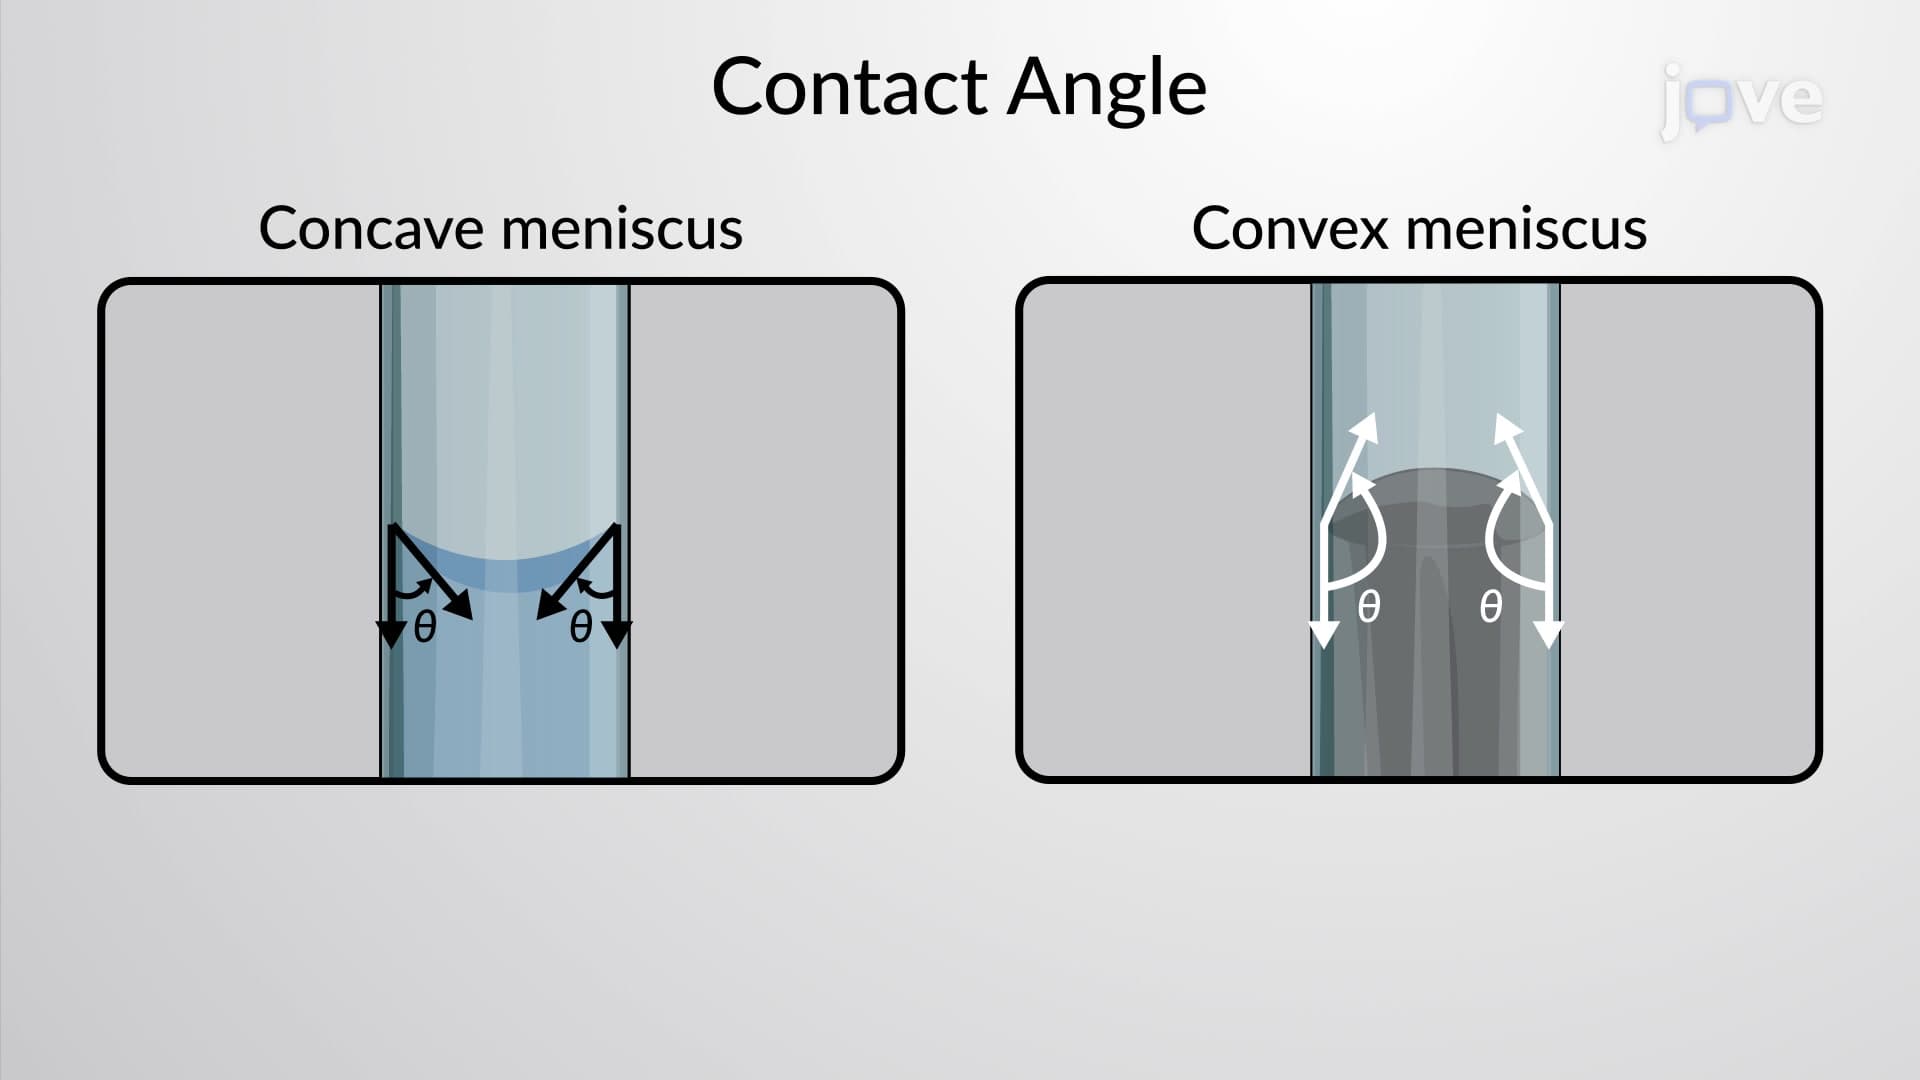
Contact Angle
The adhesive force is the molecular force between molecules of different materials, that is, between the molecules of the solid and the liquid. The cohesive...