Continuous Motion Estimation of Knee Joint Based on a Parameter Self-Updating Mechanism Model
Related Experiment Video
Updated: Jul 15, 2025
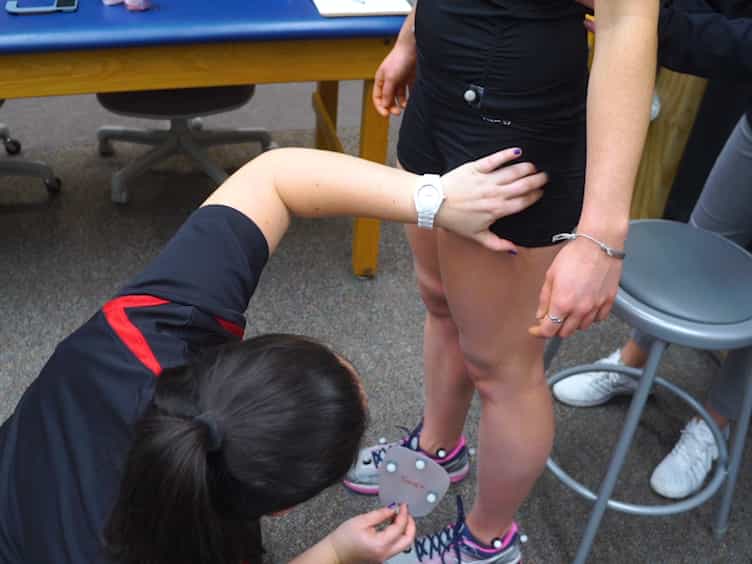
Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
Jiayi Li1, Kexiang Li2, Jianhua Zhang3
1School of Mechanical Engineering, Hebei University of Technology, Tianjin 300401, China.

Abstract:
Estimation of continuous motion of human joints using surface electromyography (sEMG) signals has a critical part to play in intelligent rehabilitation. Traditional methods always use sEMG signals as inputs to build regression or biomechanical models to estimate continuous joint motion variables. However, it is challenging to accurately estimate continuous joint motion in new subjects due to the non-stationarity and individual differences in sEMG signals, which greatly limits the generalisability of the method. In this paper, a continuous motion estimation model for the human knee joint with a parameter self-updating mechanism based on the fusion of particle swarm optimization (PSO) and deep belief network (DBN) is proposed. According to the original sEMG signals of different subjects, the method adaptively optimized the parameters of the DBN model and completed the optimal reconstruction of signal feature structure in high-dimensional space to achieve the optimal estimation of continuous joint motion. Extensive experiments were conducted on knee joint motions. The results suggested that the average root mean square errors (RMSEs) of the proposed method were 9.42° and 7.36°, respectively, which was better than the results obtained by common neural networks. This finding lays a foundation for the human-robot interaction (HRI) of the exoskeleton robots based on the sEMG signals.
More Related Videos
Related Concept Videos
 01:18
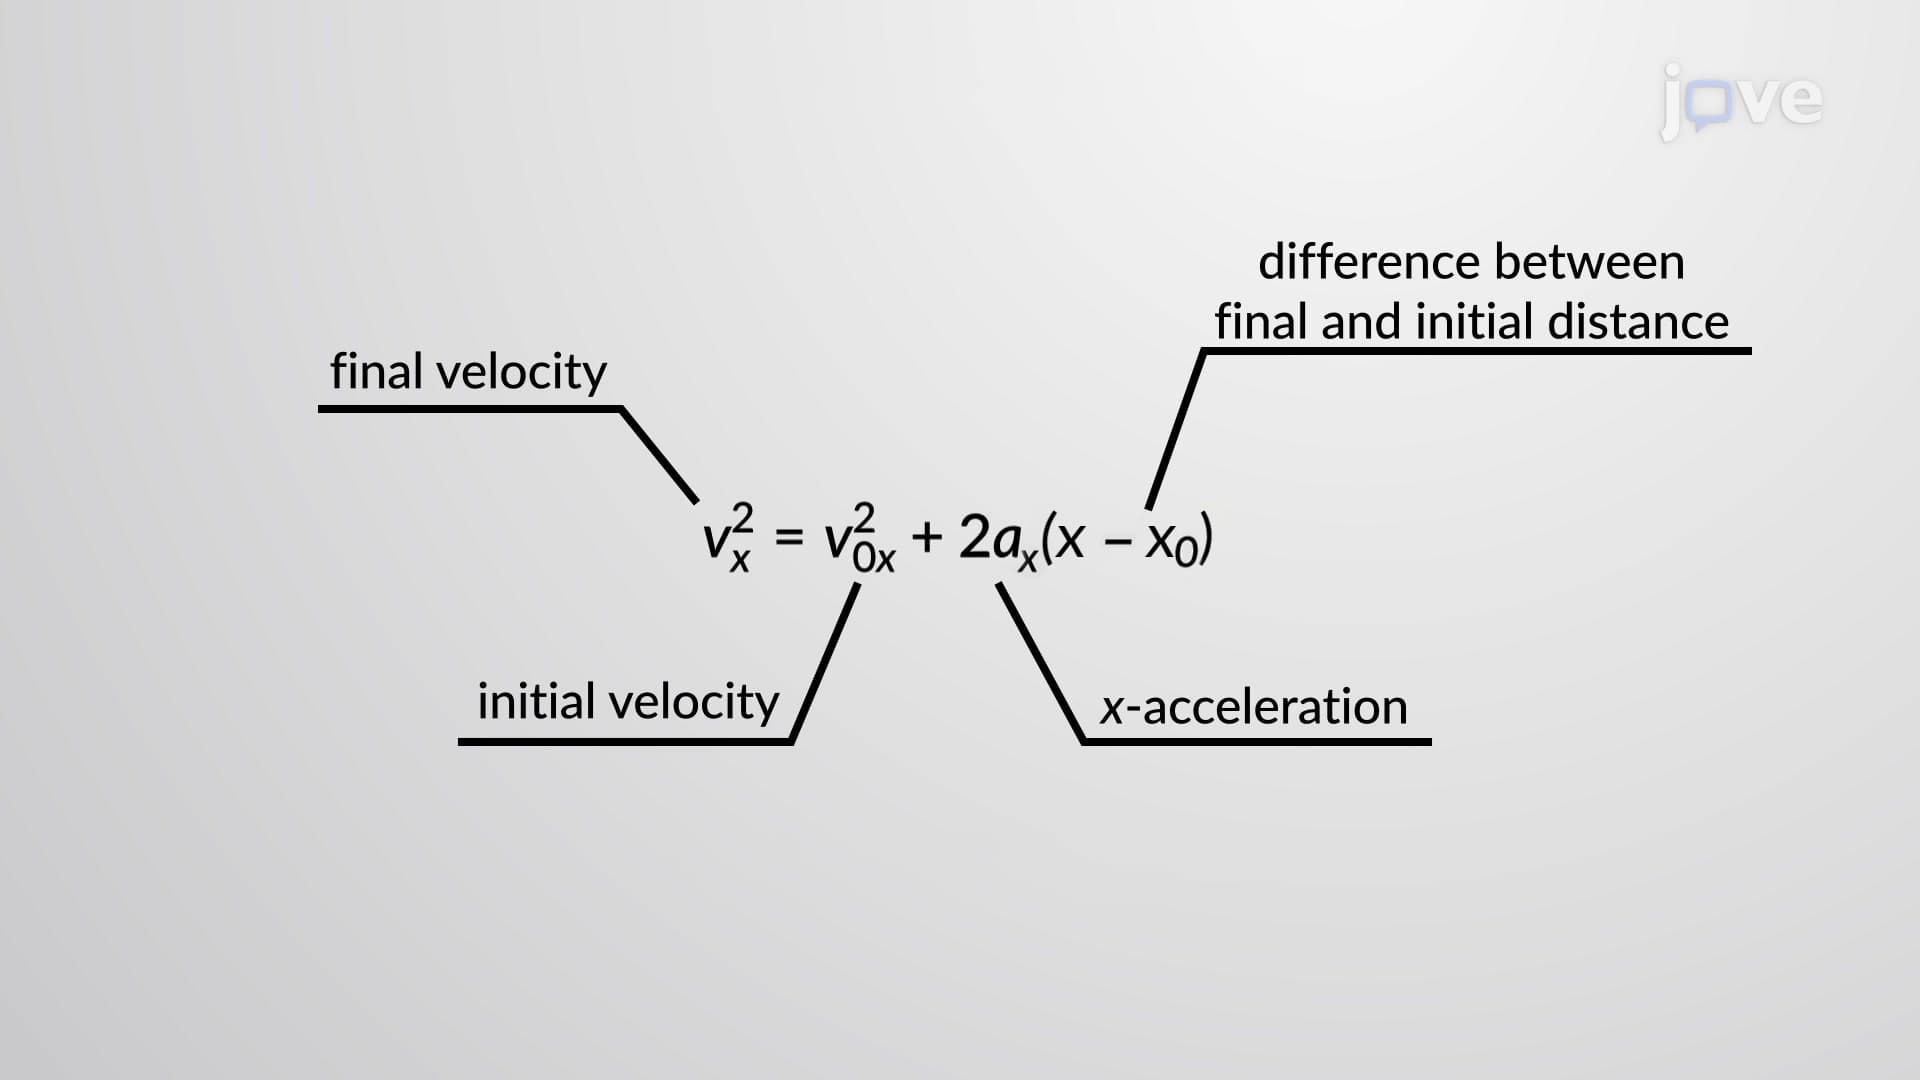
Kinematic Equations - III
Using the kinematic equations,...
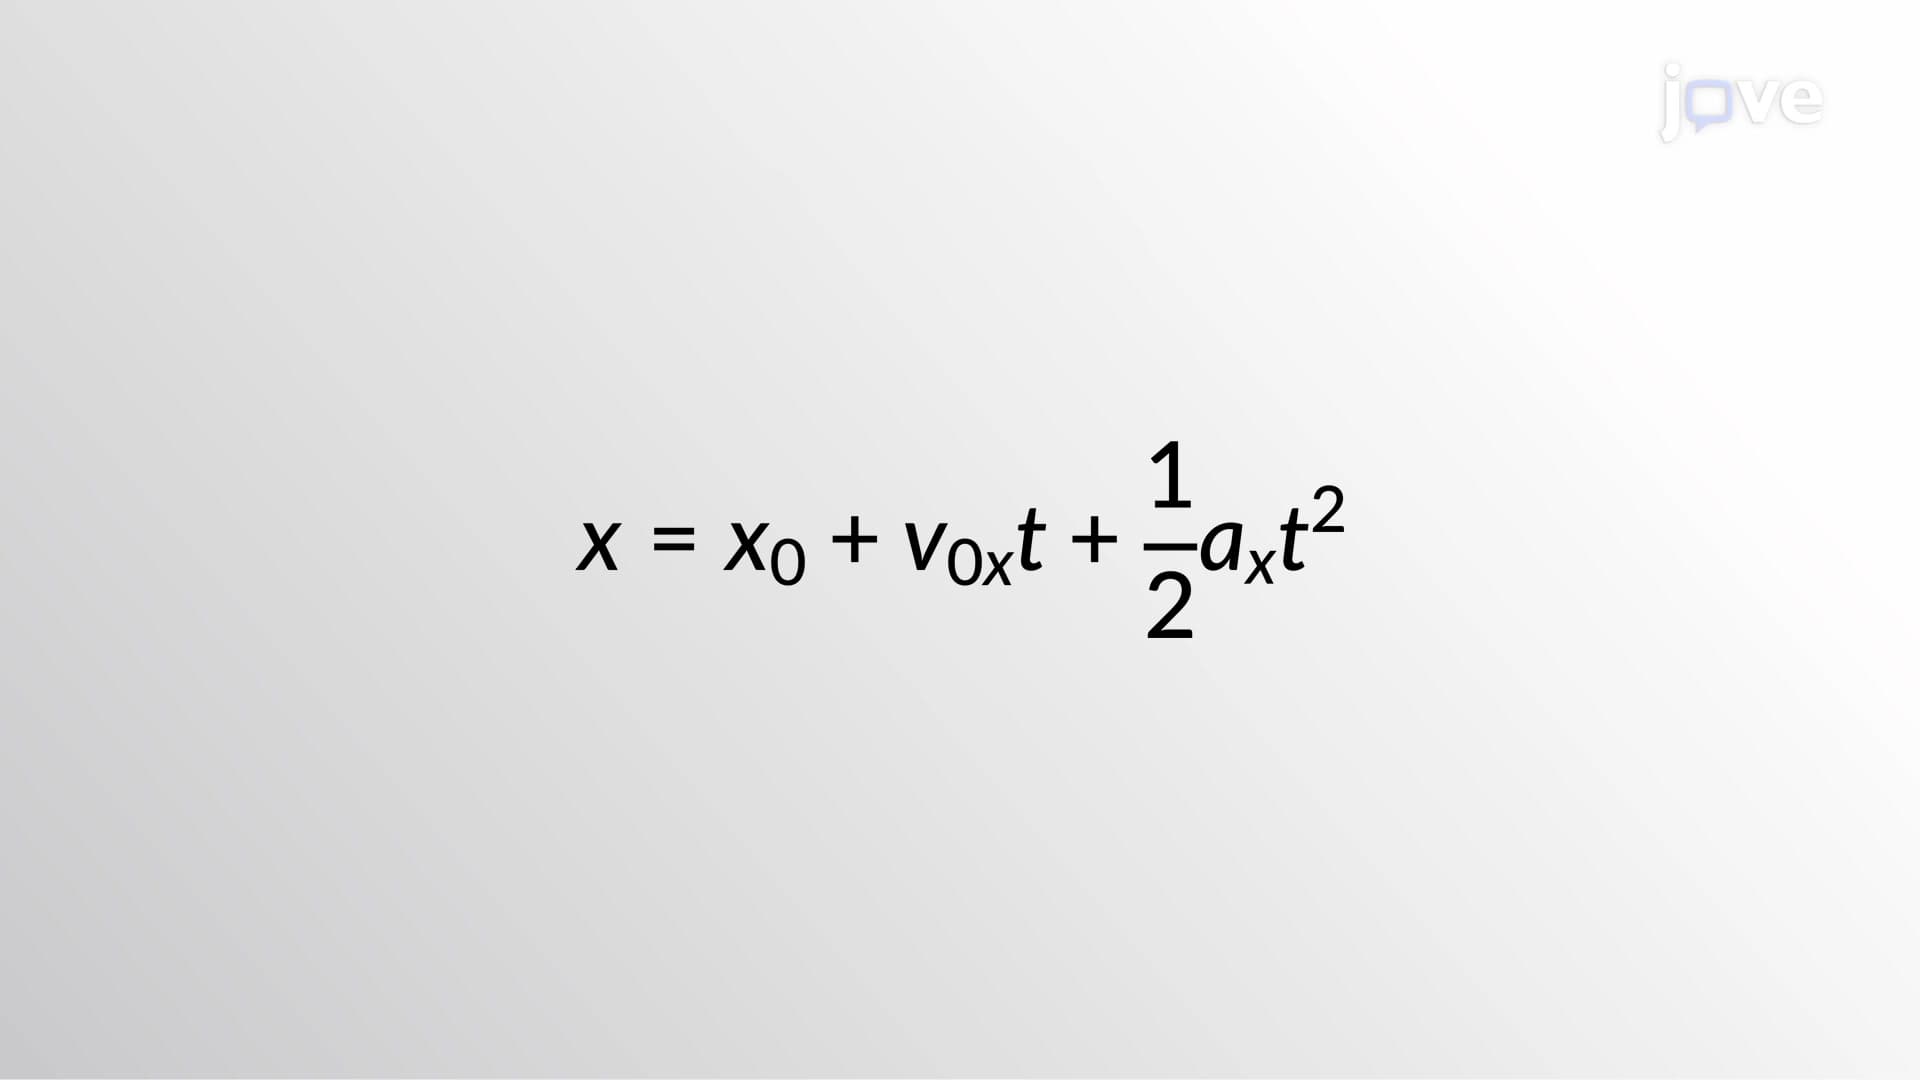 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
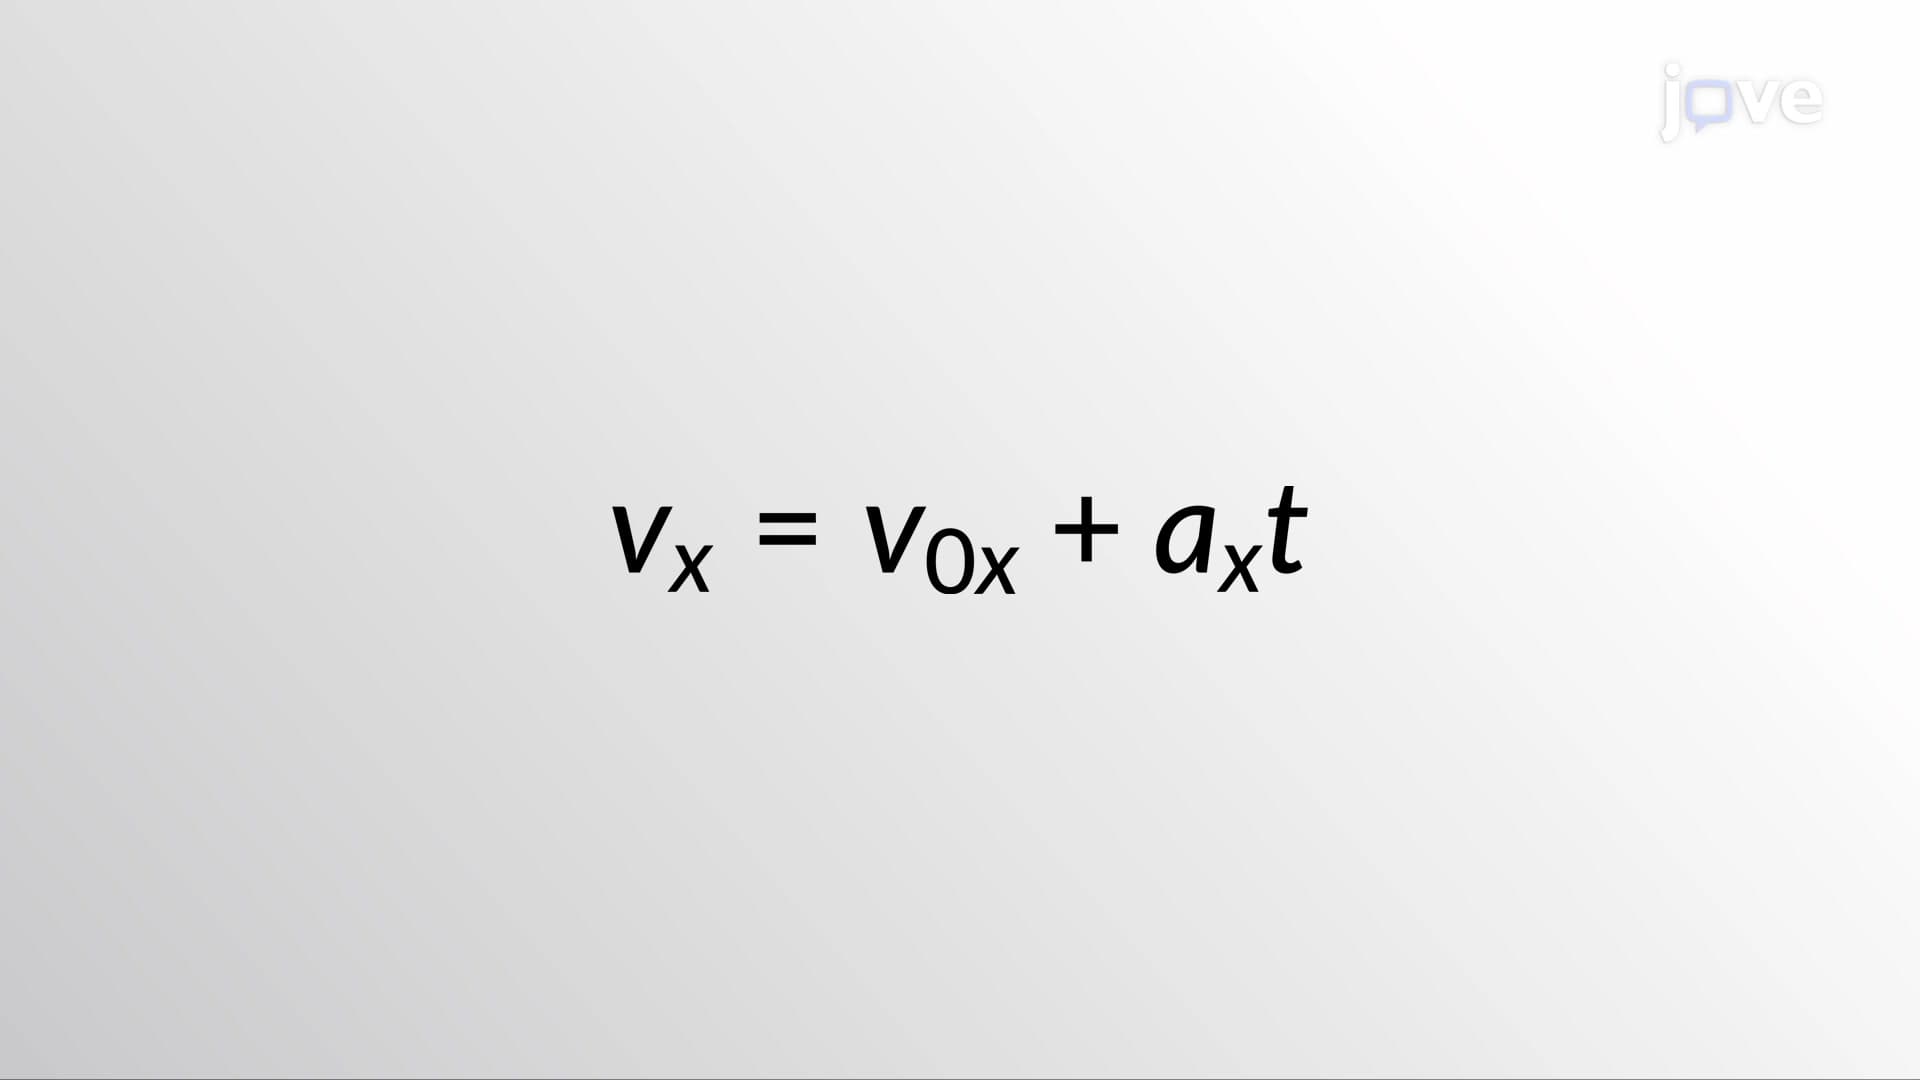 01:26
Kinematic Equations - I
 01:15
Kinematic Equations: Problem Solving
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...