Related Experiment Video
Updated: Jul 15, 2025


Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
Periodic Intermittent Adaptive Control with Saturation for Pinning Quasi-Consensus of Heterogeneous Multi-Agent
Bin Du1, Quan Xu1, Junfu Zhang1
1School of Mechanical Engineering, Xihua University, Chengdu 610039, China.

Abstract:
A periodic intermittent adaptive control method with saturation is proposed to pin the quasi-consensus of nonlinear heterogeneous multi-agent systems with external disturbances in this paper. A new periodic intermittent adaptive control protocol with saturation is designed to control the internal coupling between the follower agents and the feedback gain between the leader and the follower. In particular, we use the saturation adaptive law: when the quasi-consensus error converges to a certain range, the adaptive coupling edge weight and the adaptive feedback gain will not be updated. Furthermore, we propose three saturated adaptive pinning control protocols. The quasi-consensus is achieved through its own pinning as long as the agents remain connected to each other. Using the Lyapunov function method and inequality technique, the convergence range of the quasi-consensus error of a heterogeneous multi-agent system is obtained. Finally, the rationality of the proposed control protocol is verified through numerical simulation. Theoretical derivation and simulation results show that the novel proposed periodic intermittent adaptive control method with saturation can successfully be used to achieve the pinning of quasi-consensus of nonlinear heterogeneous multi-agent systems.


Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:59
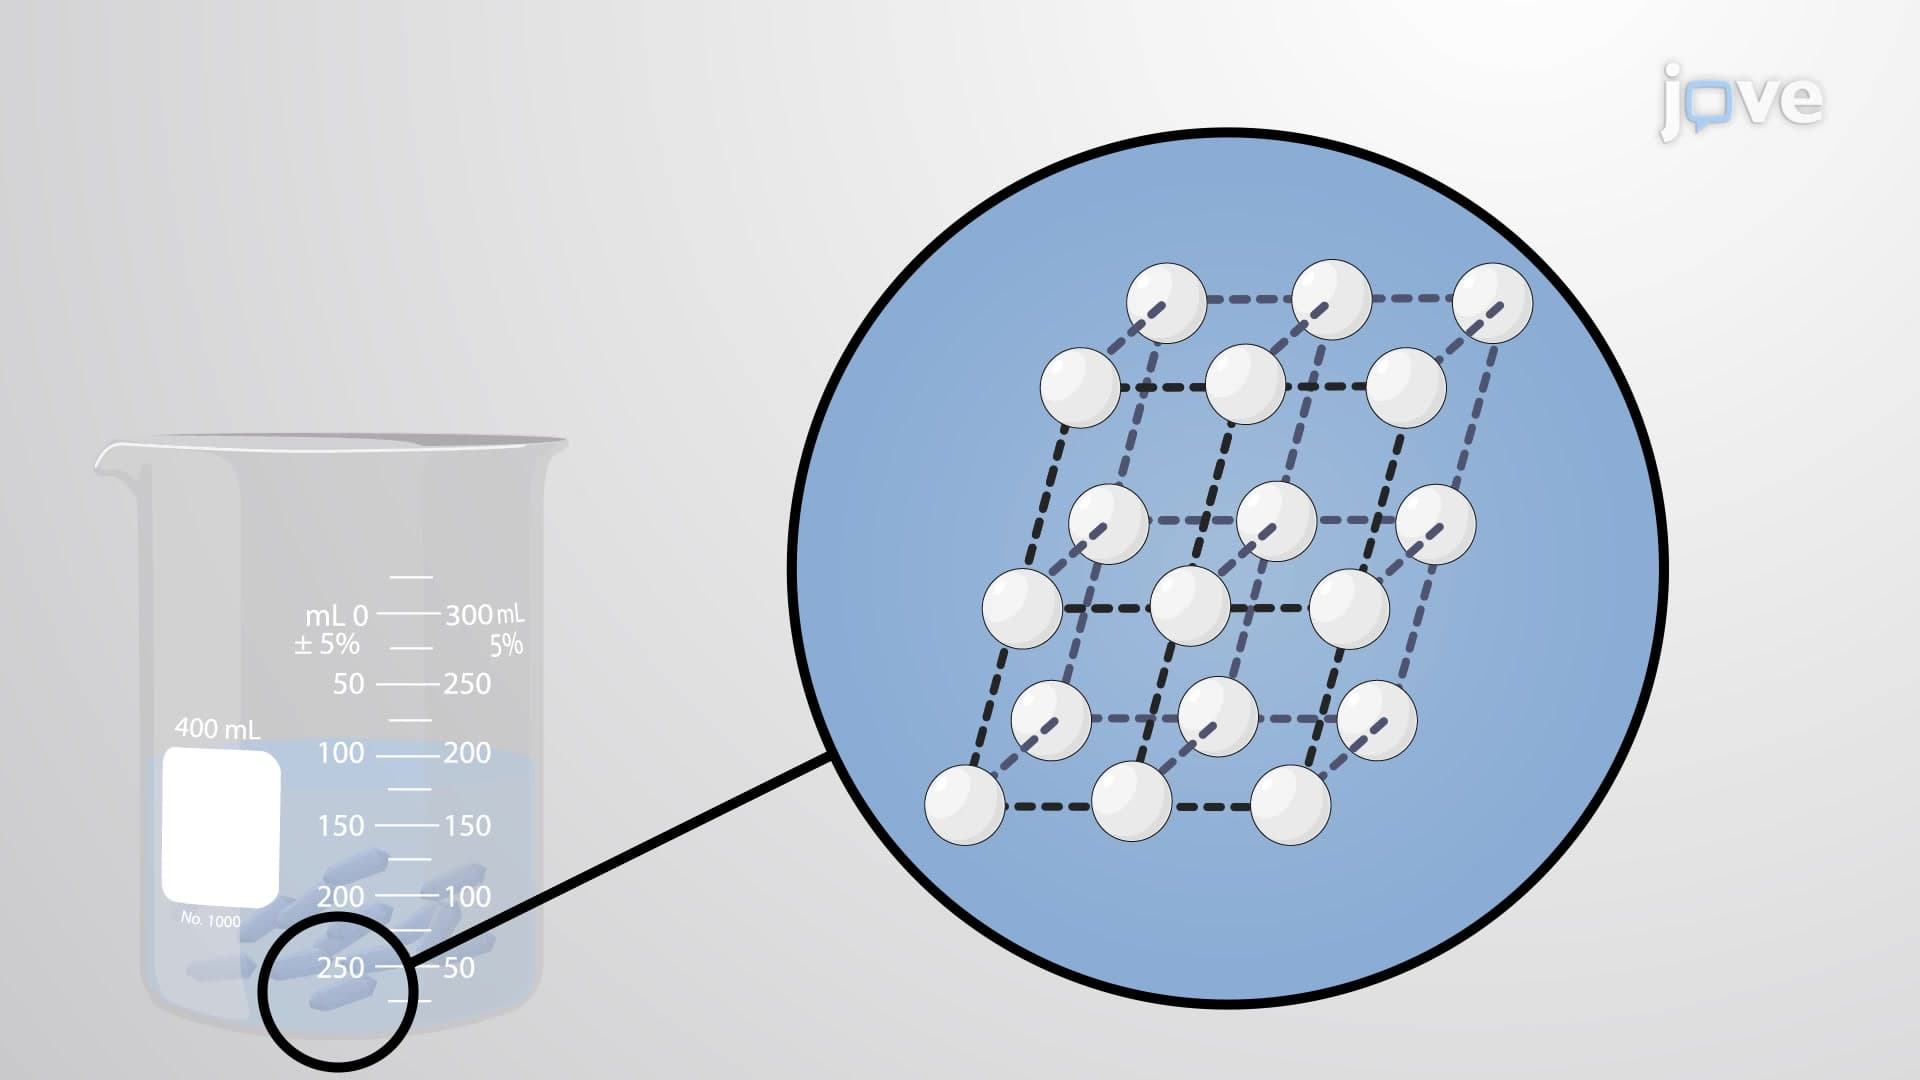
Solution Equilibrium and Saturation
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:10
Control Systems
At the heart...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...