Related Experiment Video
Updated: Jul 15, 2025
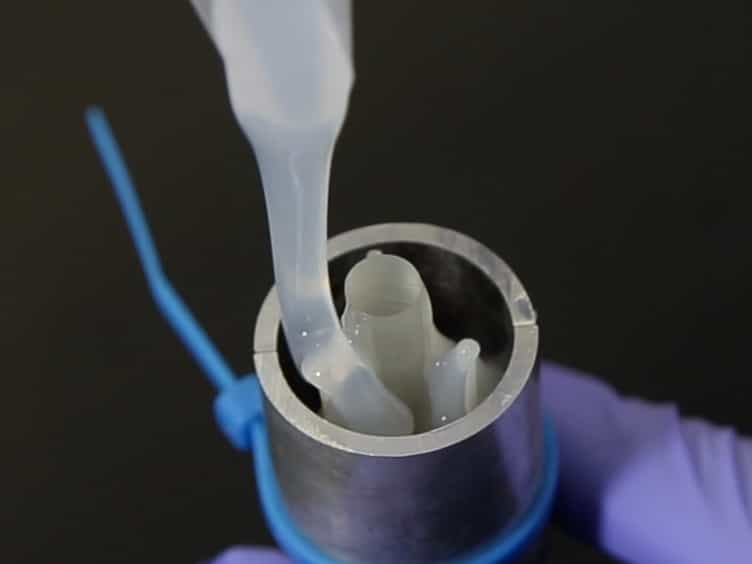
Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
A Novel Extensible Continuum Robot with Growing Motion Capability Inspired by Plant Growth for Path-Following in
Yuhao Xu1, Dezhi Song1, Zhiqiang Zhang2
1Key Laboratory of Mechanism Theory and Equipment Design of Ministry of Education, School of Mechanical Engineering, Tianjin University, Tianjin, China.

Abstract:
This article presents a novel extensible continuum robot (ECR) with growing motion capability for improved flexible access in transoral laryngeal procedures. The robot uses an extensible continuum joint with a staggered V-shaped notched structure as the backbone, driven by the pushing and pulling of superelastic Nitinol rods. The notched structure is optimized to achieve a wide range of extension/contraction and bending motion for the continuum joint. The successive and uniform deflection of the notches provides the continuum joint with excellent constant curvature bending characteristics. The bidirectional rod-driven approach expands the robot's extension capabilities with both pushing and pulling operations, and the superelasticity of the driving rods preserves the robot's bending performance. The ECR significantly increases motion dexterity and reachability through its variable length, which facilitates collision-free access to deep lesions by following the anatomy. To further exploit the advantages of the ECR in path-following for flexible access, a growing motion approach inspired by the plant growth process has been proposed to minimize the path deviation error. Characterization experiments are conducted to verify the performances of the proposed ECR. The extension ratio achieves up to 225.92%, and the average distal positioning error and hysteresis error values are 2.87% and 0.51% within the ±120° bending range. Compared with the typical continuum robot with a fixed length, the path-following deviation of this robot is reduced by more than 58.30%, effectively reducing the risk of collision during access. Phantom experiments validate the feasibility of the proposed concept in flexible access procedures.
Related Concept Videos
 01:25
Suctioning the Oropharyngeal Airway
After assembling the equipment, the nurse should practice hand hygiene and don appropriate PPE according to infection control guidelines to avoid the...
 01:29
Suctioning the Nasopharyngeal Airway
Equipment Required
 01:24
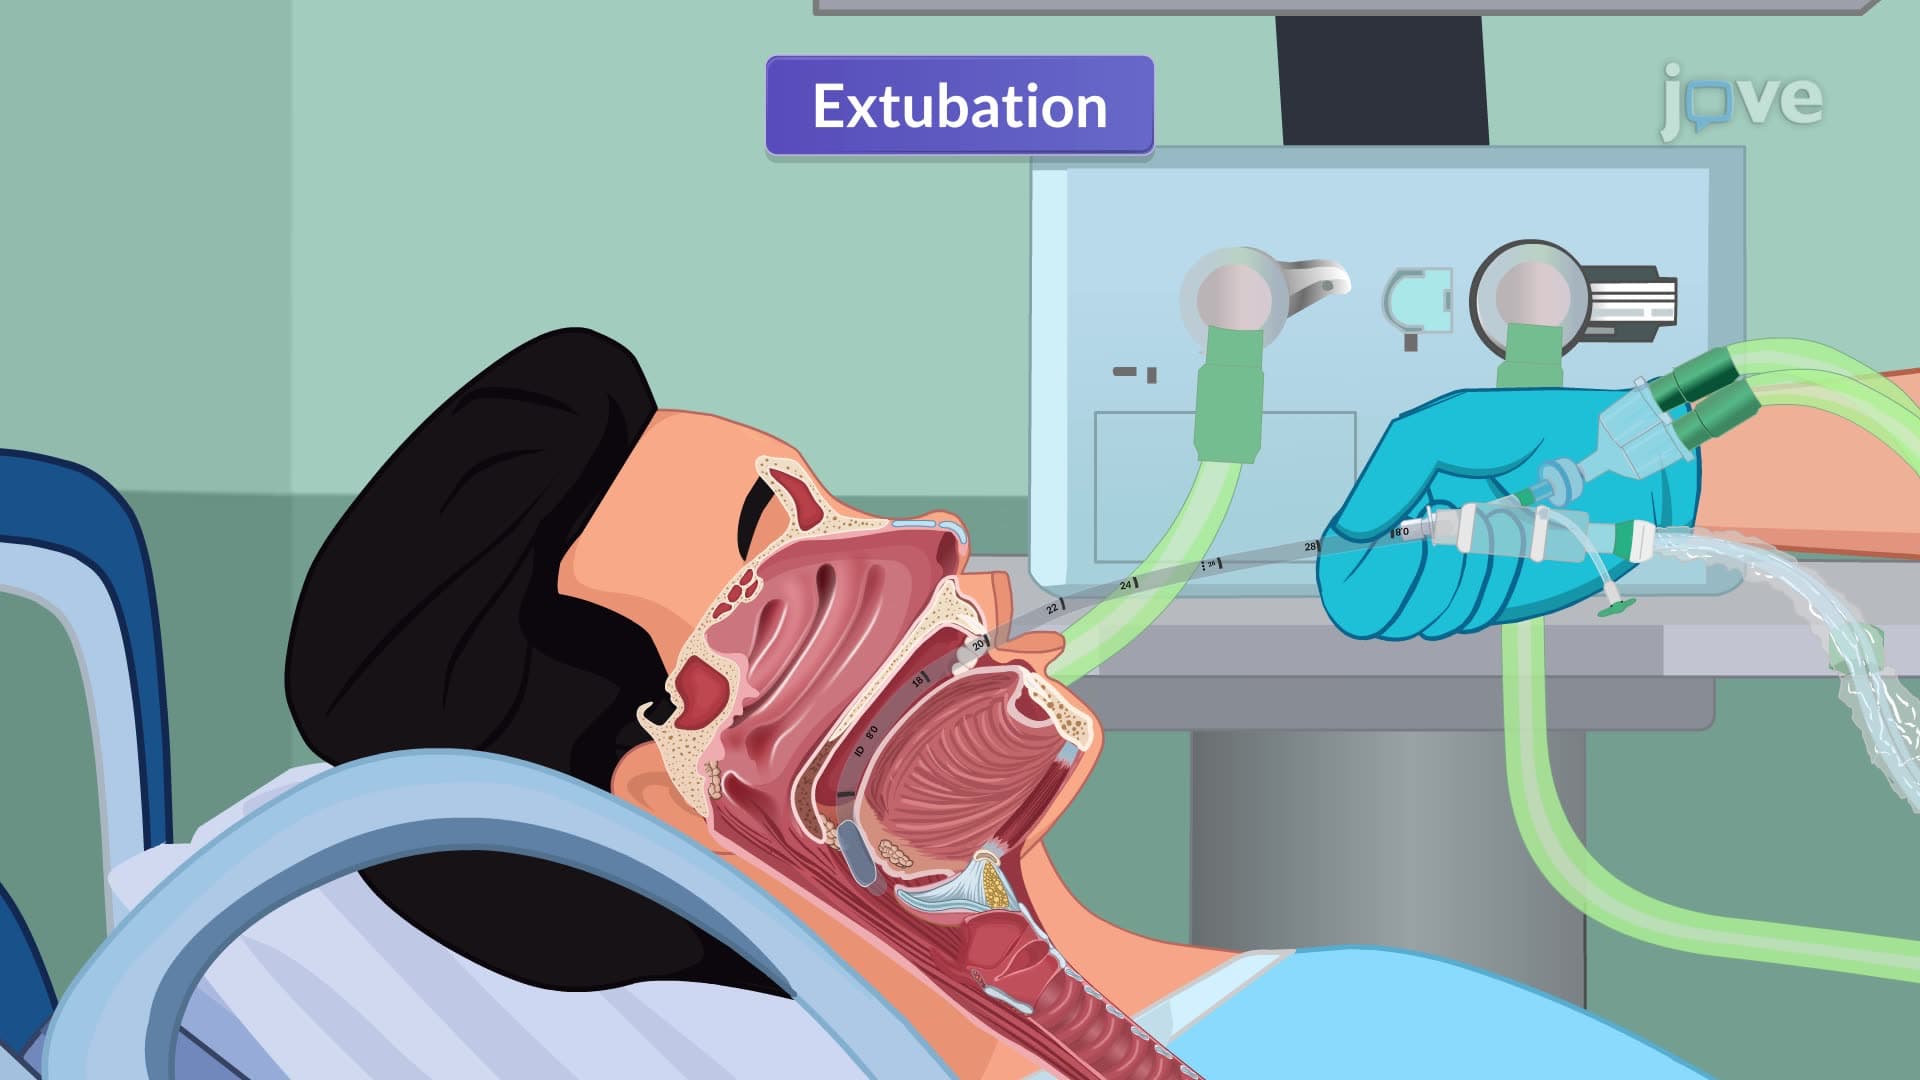
Endotracheal Tube Extubation
Procedure
Extubation removes the endotracheal tube (ETT) from the patient on mechanical ventilation. It requires a well-coordinated, multidisciplinary approach involving physicians, nurses, respiratory therapists, and other healthcare professionals....
 01:23
Oxygen Delivering System III: Tracheostomy and T-piece
Tracheostomy
A tracheostomy is a surgically created opening (stoma) in the anterior part of the trachea. It is used to establish a patient airway, bypass an upper airway obstruction, simplify the removal of secretions, permit long-term...
 01:26
Tracheostomy Suctioning I: Pre-Procedural Steps
Equipment Required
First, gather all necessary equipment: a sterile suction catheter, a sterile disposable container, sterile gloves, a towel or...
 01:23
Tracheostomy Suctioning II: Procedure