Adaptive cooperative guidance with seeker-less followers: A position coordination-based framework
Related Experiment Video
Updated: Jul 15, 2025

Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
1School of Astronautics, Northwestern Polytechnical University, Xi'an 710072, China.

Abstract:
This paper addresses the problem of cooperative guidance for multiple flight vehicles, comprising a leader and seeker-less followers. All the flight vehicles are required to hit the target simultaneously at a desired impact time, even though the target information is unavailable to the followers. To achieve this, a fixed-time convergent guidance law is proposed for the leader, incorporating impact time control. We introduce an adaptive cooperative guidance strategy for the seeker-less followers through coordinated position location relative to the leader. The simulation results validate the effectiveness satisfactorily coinciding with the theoretical analysis.
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Types of Global Positioning System Surveys
 01:28
Field Application of Global Positioning System
 01:03
Inertial Frames of Reference
 01:27
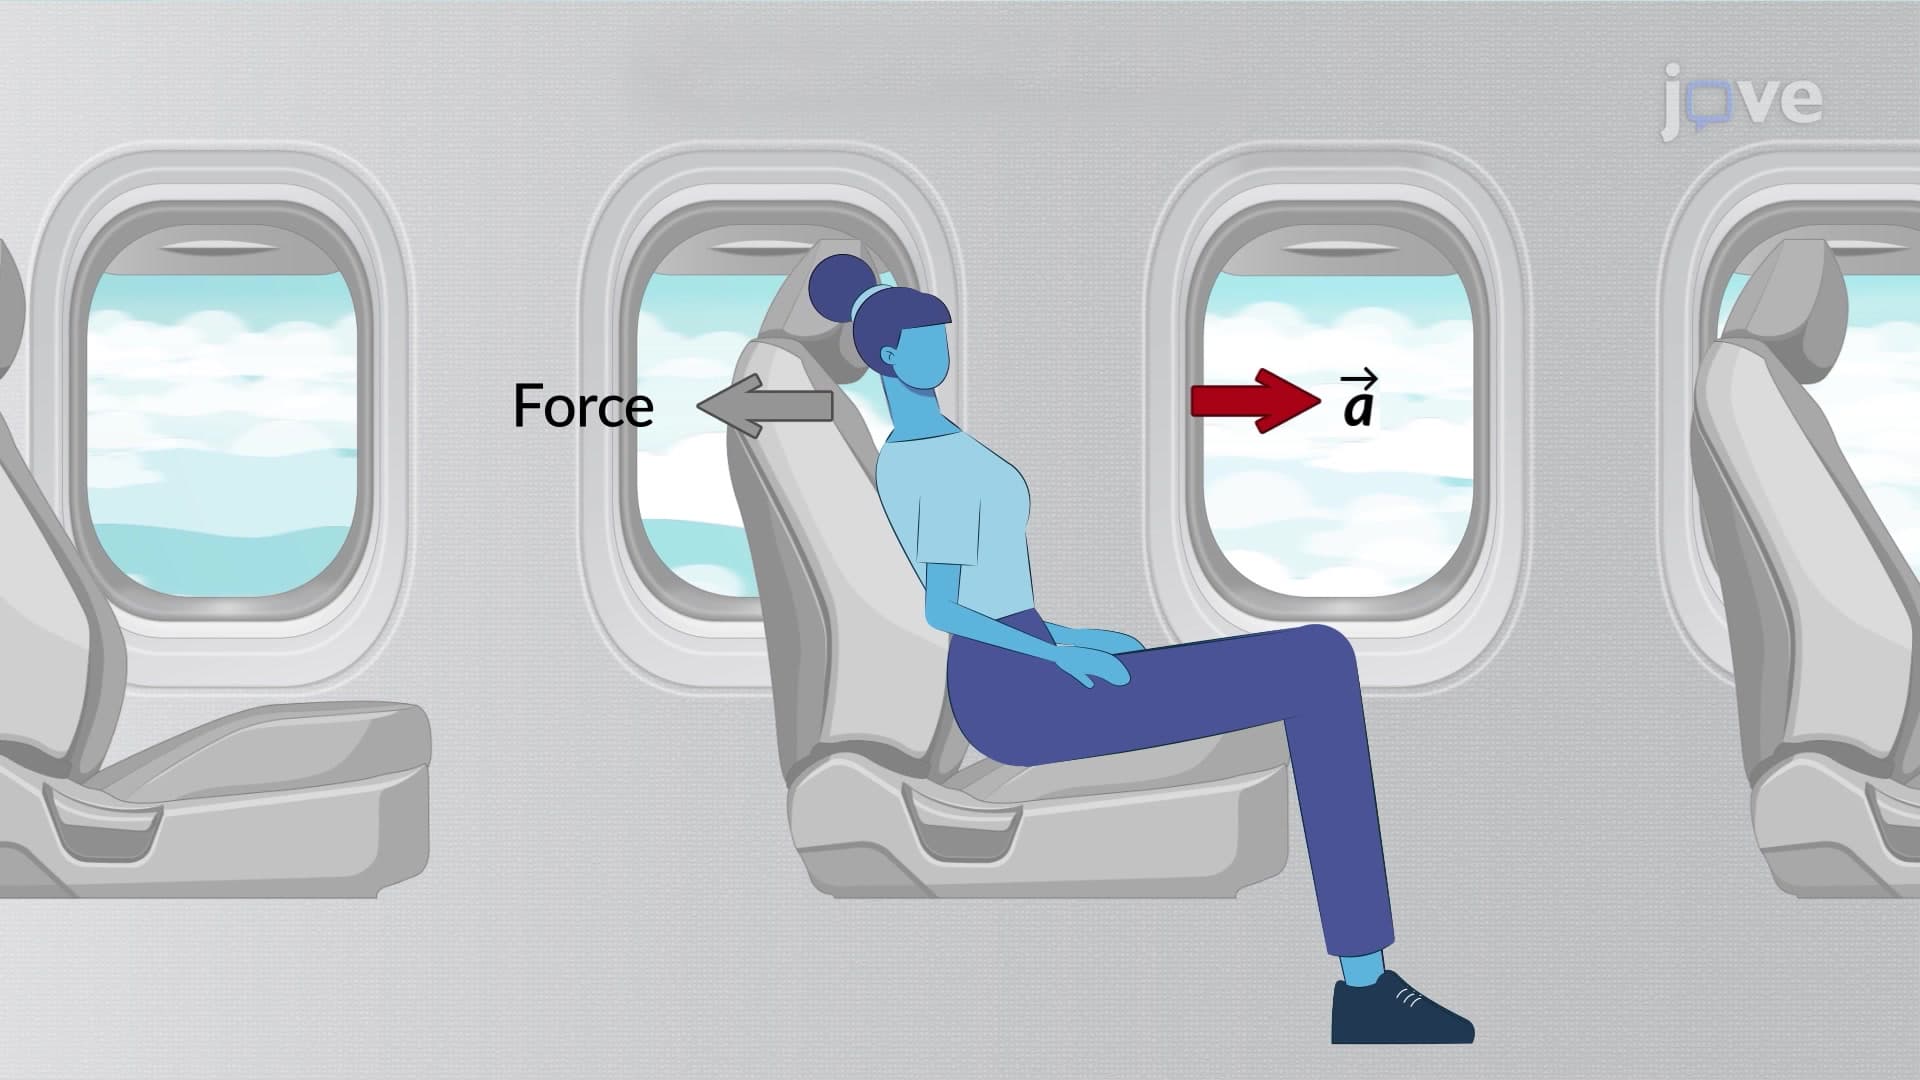
Non-inertial Frames of Reference
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...