Related Experiment Video
Updated: Jul 12, 2025


Author Spotlight: Advancing Alzheimer's Research – Exploring Early Detection and Multi-Omics Approaches
Published on: December 15, 2023
A Lightweight Unsupervised Intrusion Detection Model Based on Variational Auto-Encoder
Yi Ren1, Kanghui Feng1, Fei Hu1
1School of Computer Science, Sichuan University, Chengdu 610065, China.

Abstract:
With the gradual integration of internet technology and the industrial control field, industrial control systems (ICSs) have begun to access public networks on a large scale. Attackers use these public network interfaces to launch frequent invasions of industrial control systems, thus resulting in equipment failure and downtime, production data leakage, and other serious harm. To ensure security, ICSs urgently need a mature intrusion detection mechanism. Most of the existing research on intrusion detection in ICSs focuses on improving the accuracy of intrusion detection, thereby ignoring the problem of limited equipment resources in industrial control environments, which makes it difficult to apply excellent intrusion detection algorithms in practice. In this study, we first use the spectral residual (SR) algorithm to process the data; we then propose the improved lightweight variational autoencoder (LVA) with autoregression to reconstruct the data, and we finally perform anomaly determination based on the permutation entropy (PE) algorithm. We construct a lightweight unsupervised intrusion detection model named LVA-SP. The model as a whole adopts a lightweight design with a simpler network structure and fewer parameters, which achieves a balance between the detection accuracy and the system resource overhead. Experimental results on the ICSs dataset show that our proposed LVA-SP model achieved an F1-score of 84.81% and has advantages in terms of time and memory overhead.
Related Concept Videos
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 01:05
Difference from Background: Limit of Detection
The LOD indicates the presence or absence...
 01:11
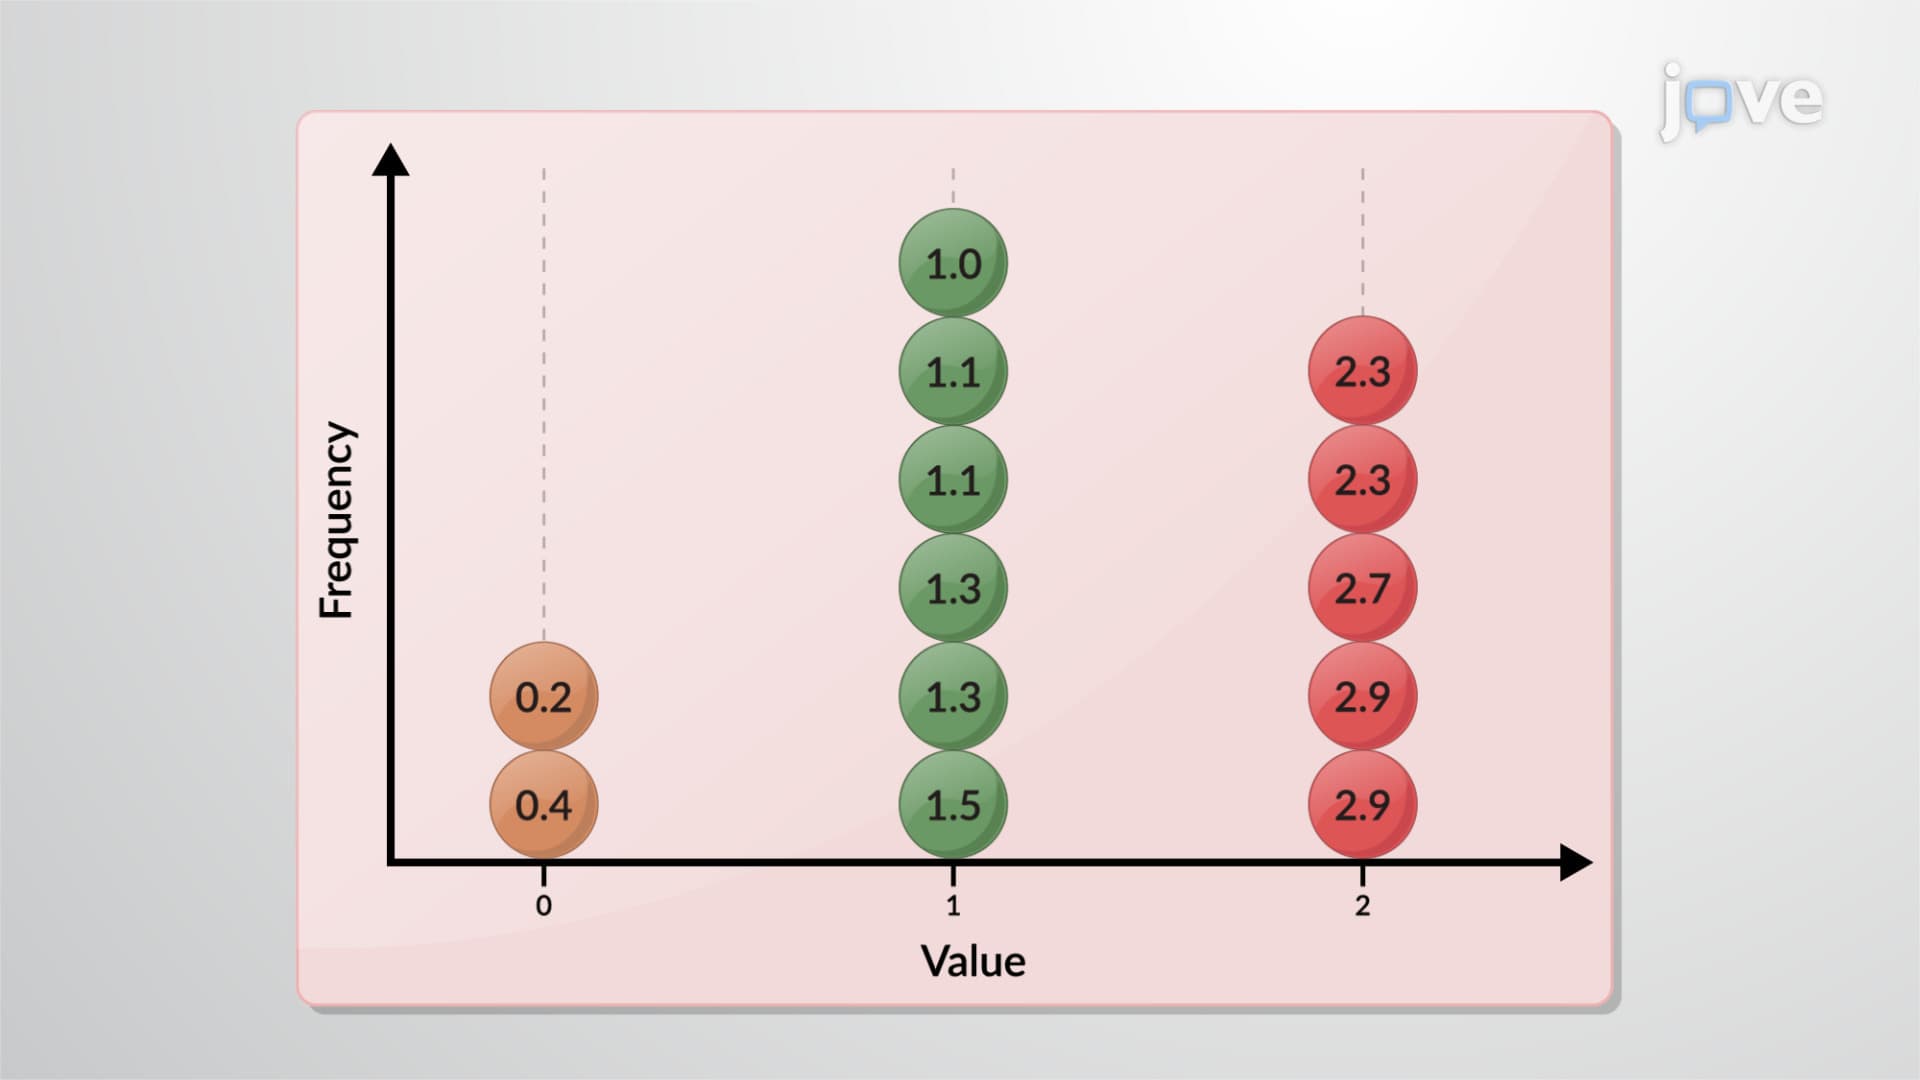
Variability: Analysis
The range is a simple measure of variability, indicating the difference between the highest and...
 01:30
Classification of Signals
A continuous-time signal holds a value at every instant in time, representing information seamlessly. In contrast, a discrete-time signal holds values only at specific moments, often denoted as x(n), where...
 01:26
Classification of Systems-I
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
 01:15
Variance
The standard deviation measures the spread in the same units as the...