Related Experiment Video
Updated: Jul 12, 2025

A Teleoperated Robotic System-Assisted Percutaneous Transiliac-Transsacral Screw Fixation Technique
Published on: January 6, 2023
Full-Perception Robotic Surgery Environment with Anti-Occlusion Global-Local Joint Positioning
Hongpeng Wang1,2,3, Tianzuo Liu1,2, Jianren Chen1,2
1College of Artificial Intelligence, Nankai University, Tianiin 300353, China.

Abstract:
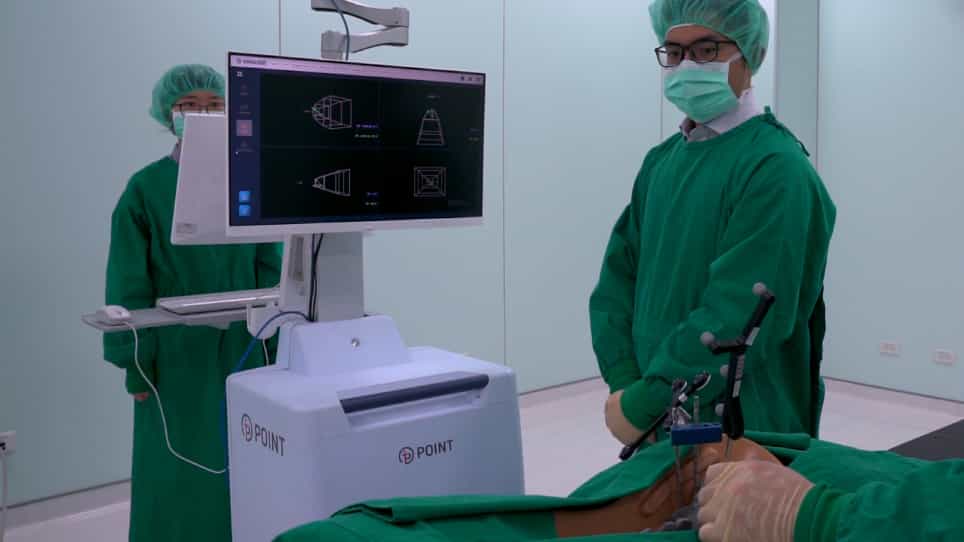
The robotic surgery environment represents a typical scenario of human-robot cooperation. In such a scenario, individuals, robots, and medical devices move relative to each other, leading to unforeseen mutual occlusion. Traditional methods use binocular OTS to focus on the local surgical site, without considering the integrity of the scene, and the work space is also restricted. To address this challenge, we propose the concept of a fully perception robotic surgery environment and build a global-local joint positioning framework. Furthermore, based on data characteristics, an improved Kalman filter method is proposed to improve positioning accuracy. Finally, drawing from the view margin model, we design a method to evaluate positioning accuracy in a dynamic occlusion environment. The experimental results demonstrate that our method yields better positioning results than classical filtering methods.

Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:28
Field Application of Global Positioning System