Related Experiment Video
Updated: Sep 21, 2026

Adaptation of a Haptic Robot in a 3T fMRI
Published on: October 4, 2011
Three-degrees-of-freedom orientation manipulation of small untethered robots with a single anisotropic soft magnet
Heng Wang1, Junhao Cui2, Kuan Tian2
1Shien-Ming Wu School of Intelligent Engineering, South China University of Technology, Guangzhou, Guangdong, China. wanghengscut@scut.edu.cn.

Abstract:
Magnetic actuation has been well exploited for untethered manipulation and locomotion of small-scale robots in complex environments such as intracorporeal lumens. Most existing magnetic actuation systems employ a permanent magnet onboard the robot. However, only 2-DoF orientation of the permanent-magnet robot can be controlled since no torque can be generated about its axis of magnetic moment, which limits the dexterity of manipulation. Here, we propose a new magnetic actuation method using a single soft magnet with an anisotropic geometry (e.g., triaxial ellipsoids) for full 3-DoF orientation manipulation. The fundamental actuation principle of anisotropic magnetization and 3-DoF torque generation are analytically modeled and experimentally validated. The hierarchical orientation stability about three principal axes is investigated, based on which we propose and validate a multi-step open-loop control strategy to alternatingly manipulate the direction of the longest axis of the soft magnet and the rotation about it for dexterous 3-DoF orientation manipulation.

Related Concept Videos
 01:30
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:15
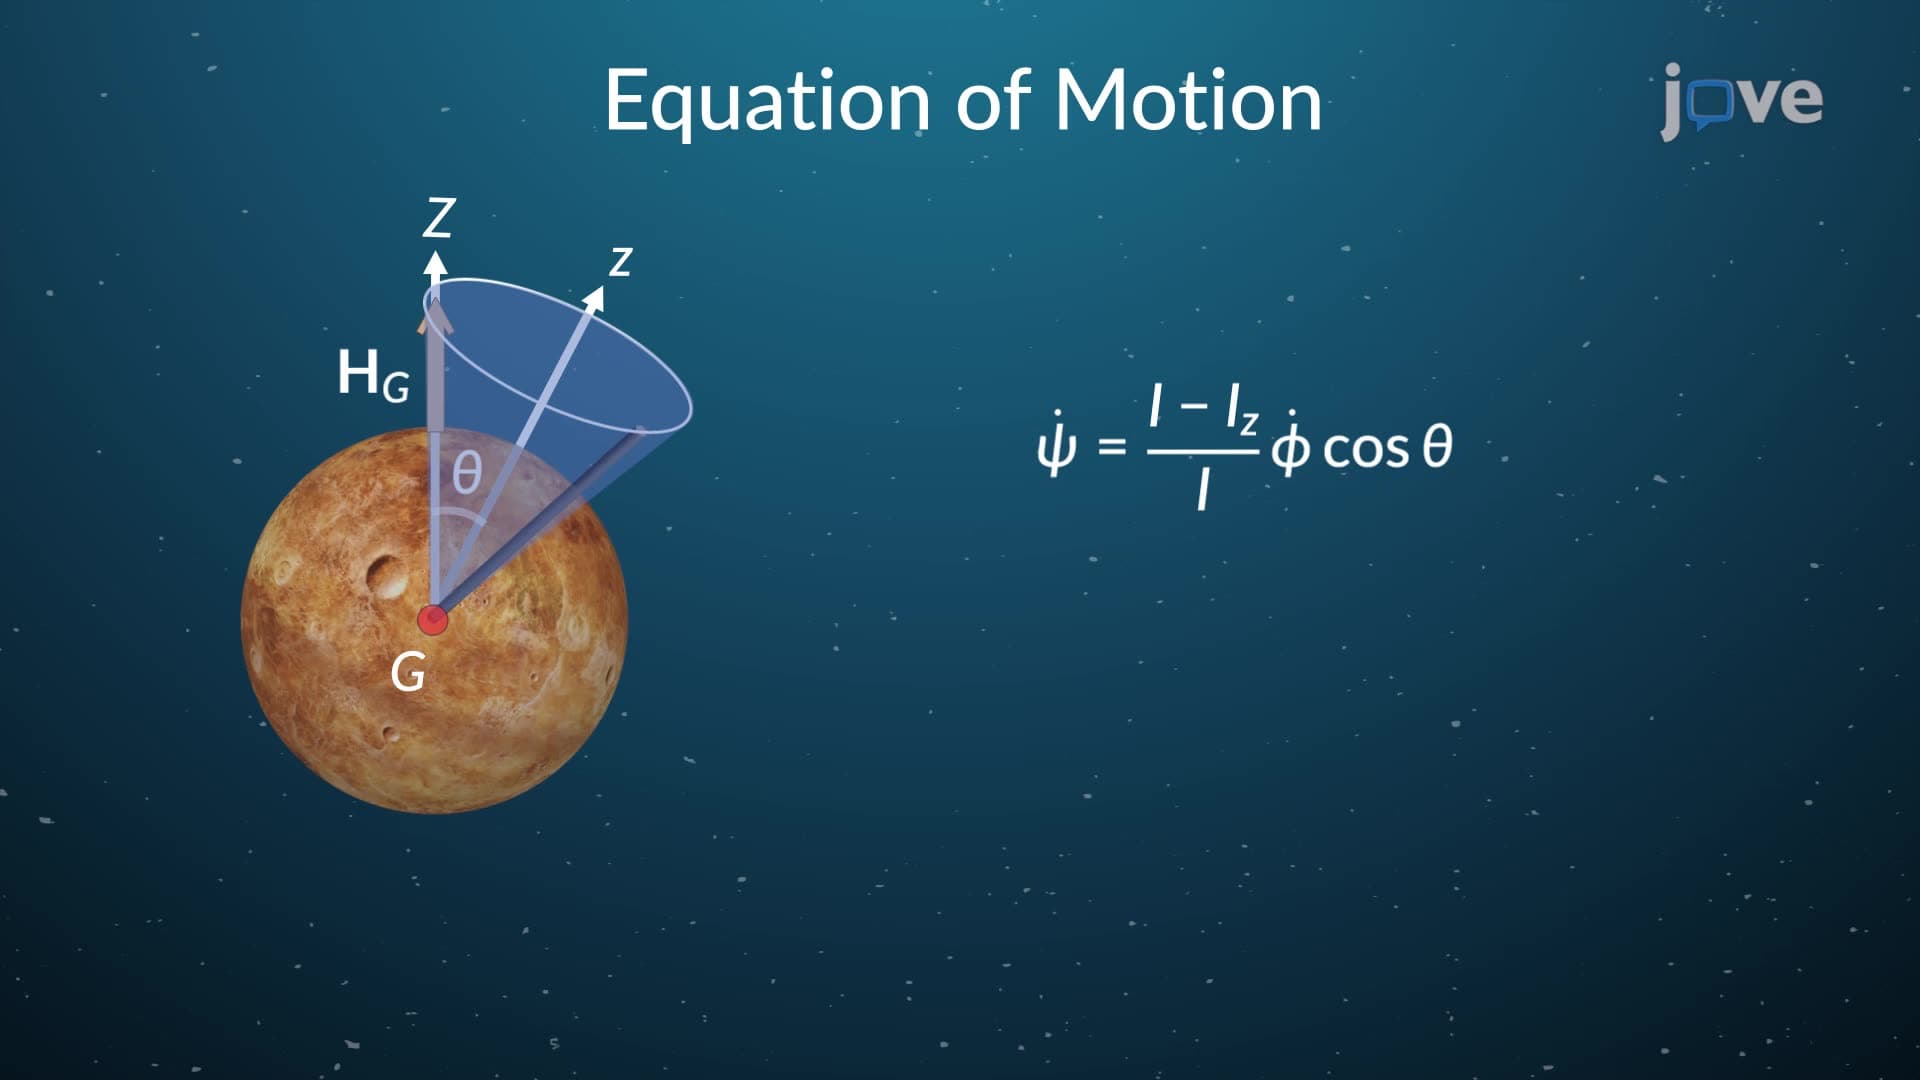
Torque Free Motion
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...