

Research on composite fault diagnosis technology of underwater vehicle actuator with positioning error constraint
1Jiangsu University of Science and Technology, Zhenjiang, Jiangsu, 212100, China.

Abstract:
When diagnosing the composite fault of the actuator, the characteristics of the motion force of the underwater vehicle are not analyzed, and there are diagnostic errors, resulting in the low accuracy of the diagnosis technology. In order to solve this problem and improve the operation safety of underwater vehicle actuators, this paper proposes a compound fault diagnosis technology for underwater vehicle actuators under positioning error constraints. Analyze the motion force of the underwater robot actuator, control the motion of the underwater robot actuator according to the analysis results, and extract real-time data parameters according to the control results. Under the constraint of positioning error, the composite fault features of the underwater robot actuator are divided, and the diagnosis model is built according to the deep fusion of the features to complete the fault diagnosis. The experimental results show that the technology can diagnose the composite fault data of the actuator, and the positioning error of the horizontal axis and the horizontal axis can be significantly improved, which can improve the diagnosis effect of the composite fault of the actuator and to the improvement of underwater robot running safety of actuators provide certain reference.
Related Concept Videos
 01:19
Root-Locus Method
This system can be represented by a block...
 01:18
Fault Types
For line-to-line faults occurring between phases B and C, the...
 01:27
Line Protection with Impedance Relays
Under normal conditions, low load currents keep the measured...
 01:26
Errors in Global Positioning System
 01:25
Directional Relays
 01:21
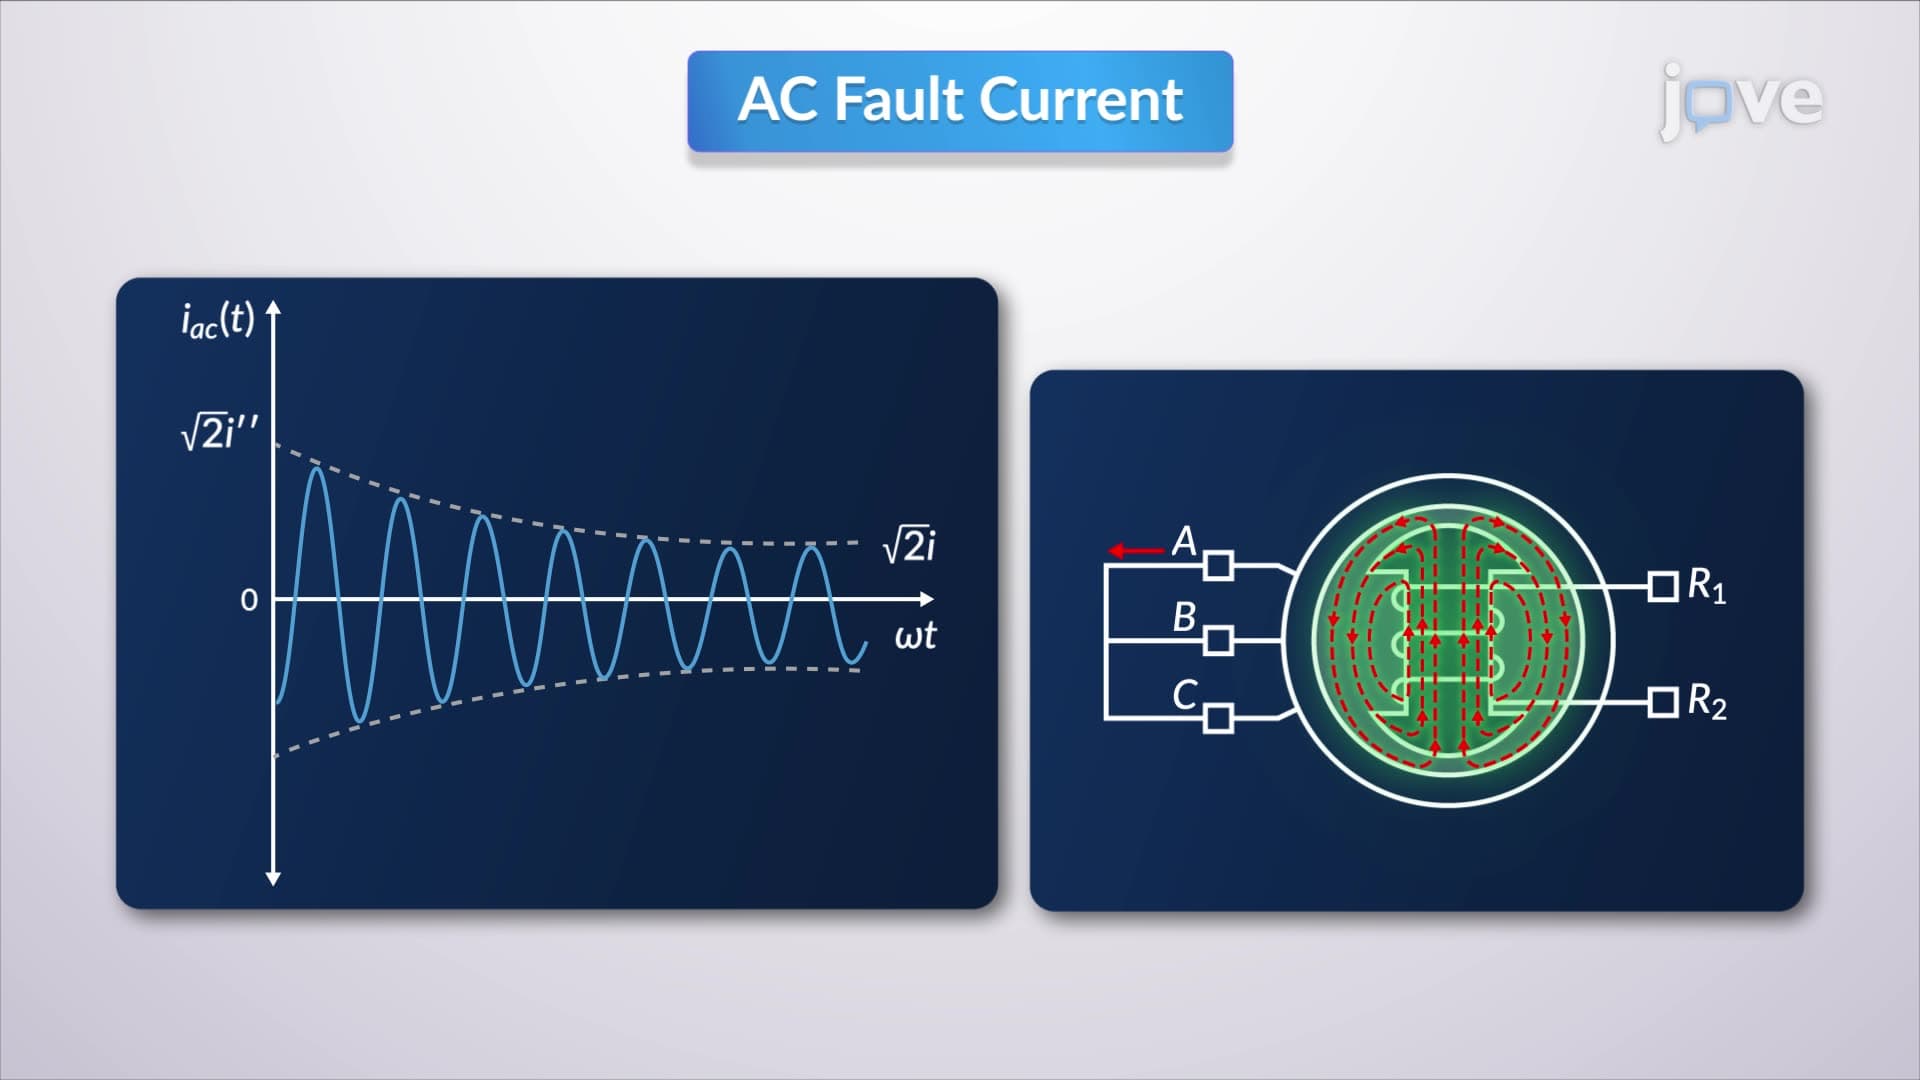
Three-Phase Short Circuit—Unloaded Synchronous Machine
This behavior occurs due to the magnetic flux produced by the short-circuit armature currents. Initially, these currents follow high-reluctance paths but eventually shift to...