Air-ground coordinated unmanned swarm systems: A multitasking framework for control design
Related Experiment Video
Updated: Jul 8, 2025
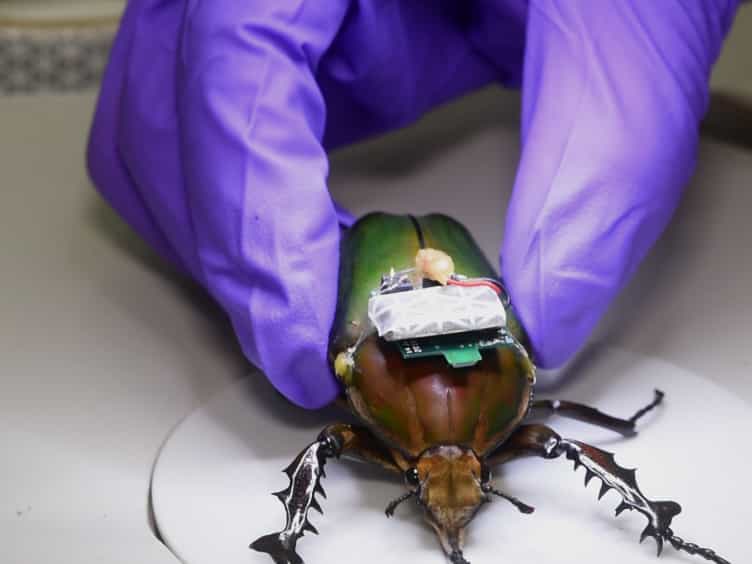
Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle Mercynorrhina torquata
Published on: September 2, 2016
Xiuye Wang1, Huiming Wang1, Qinqin Sun2
1School of Mechanical Engineering, Nanjing University of Science and Technology, 210094, Nanjing, China.

Abstract:
An air-ground heterogeneous unmanned swarm system coordination is considered. The system consists of N unmanned aerial vehicles (UAVs) and one unmanned ground vehicle (UGV). This forms a complicated mission, which consists of the following four different tasks. First, the aerial vehicles are in a compact formation, while avoiding collision with each other. Second, the aerial vehicles should stay close to the ground, while avoiding collision with the ground. Third, the aerial vehicles should stay close to the ground vehicle. Fourth, the ground vehicle should follow a desired trajectory. These tasks reflect two seemingly contradictory nature: close to (due to tracking) and away from (due to avoidance). The effective control design should address all four tasks even in the presence of uncertainty. By two creative transformations, this multitude of tasks are consolidated in a χ-measure. An adaptive robust control, which includes a robust control scheme and an online adaptation law, is then proposed to render guarantee boundedness performance of this χ-measure. As a result, the control design is able to accomplish the combined tracking-avoidance mission for the uncertain swarm system. Despite the presence of conflicting aspects between these tasks, the designed controller exhibits outstanding performance.
More Related Videos
 07:49
Automated Deployment of an Internet Protocol Telephony Service on Unmanned Aerial Vehicles Using Network Functions Virtualization
Published on: November 26, 2019
 11:53
The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Related Concept Videos
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 01:10
Control Systems
At the heart...
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:24
PI Controller: Design