Lagrange tracking-based long-term drift trajectory prediction method for Autonomous Underwater Vehicle
Related Experiment Video
Updated: Jul 7, 2025
Long-term Behavioral Tracking of Freely Swimming Weakly Electric Fish
Published on: March 6, 2014
Shuwen Zheng1, Mingjun Zhang1, Jing Zhang2
1College of Mechanical and Electrical Engineering, Harbin Engineering University, Harbin 150001, China.

Abstract:
Autonomous Underwater Vehicle (AUV) works autonomously in complex marine environments. After a severe accident, an AUV will lose its power and rely on its small buoyancy to ascend at a slow speed. If the reserved buoyancy is insufficient, when reaching the thermocline, the buoyancy will rapidly decrease to zero. Consequently, the AUV will experience prolonged lateral drift within the thermocline. This study focuses on developing a prediction method for the drift trajectory of an AUV after a long-term power loss accident. The aim is to forecast the potential resurfacing location, providing technical support for surface search and salvage operations of the disabled AUV. To the best of our knowledge, currently, there is no mature and effective method for predicting long-term AUV underwater drift trajectories. In response to this issue, based on real AUV catastrophes, this paper studies the prediction of long-term AUV underwater drift trajectories in the cases of power loss. We propose a three-dimensional trajectory prediction method based on the Lagrange tracking approach. This method takes the AUV's longitudinal velocity, the time taken to reach different depths, and ocean current data at various depths into account. The reason for the AUV's failure to ascend to sea surface lies that the remaining buoyancy is too small to overcome the thermocline. As a result, AUV drifts long time within the thermocline. To address this issue, a method for estimating thermocline currents is proposed, which can be used to predict the lateral drift trajectory of the AUV within the thermocline. Simulation is conducted to compare the results obtained by the proposed method and that in a real accident. The results demonstrate that the proposed approach exhibits small directional and positional errors. This validates the effectiveness of the proposed method.
Related Concept Videos
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:19
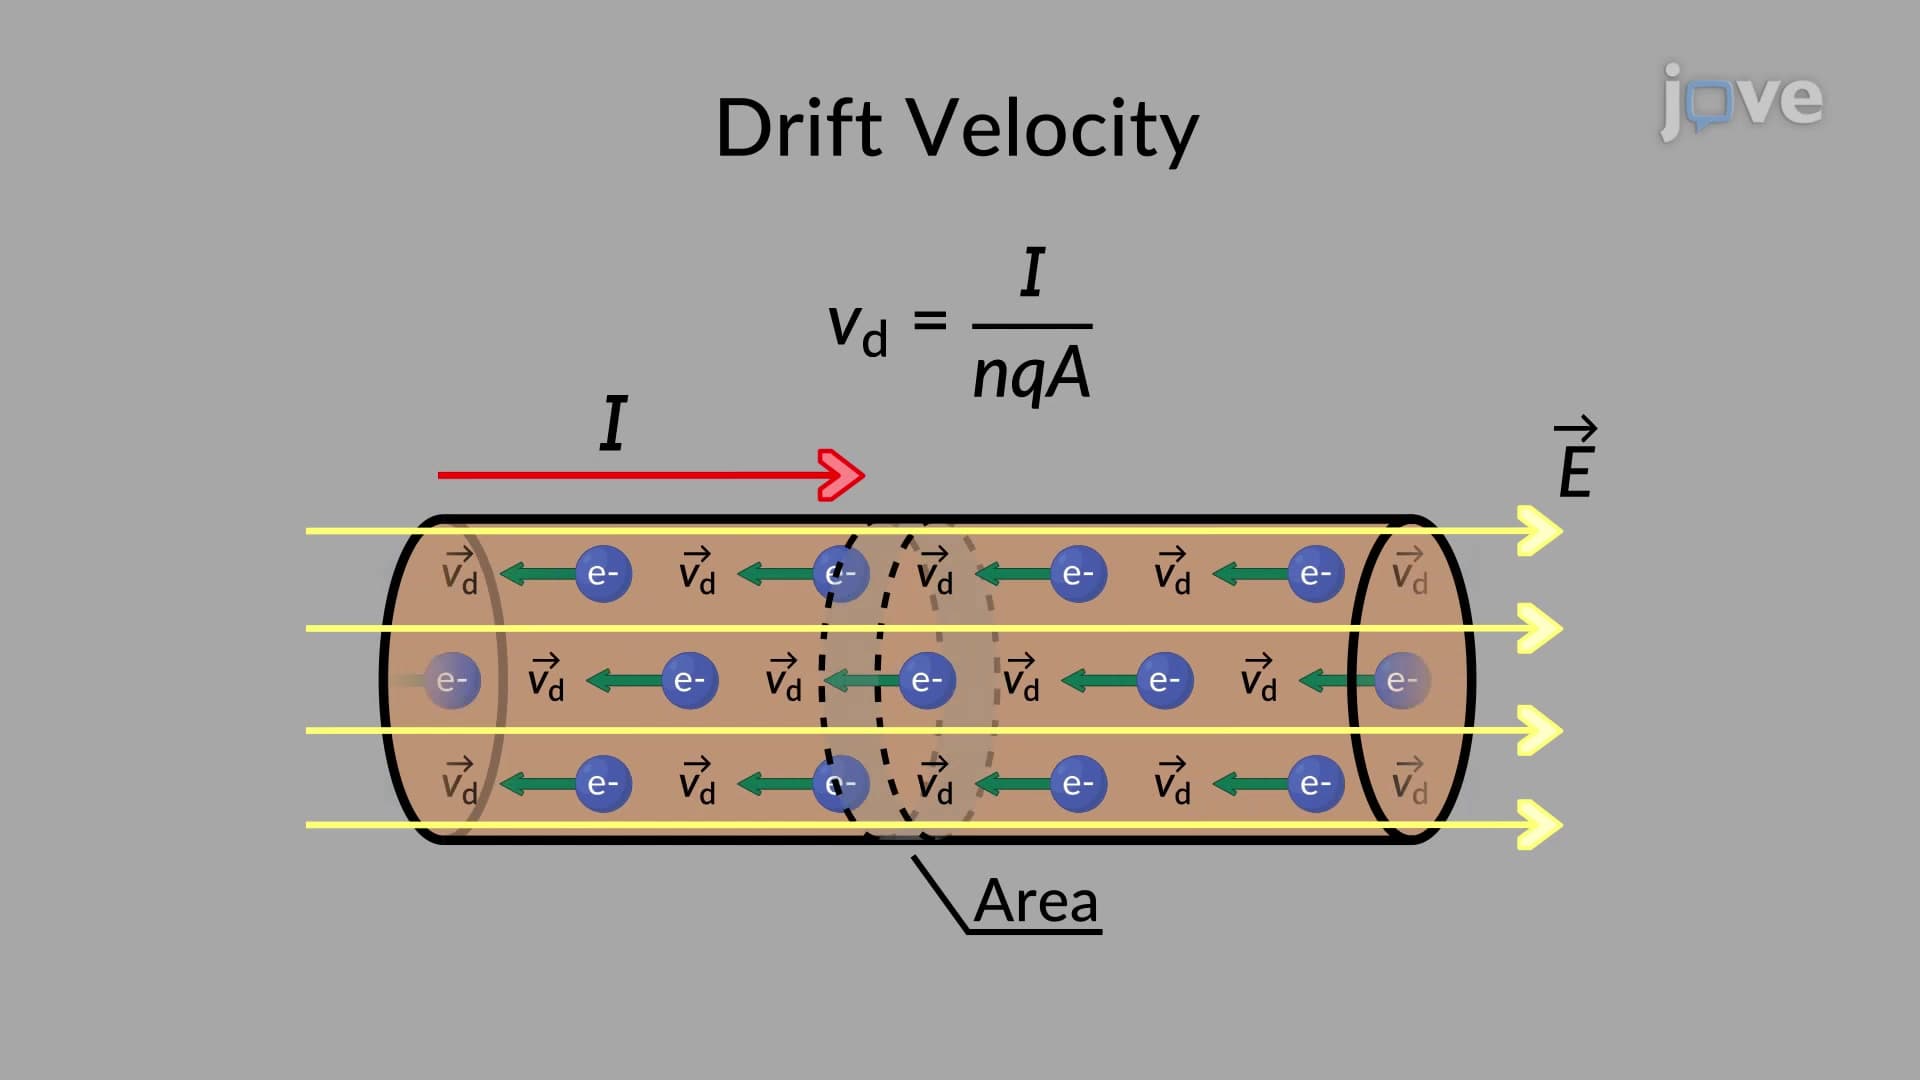
Drift Velocity
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...