Related Experiment Video
Updated: Jul 24, 2026
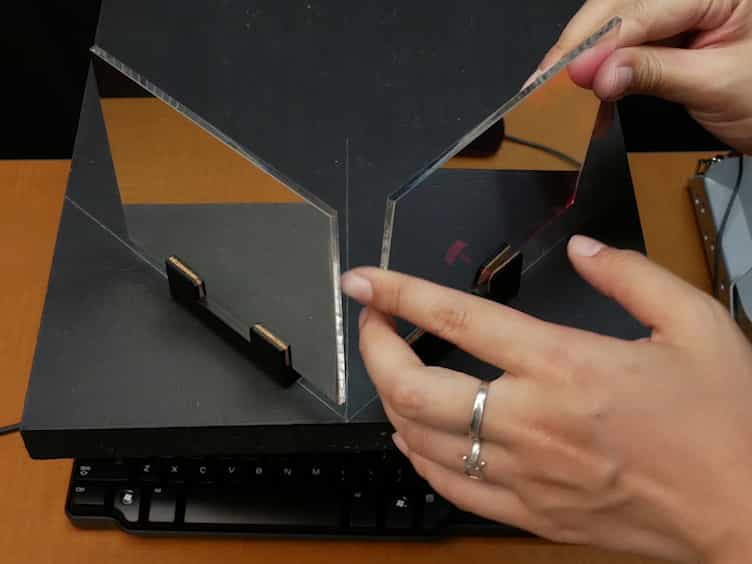
How to Build a Dichoptic Presentation System That Includes an Eye Tracker
Published on: September 6, 2017
Accurate Monocular SLAM Initialization via Structural Line Tracking
Tianlun Gu1,2, Jianwei Zhang1,2, Yanli Liu1,2
1College of Computer Science, Sichuan University, Chengdu 610065, China.

Abstract:
In this paper, we present a novel monocular simultaneous localization and mapping (SLAM) initialization algorithm that relies on structural features by tracking structural lines. This approach addresses the limitations of the traditional method, which can fail to account for a lack of features or their uneven distribution. Our proposed method utilizes a sliding window approach to guarantee the quality and stability of the initial pose estimation. We incorporate multiple geometric constraints, orthogonal dominant directions, and coplanar structural lines to construct an efficient pose optimization strategy. Experimental evaluations conducted on both the collected chessboard datasets and real scene datasets show that our approach provides superior results in terms of accuracy and real-time performance compared to the well-tuned baseline methods. Notably, our algorithm achieves these improvements while being computationally lightweight, without the need for matrix decomposition.