Related Experiment Video
Updated: Jul 6, 2025
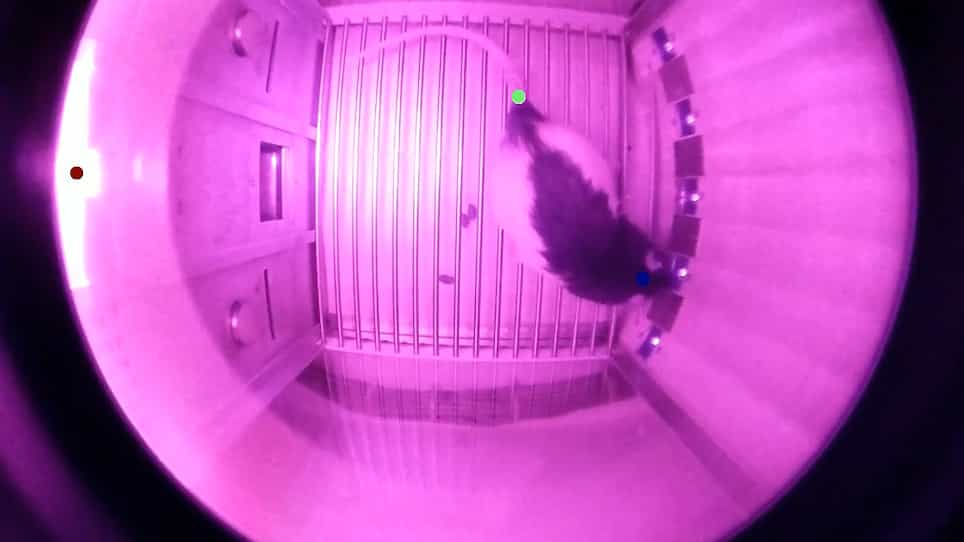

Tracking Rats in Operant Conditioning Chambers Using a Versatile Homemade Video Camera and DeepLabCut
Published on: June 15, 2020
A comparative study of a traditional localization algorithm and a deep learning model for radioactive particle
Roos Sophia de Freitas Dam1, Renato Raoni Werneck Affonso2, William Luna Salgado2
1Programa de Engenharia Nuclear, Universidade Federal Do Rio de Janeiro, Avenida Horácio de Macedo 2030, Bloco G - Sala 206, Zip Code 21941-914, Cidade Universitária, RJ, Brazil; Instituto de Engenharia Nuclear, Rua Hélio de Almeida 75, Zip Code 21941-906, Cidade Universitária, RJ, Brazil.

Abstract:
Radioactive particle tracking is a nuclear technique that tracks a sealed radioactive particle inside a volume through a mathematical location algorithm, which is widely applied in many fields such as chemical and civil engineering in hydrodynamics flows. It is possible to reconstruct the trajectory of the radioactive particle using a traditional mathematical algorithm or artificial intelligence methods. In this paper, the traditional algorithm is based on solving a minimization problem between the simulated events and a calibration dataset, and it was written using C++ language. The artificial intelligence method is represented by a deep neural network, in which hyperparameters were defined using a Python optimization library called Optuna. This paper aims to compare the potentiality of both methods to evaluate the accuracy of the radioactive particle tracking technique. This study proposes a simplified model of a concrete mixer, six NaI(Tl) detectors, and a137Cs sealed radioactive particle. The simulated measurement geometry and the dataset (3615 patterns) were developed using the MCNPX code, which is a mathematical code based on the Monte Carlo Method. The results show a mean absolute percentage error (MAPE) of 20.81%, 10.33%, and 16.84% for x, y and z coordinates, respectively, for the traditional algorithm. For the deep neural network, MAPE is 6.87%, 2.70%, and 22.79% respectively for x, y and z coordinates. In addition, an investigation is carried out to analyze whether the size of the calibration dataset influences the performance of both methods.