Related Experiment Video
Updated: Jul 5, 2025
Electroantennography-based Bio-hybrid Odor-detecting Drone using Silkmoth Antennae for Odor Source Localization
Published on: August 27, 2021
An Angular Acceleration Based Looming Detector for Moving UAVs
Jiannan Zhao1, Quansheng Xie1, Feng Shuang1
1Guangxi Key Laboratory of Intelligent Control and Maintenance of Power Equipment, School of Electrical Engineering, Guangxi University, Nanning 530004, China.

Abstract:
Visual perception equips unmanned aerial vehicles (UAVs) with increasingly comprehensive and instant environmental perception, rendering it a crucial technology in intelligent UAV obstacle avoidance. However, the rapid movements of UAVs cause significant changes in the field of view, affecting the algorithms' ability to extract the visual features of collisions accurately. As a result, algorithms suffer from a high rate of false alarms and a delay in warning time. During the study of visual field angle curves of different orders, it was found that the peak times of the curves of higher-order information on the angular size of looming objects are linearly related to the time to collision (TTC) and occur before collisions. This discovery implies that encoding higher-order information on the angular size could resolve the issue of response lag. Furthermore, the fact that the image of a looming object adjusts to meet several looming visual cues compared to the background interference implies that integrating various field-of-view characteristics will likely enhance the model's resistance to motion interference. Therefore, this paper presents a concise A-LGMD model for detecting looming objects. The model is based on image angular acceleration and addresses problems related to imprecise feature extraction and insufficient time series modeling to enhance the model's ability to rapidly and precisely detect looming objects during the rapid self-motion of UAVs. The model draws inspiration from the lobula giant movement detector (LGMD), which shows high sensitivity to acceleration information. In the proposed model, higher-order information on the angular size is abstracted by the network and fused with multiple visual field angle characteristics to promote the selective response to looming objects. Experiments carried out on synthetic and real-world datasets reveal that the model can efficiently detect the angular acceleration of an image, filter out insignificant background motion, and provide early warnings. These findings indicate that the model could have significant potential in embedded collision detection systems of micro or small UAVs.
Related Concept Videos
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:10
Relative Motion Analysis - Acceleration
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:16
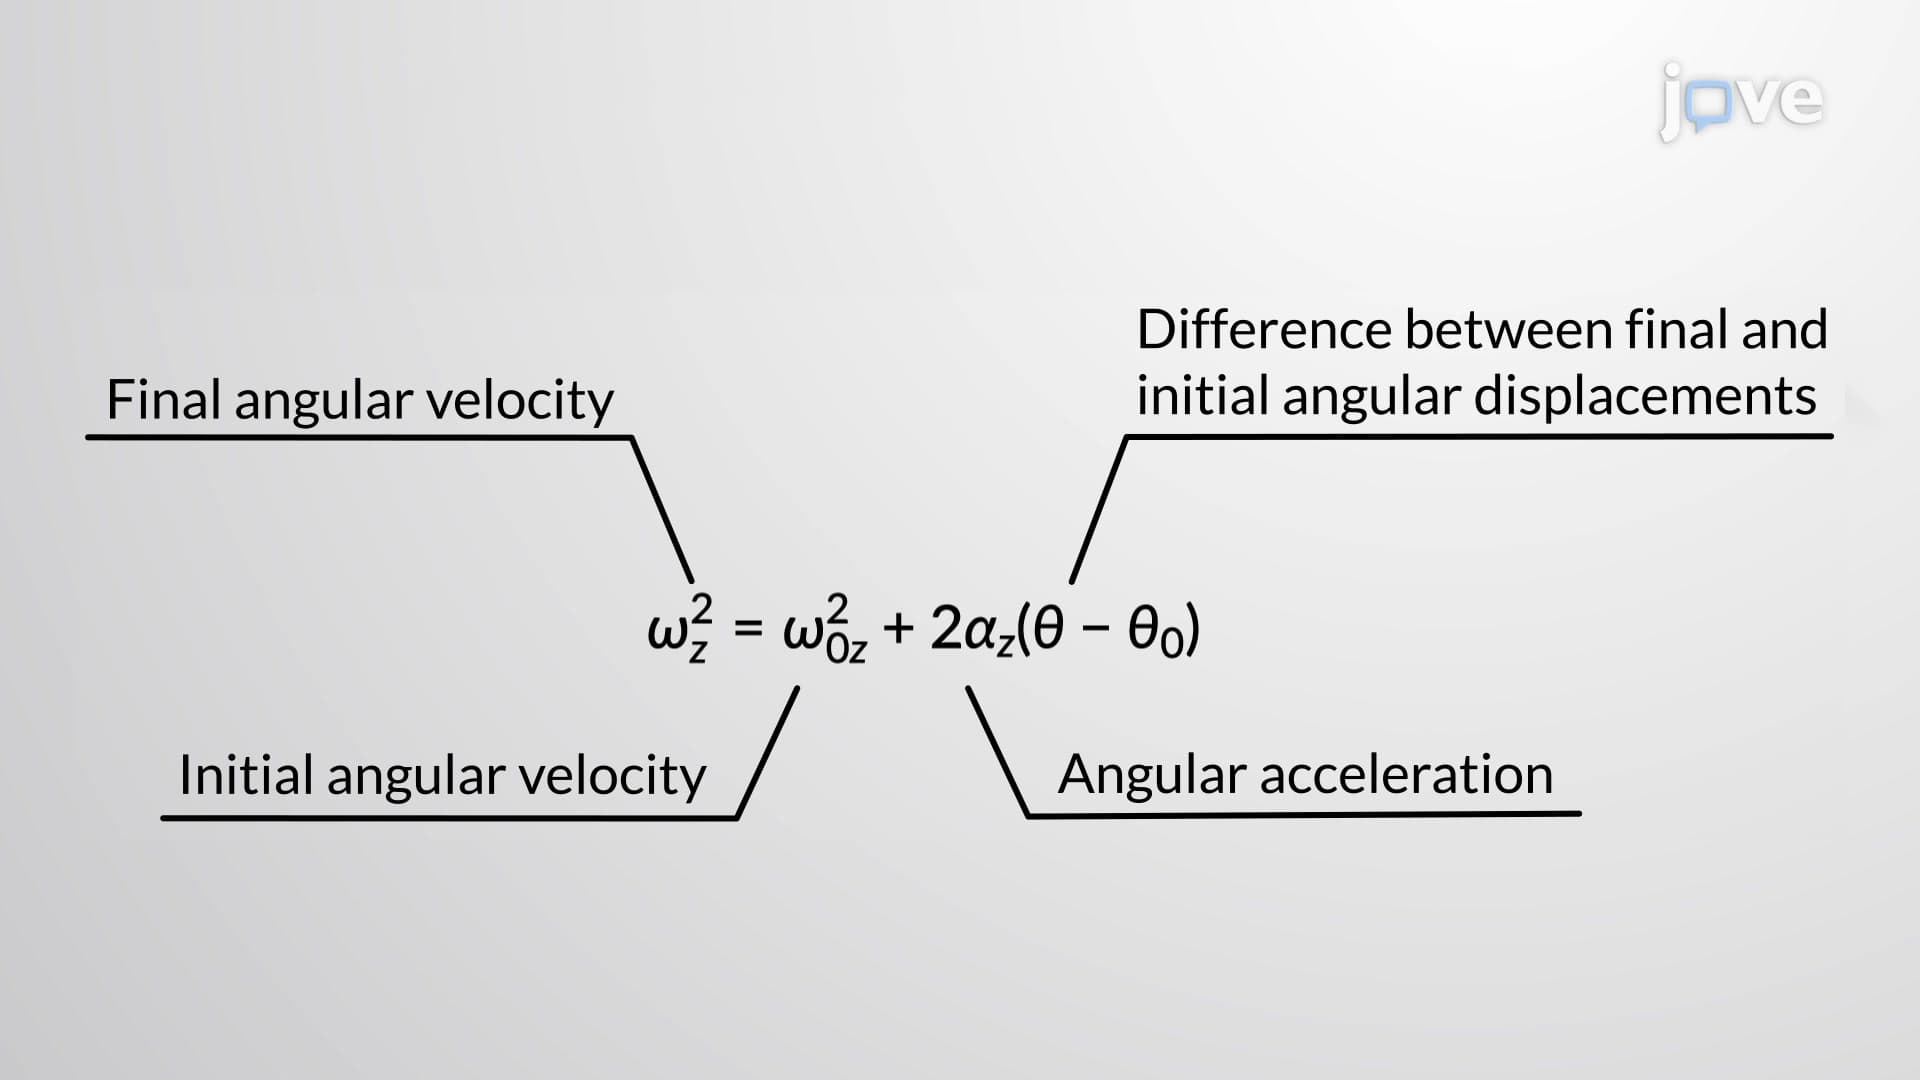
Rotation with Constant Angular Acceleration - II
The first...
 01:37
Rotation with Constant Angular Acceleration - I
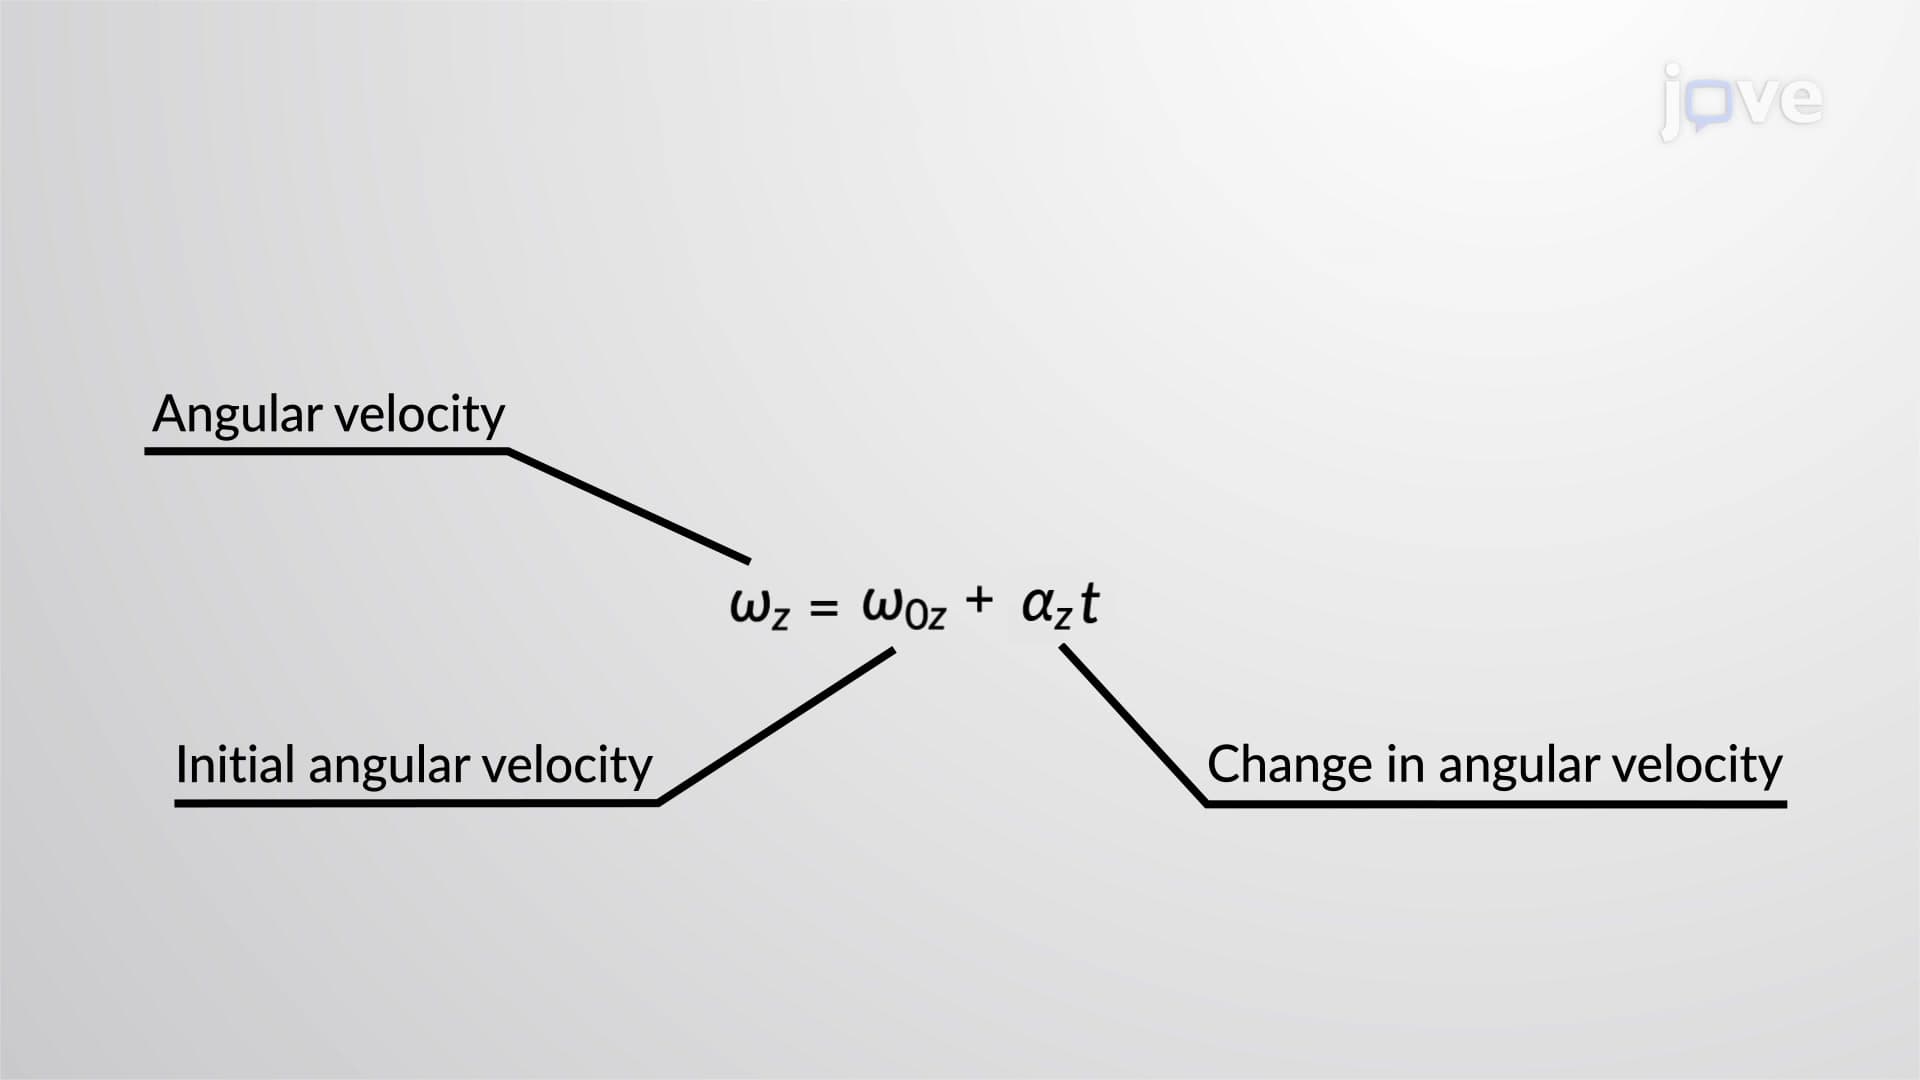
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...