Related Experiment Video
Updated: Jul 5, 2025

Comparative Analysis of Lower Limb Kinematics between the Initial and Terminal Phase of 5km Treadmill Running
Published on: July 17, 2020
Learning Quadrupedal High-Speed Running on Uneven Terrain
1Department of Automation, Tsinghua University, Beijing 100084, China.

Abstract:
Reinforcement learning (RL)-based controllers have been applied to the high-speed movement of quadruped robots on uneven terrains. The external disturbances increase as the robot moves faster on such terrains, affecting the stability of the robot. Many existing RL-based methods adopt higher control frequencies to respond quickly to the disturbance, which requires a significant computational cost. We propose a control framework that consists of an RL-based control policy updating at a low frequency and a model-based joint controller updating at a high frequency. Unlike previous methods, our policy outputs the control law for each joint, executed by the corresponding high-frequency joint controller to reduce the impact of external disturbances on the robot. We evaluated our method on various simulated terrains with height differences of up to 6 cm. We achieved a running motion of 1.8 m/s in the simulation using the Unitree A1 quadruped. The RL-based control policy updates at 50 Hz with a latency of 20 ms, while the model-based joint controller runs at 1000 Hz. The experimental results show that the proposed framework can overcome the latency caused by low-frequency updates, making it applicable for real-robot deployment.
More Related Videos
 08:19
Asymmetric Walkway: A Novel Behavioral Assay for Studying Asymmetric Locomotion
Published on: January 15, 2016
 06:35
Using Gold-standard Gait Analysis Methods to Assess Experience Effects on Lower-limb Mechanics During Moderate High-heeled Jogging and Running
Published on: September 14, 2017
Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:21
Rolling Resistance
For instance, imagine a hard cylinder rolling on a comparatively soft surface. The cylinder's weight compresses the surface beneath it. As the cylinder moves, the material in front of it slows down...
 01:16
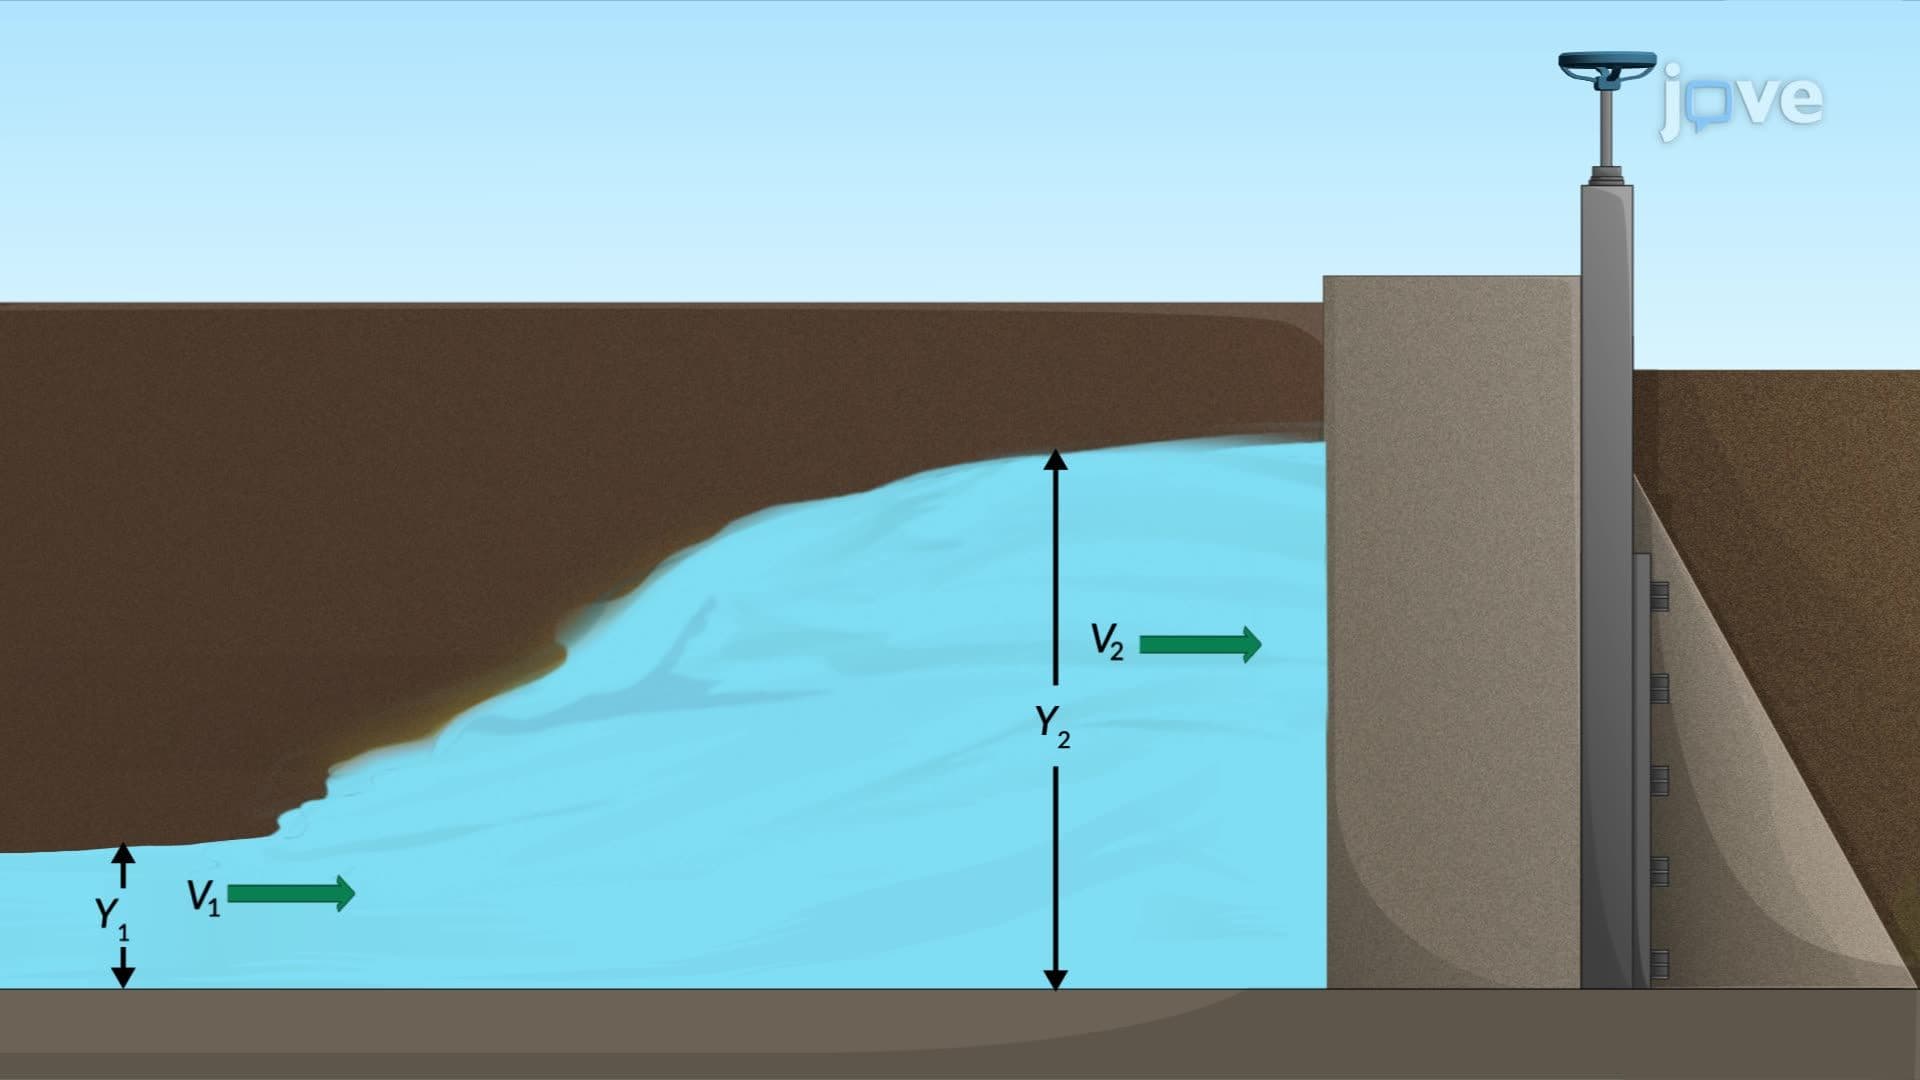
Hydraulic Jump: Problem Solving