Related Experiment Video
Updated: Jul 5, 2025


Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
The (Un)ideal Physicist: How Humans Rely on Object Interaction for Friction Estimates
Harun Karimpur1,2, Christian Wolf3, Katja Fiehler1,2
1Experimental Psychology, Justus Liebig University Giessen.

Abstract:
To estimate object properties such as mass or friction, our brain relies on visual information to efficiently compute approximations. The role of sensorimotor feedback, however, is not well understood. Here we tested healthy adults (N = 79) in an inclined-plane problem, that is, how much a plane can be tilted before an object starts to slide, and contrasted the interaction group with observation groups who accessed involved forces by watching objects being manipulated. We created objects of different masses and levels of friction and asked participants to estimate the critical tilt angle after pushing an object, lifting it, or both. Estimates correlated with applied forces and were biased toward object mass, with higher estimates for heavier objects. Our findings highlight that inferences about physical object properties are tightly linked to the human sensorimotor system and that humans integrate sensorimotor information even at the risk of nonveridical perceptual estimates.
More Related Videos

Related Concept Videos
 01:27
Types of Friction Problems
The first type of dry friction problem involves situations where there is no apparent impending motion....
 01:07
Frictional Force
 01:05
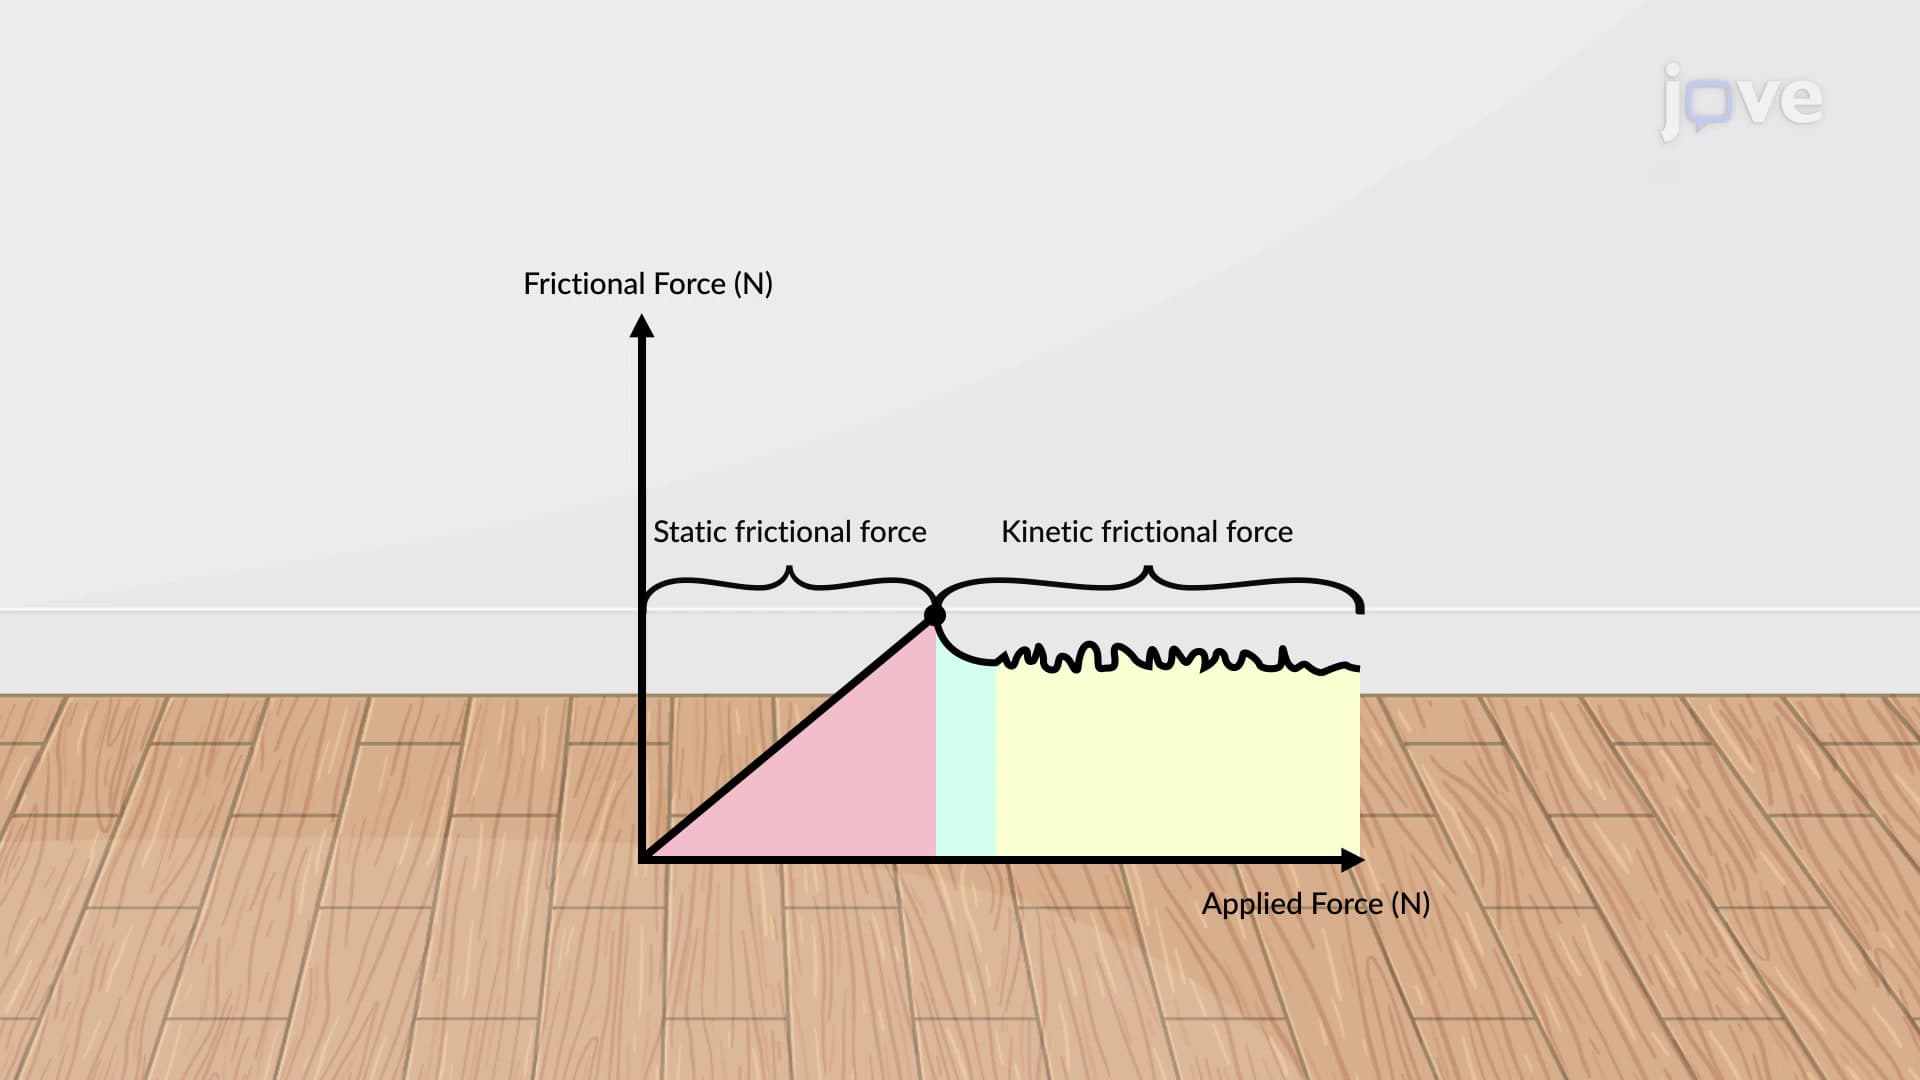
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:30
Dry Friction
To illustrate this concept, imagine a wooden crate resting on a rough, non-uniform horizontal surface. When an external force is applied to...
 01:30
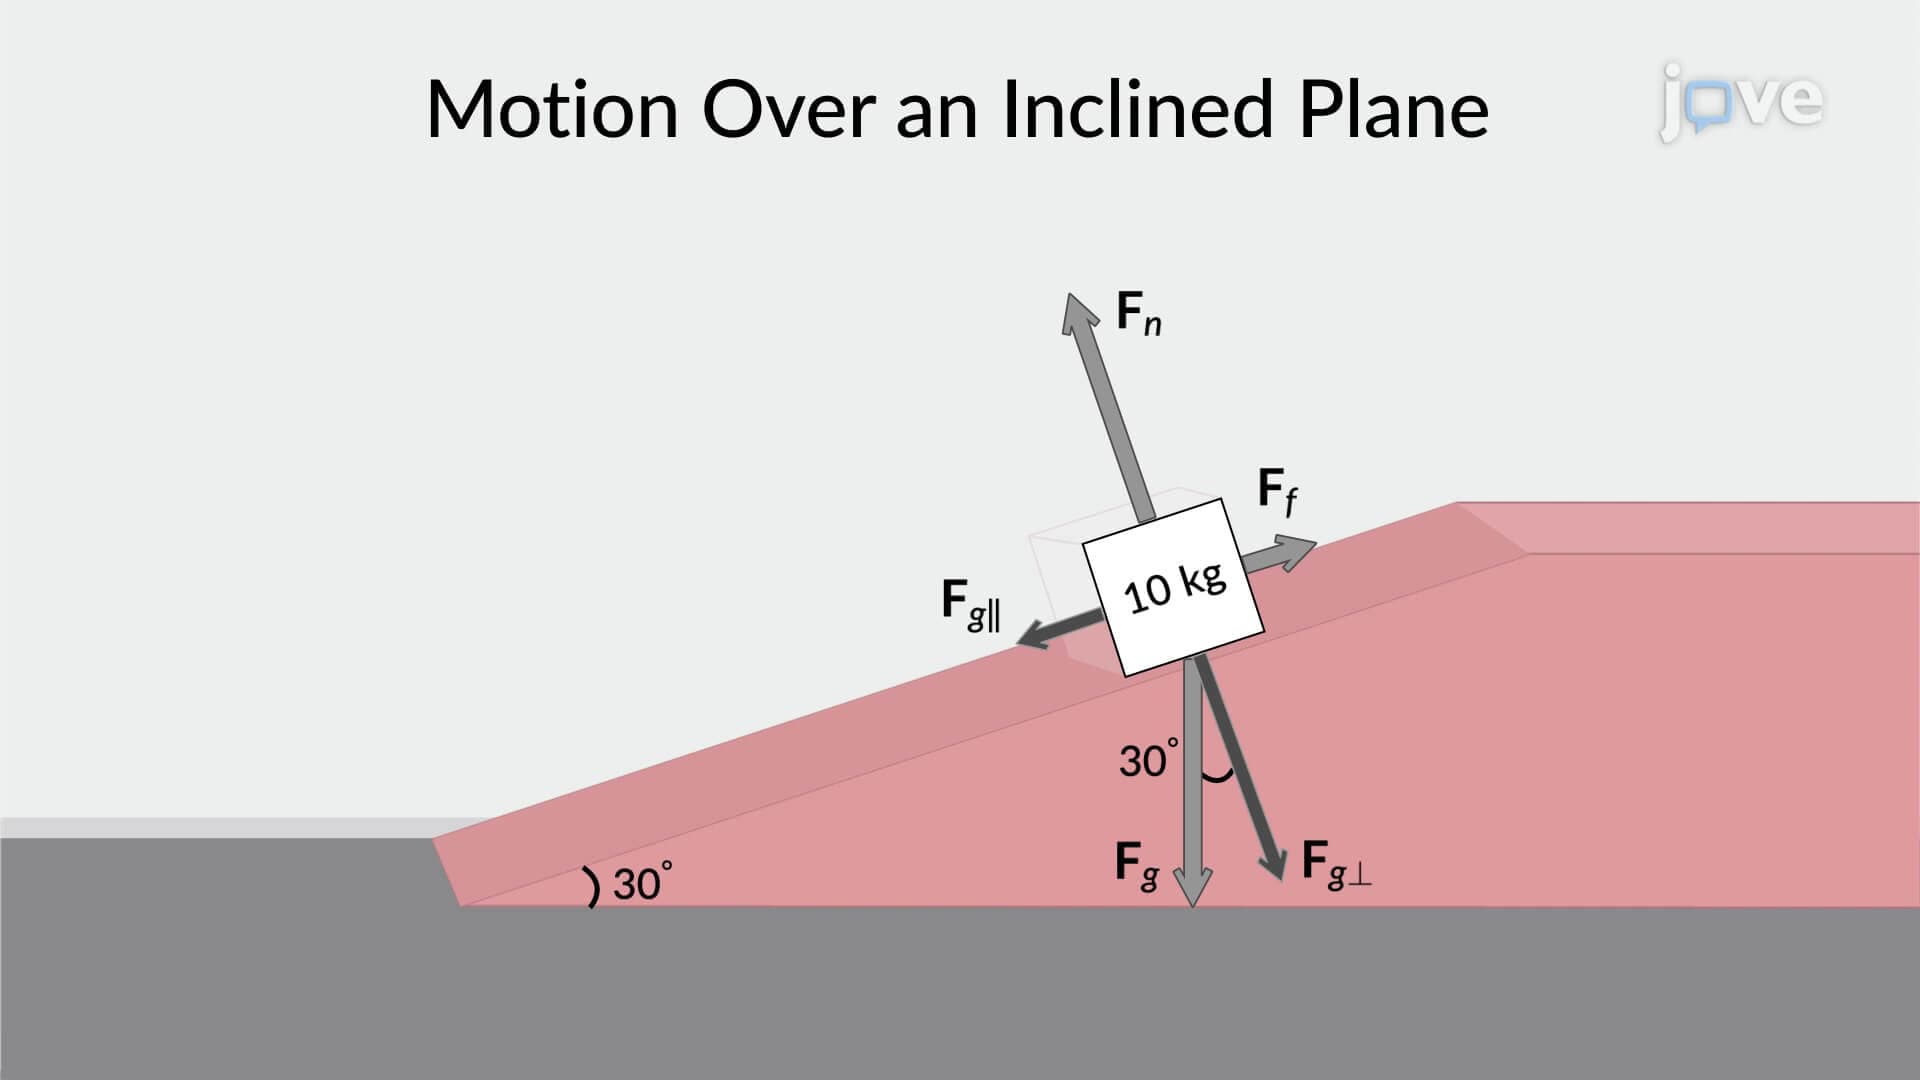
Free-body Diagrams: Problem Solving
For example, consider a block with a mass of 10 kg released on an inclined plane at an angle of 30° to the horizontal, where...
 01:26
Kinetic Friction