RIS-assisted near-field localization using practical phase shift model
Related Experiment Video
Updated: Jul 2, 2025
Implementation of a Reference Interferometer for Nanodetection
Published on: April 26, 2014
Saber Hassouna1, Muhammad Ali Jamshed2, Masood Ur-Rehman2
1James Watt School of Engineering, University of Glasgow, Glasgow, UK. s.hassouna.1@research.gla.ac.uk.

Abstract:
Our research focuses on examining the problem of localizing user equipment (UE) in the uplink scenario using reconfigurable intelligent surfaces (RIS) based lens. We carry out a thorough analysis of the Fisher information matrix (FIM) and assess the influence of various RIS-based lens configurations using an actual RIS phase-dependent amplitude variations model. Furthermore, to reduce the complexity of the maximum likelihood (ML) estimator, a simple localization algorithm-based angular expansion is presented. Simulation results show superior localization performance when prior location information is available for directional and positional channel configurations. The position error bound (PEB) and the root mean square error (RMSE) are studied to evaluate the localization accuracy of the user utilizing the realistic RIS phase-dependent amplitude model in the near-field region. Furthermore, the achievable data rate is obtained in the same region using the realistic RIS phase-dependent amplitude model. It is noticed that adopting the actual RIS phase-dependent amplitude model under the near-field channel increases the localization error and degrades the data rate performance for amplitude value less than one so, the unity assumption of the RIS phase shift model used widely in the literature is inaccurate.
More Related Videos
Related Concept Videos
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:10
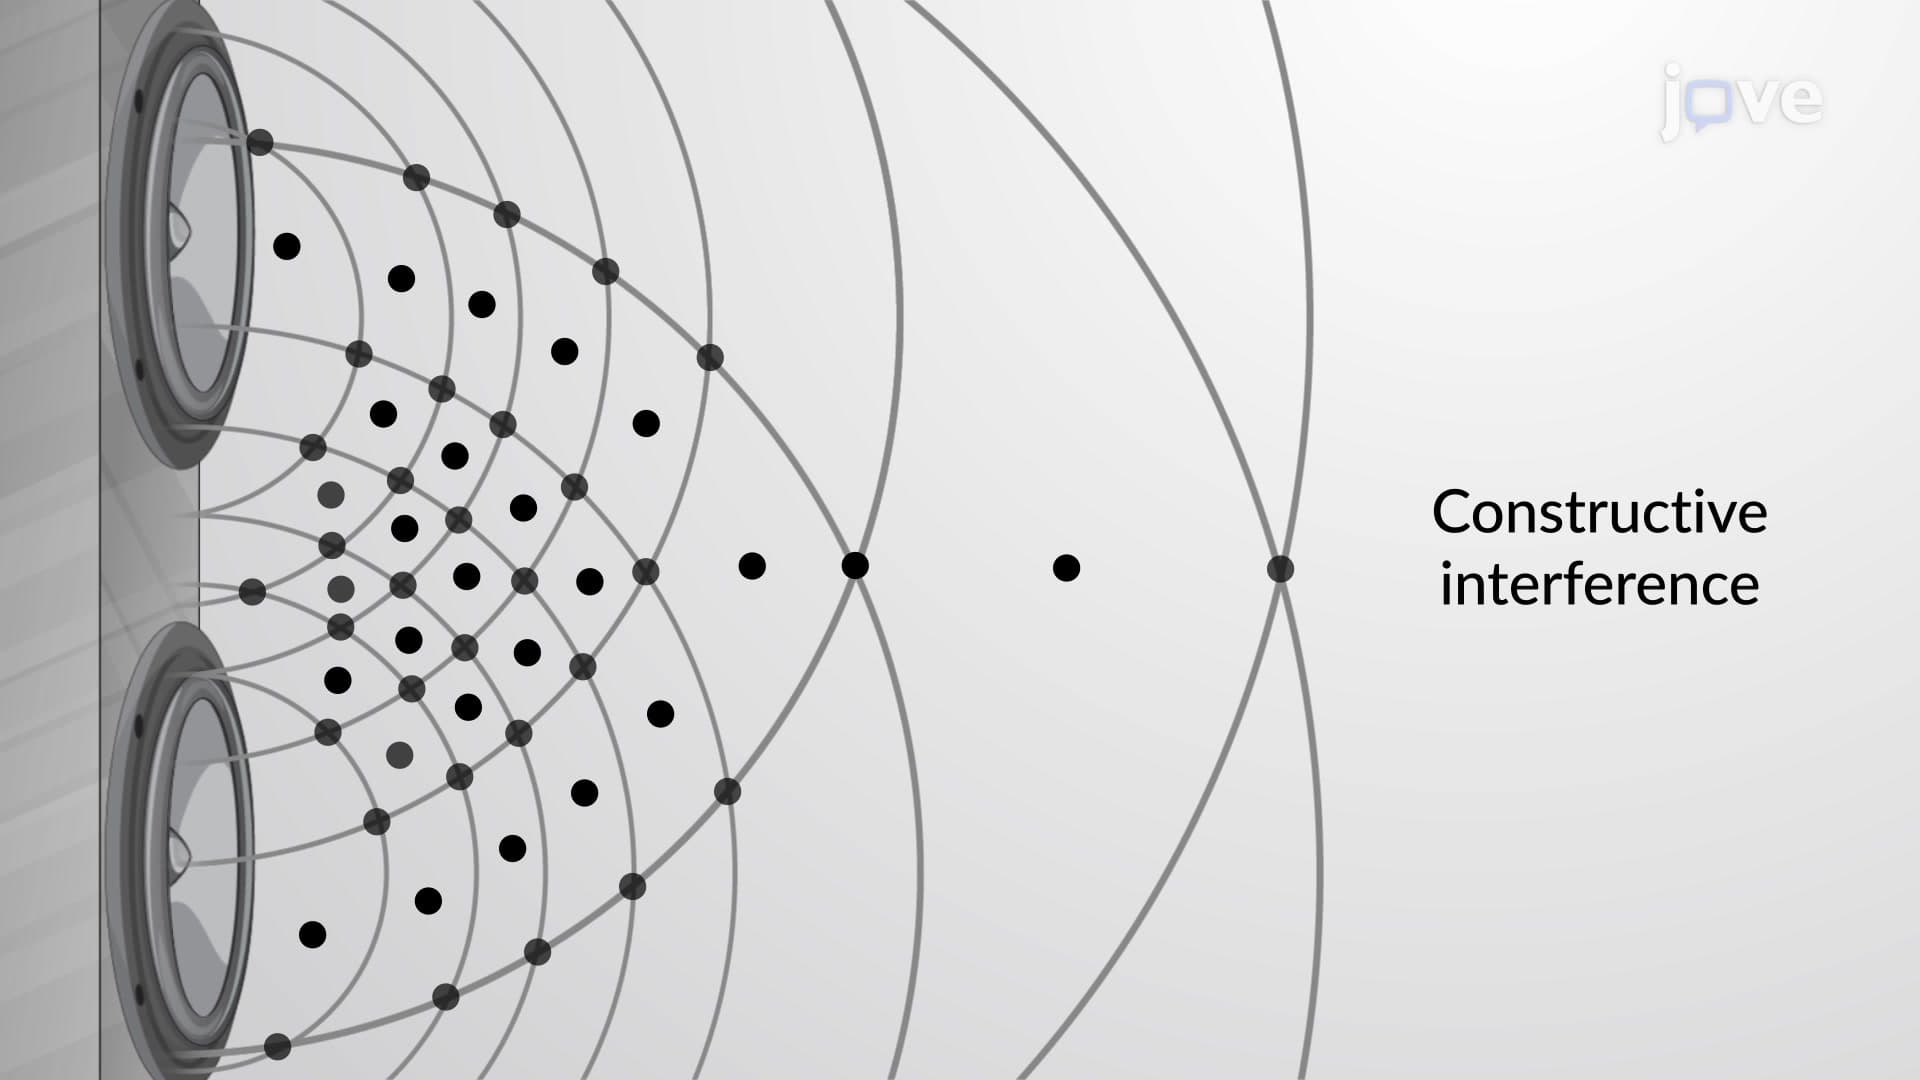
Interference: Path Lengths
Two special sources may be considered when they are in phase. This can be easily achieved by feeding the two sources from the same source. An example would be synchronizing the two speakers by feeding them with the same source, such as the sound waves produced by a tuning fork. This setup ensures that the two sources have the same frequency and are...