Related Experiment Video
Updated: Jul 2, 2025


Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
NUMERICALLY STABLE SOLUTION TO THE 6R PROBLEM OF INVERSE KINEMATICS
Xin Cao1, Evangelos A Coutsias1,2, Sara Pollock3
1Department of Applied Mathematics and Statistics, Stony Brook University, Stony Brook, NY 11794, United States.

Abstract:
In this paper, a stable and accurate algorithm to compute all solutions of the inverse kinematics problem of a 6 revolute manipulator chain is presented. A system of equations is constructed based on the fundamental closure conditions, leading to a closed algebraic system of 20 equations involving 16 quantities, composed of trigonometric functions of five among the six unknown joint angles. Two among these five are stably eliminated using singular value decomposition (SVD) avoiding the need to consider special cases. The resulting system of equations involving three unknowns is solved by conversion to a generalized eigenvalue problem. The remaining three unknown angles are obtained using the previously computed pseudoinverse. In this formulation we exploit the inherently complex form of the system reducing it to 10 complex equations in 9 quantities, which substantially accelerates the SVD computation. The method's robustness is demonstrated through a comparison to current methods and several examples including known problematic cases where some axis or link lengths vanish, or some joint angles are 180 degrees, as well as cases where multiple eigenvalues arise.
More Related Videos
 07:43
In Vivo Quantification of Hip Arthrokinematics during Dynamic Weight-bearing Activities using Dual Fluoroscopy
Published on: July 2, 2021
 08:40
Isokinetic Robotic Device to Improve Test-Retest and Inter-Rater Reliability for Stretch Reflex Measurements in Stroke Patients with Spasticity
Published on: June 12, 2019
Related Concept Videos
 01:15
Kinematic Equations: Problem Solving
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
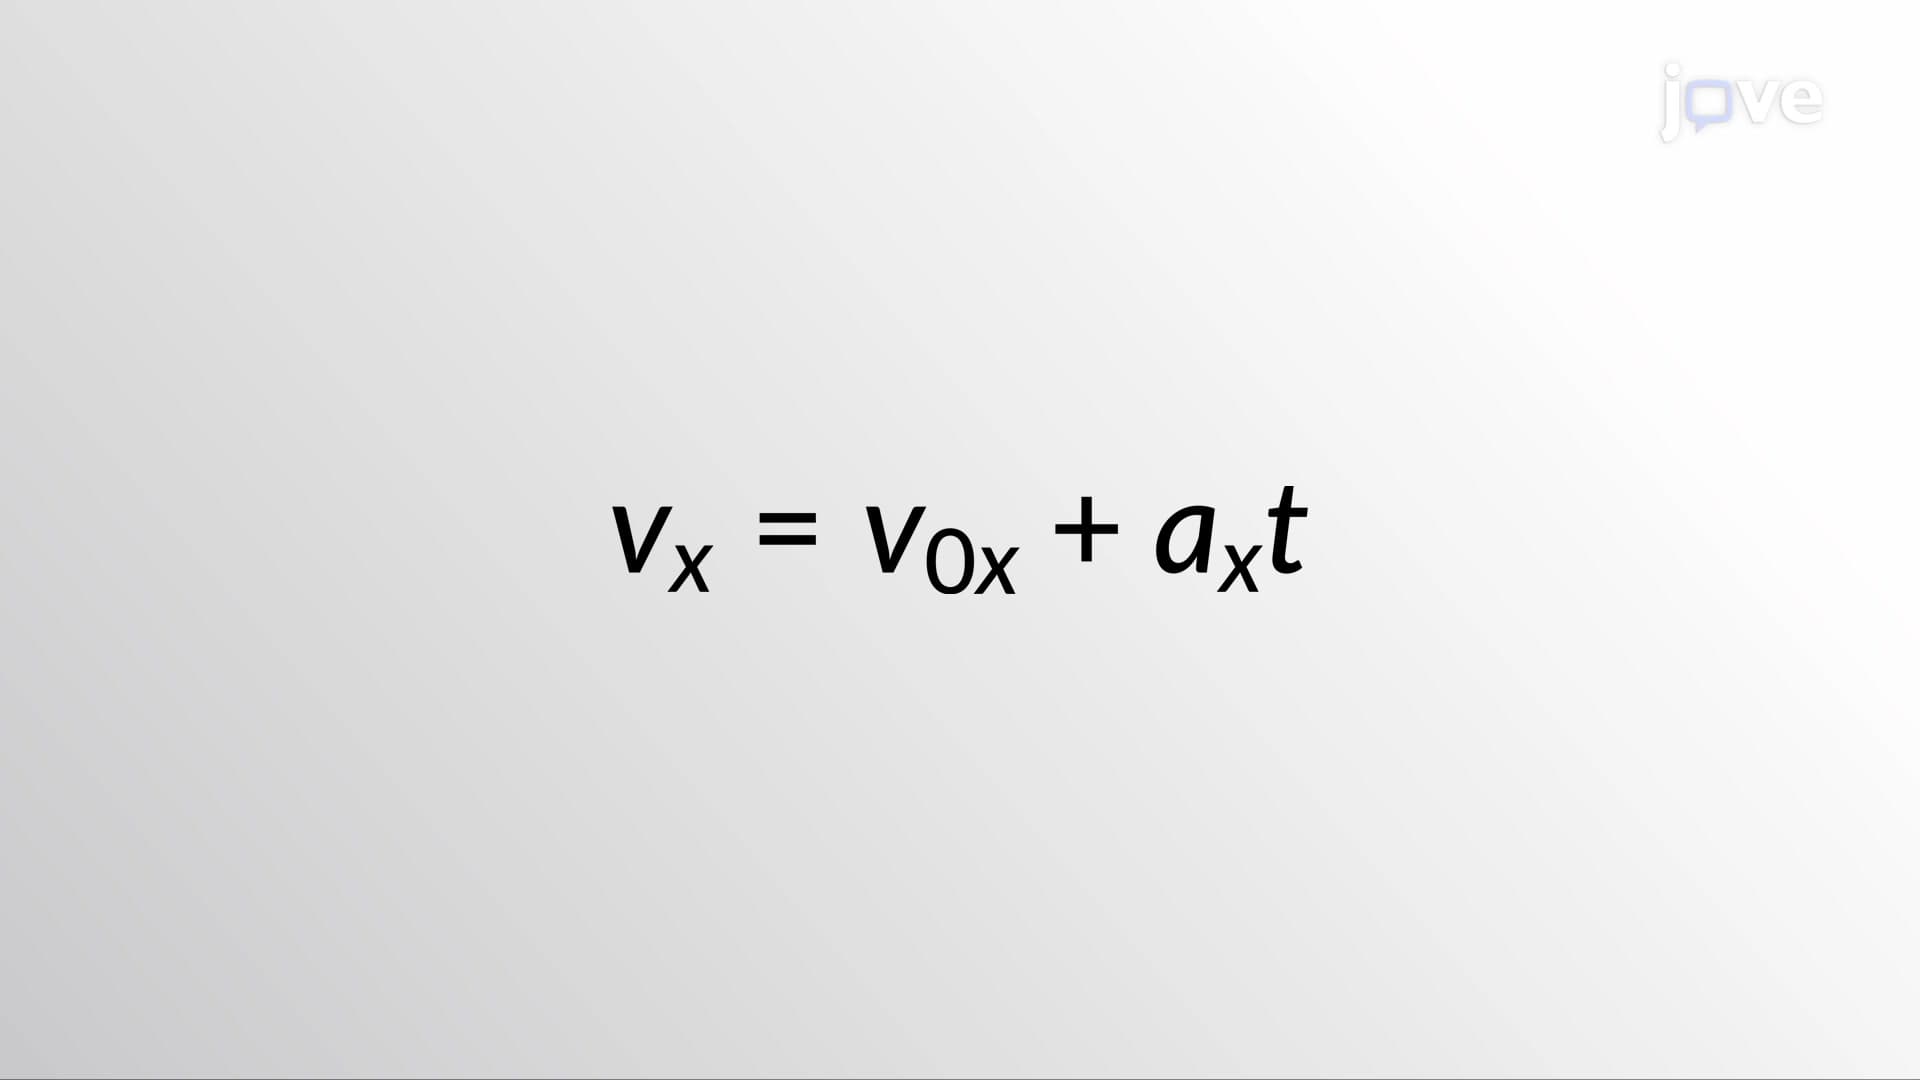 01:26
Kinematic Equations - I
 00:49
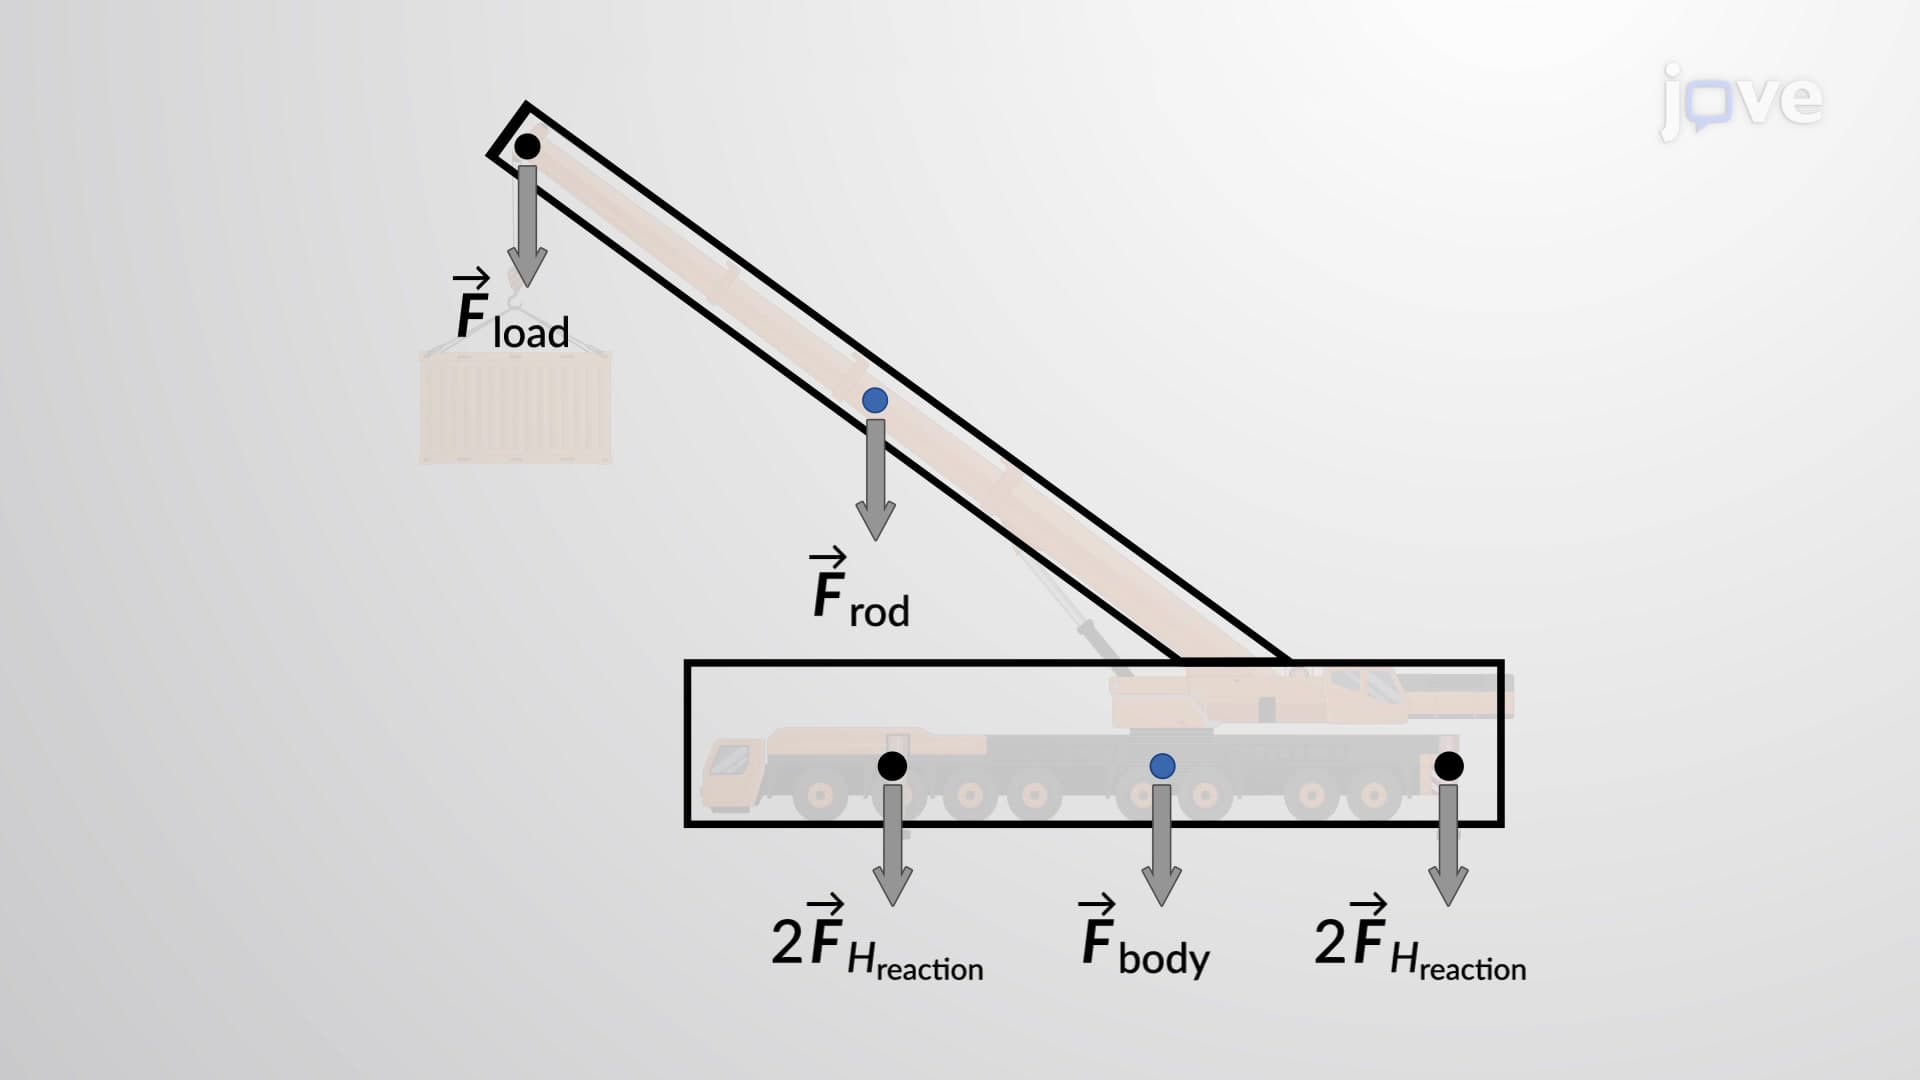
Rigid Body Equilibrium Problems - I