Related Experiment Video
Updated: Jul 2, 2025


Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
Human arm redundancy: a new approach for the inverse kinematics problem
Avi Barliya1, Nili Krausz1,2, Hila Naaman1
1Motor Control for Humans and Robotic Systems Laboratory, Weizmann Institute of Science, Rehovot, Central, Israel.

Abstract:
The inverse kinematics (IK) problem addresses how both humans and robotic systems coordinate movement to resolve redundancy, as in the case of arm reaching where more degrees of freedom are available at the joint versus hand level. This work focuses on which coordinate frames best represent human movements, enabling the motor system to solve the IK problem in the presence of kinematic redundancies. We used a multi-dimensional sparse source separation method to derive sets of basis (or source) functions for both the task and joint spaces, with joint space represented by either absolute or anatomical joint angles. We assessed the similarities between joint and task sources in each of these joint representations, finding that the time-dependent profiles of the absolute reference frame's sources show greater similarity to corresponding sources in the task space. This result was found to be statistically significant. Our analysis suggests that the nervous system represents multi-joint arm movements using a limited number of basis functions, allowing for simple transformations between task and joint spaces. Additionally, joint space seems to be represented in an absolute reference frame to simplify the IK transformations, given redundancies. Further studies will assess this finding's generalizability and implications for neural control of movement.


Related Concept Videos
 01:15
Kinematic Equations: Problem Solving
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
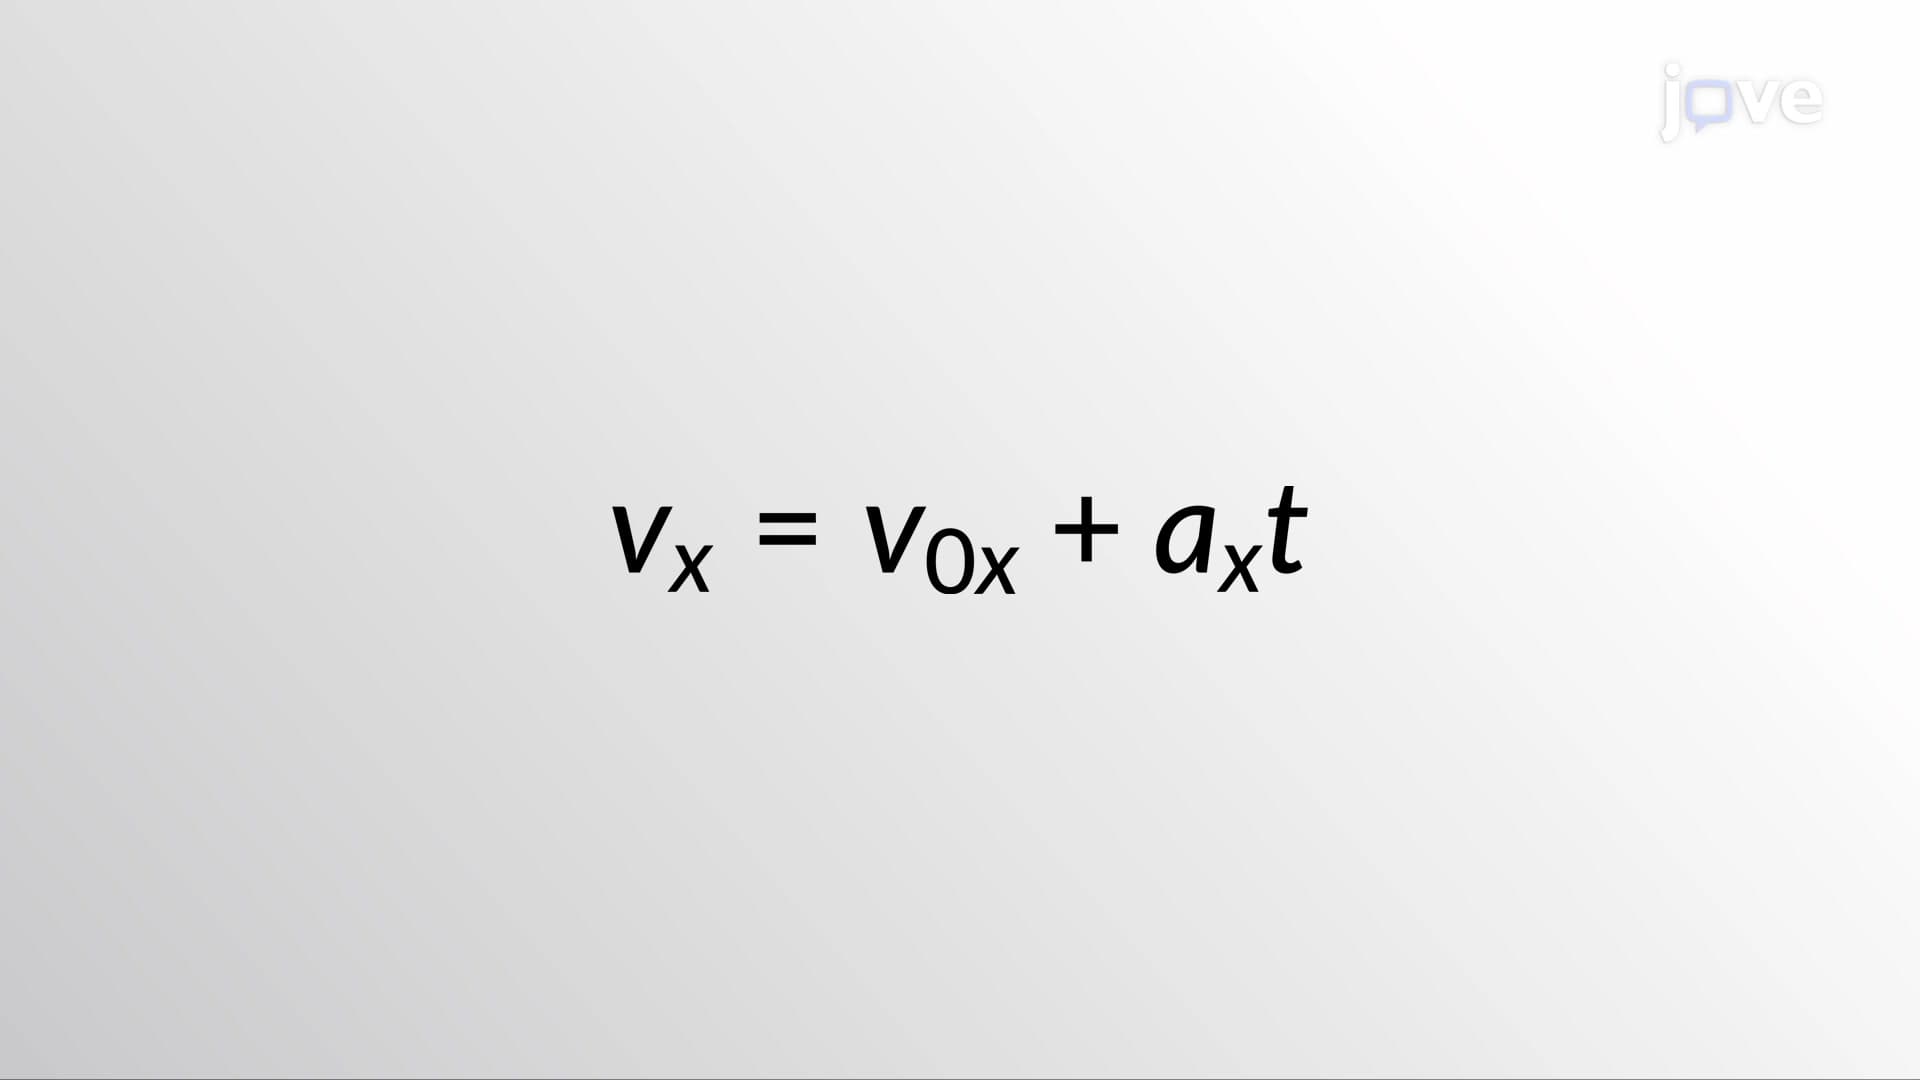 01:26
Kinematic Equations - I
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...