Sawtooth-characteristic-based free matrix integral inequality and its application to sampled-data systems

Ying Zhang1, Yong He1, Xing-Chen Shangguan1
1School of Automation, China University of Geosciences, Wuhan 430074, PR China; Hubei Key Laboratory of Advanced Control and Intelligent Automation for Complex Systems, Wuhan 430074, PR China; Engineering Research Center of Intelligent Technology for Geo-Exploration, Ministry of Education, Wuhan 430074, PR China.

Abstract:
The focus of this article is to present a sawtooth-characteristic-based free-matrix integral inequality and to discuss its application to sampled-data systems (SDSs). Firstly, the free matrix, which is associated with the sawtooth characteristic of the input delay, is presented and incorporated into the integral inequality. In the development of inequality techniques, this is the first time that a free matrix has been associated with the sawtooth characteristic. On this basis, a corresponding sawtooth-characteristic-based free-matrix integral inequality is established, enabling estimation of the integral quadratic terms of the Lyapunov-Krasovskii functional (LKF) derivative. To overcome the challenges posed by second-order terms resulting from the proposed integral inequality, augmented system variables associated with the sawtooth characteristic are also introduced. Thus, the complicated calculation arising from second-order terms and the conservatism caused by the quadratic estimation of the LKF can be avoided. Finally, through the utilization of the sawtooth-characteristic-based free-matrix integral inequality, stability criteria with less conservatism are derived for the SDSs in the form of linear matrix inequalities. The superiority of the proposed approach is illustrated through two numerical examples and a simplified sampled-data based power market.
Related Concept Videos
 01:15
Sampling Theorem
 01:22
Basic Continuous Time Signals
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...
 01:11
Sampling Continuous Time Signal
In the...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:17
Bandpass Sampling
A bandpass signal has a spectrum with a lower frequency limit, denoted as ω1, and an upper frequency limit, denoted as ω2....
 01:16
Basic Discrete Time Signals
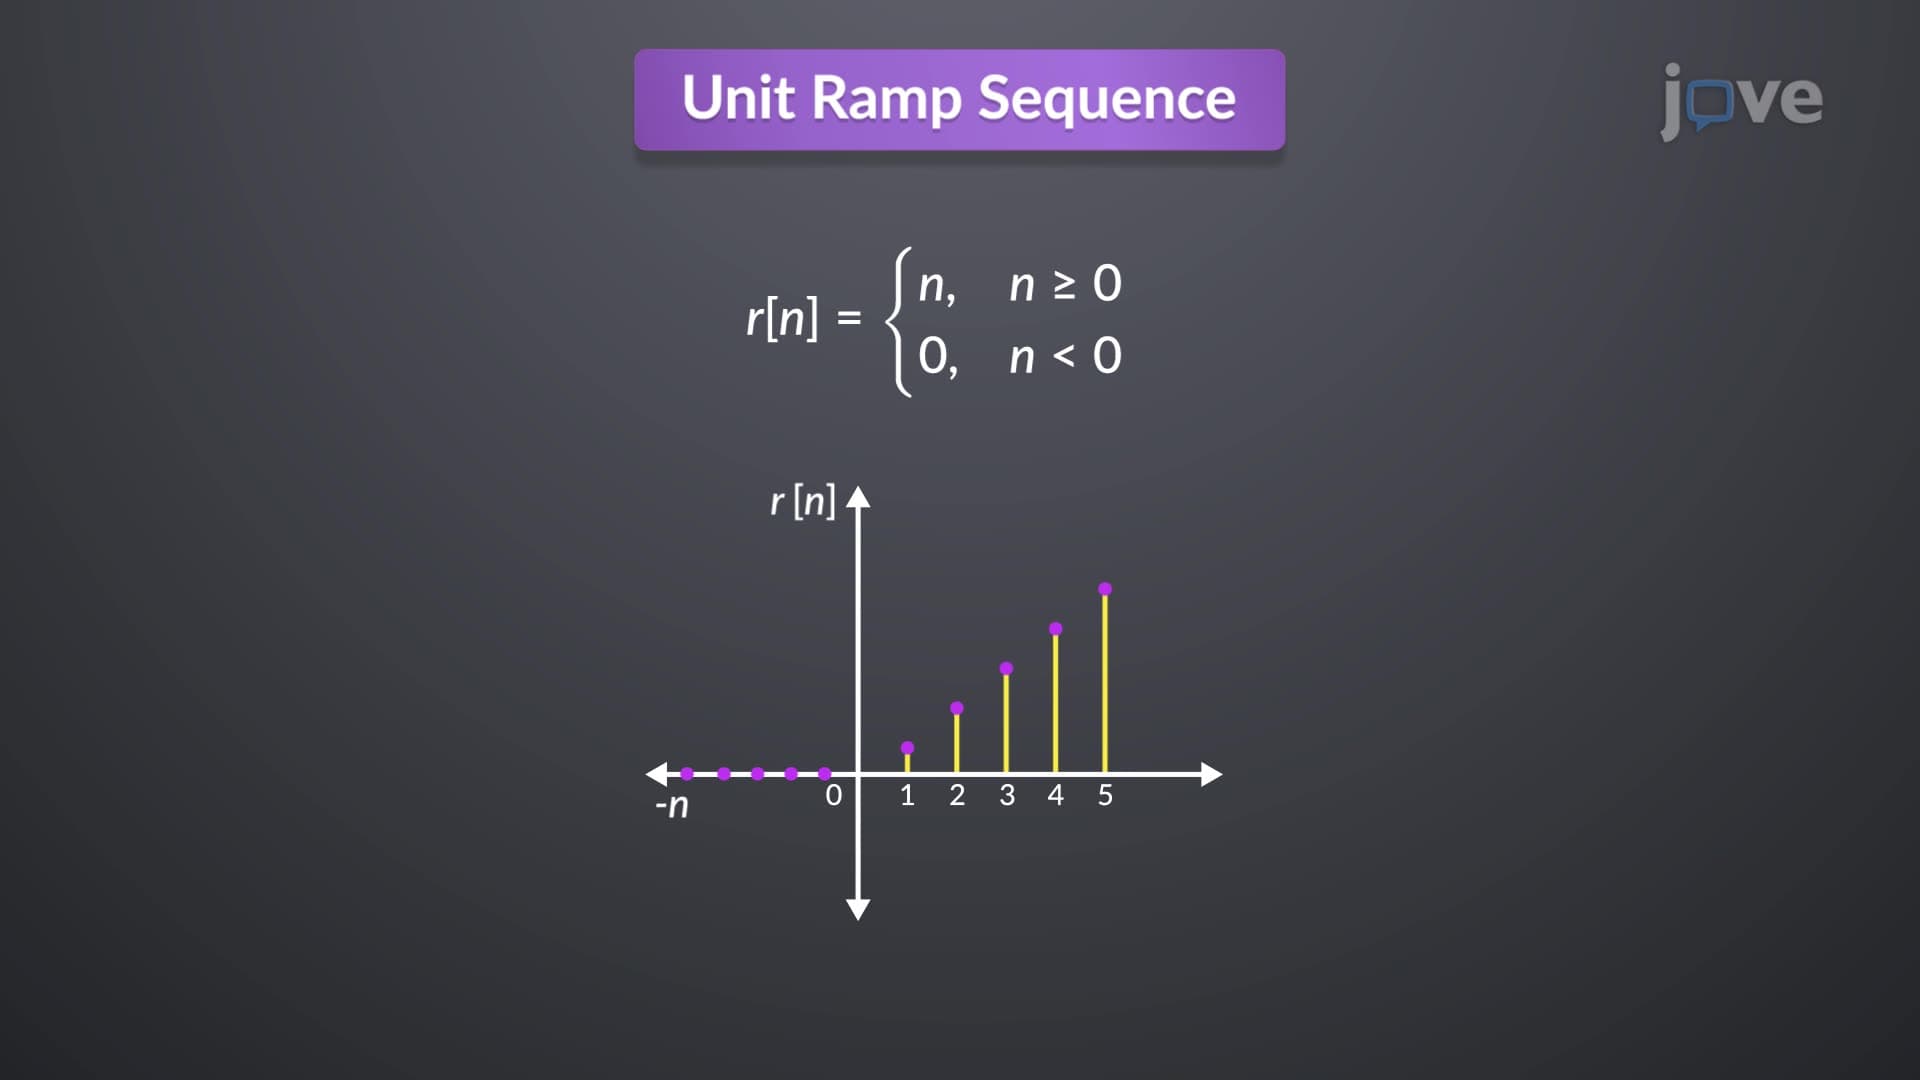
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is...