Related Experiment Video
Updated: Jul 1, 2025


Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Design and locomotion characteristic analysis of two kinds of tensegrity hopping robots
Jixue Mo1, Hao Fang2, Qingkai Yang2
1Department of Strategic and Advanced Interdisciplinary Research, Peng Cheng Laboratory, Shenzhen 518055, China.

Abstract:
This study proposed two kinds of tensegrity hopping robots, which were actuated by push-pull electromagnets and servo motors, respectively. Both tensegrity robots are able to conduct stable and consecutive hopping actions. This paper covers the robots' structural designs, theoretical modeling of the hopping actuators, and detailed analysis of the robot's self-righting properties, all of which are validated by corresponding experimental and simulational results. The first hopping robot could hop forward at an average speed of 0.641 body length/s. Although the second robot has a lower moving speed of 0.237 body length/s, its average jumping height of 0.301 m is nearly 2.5 times higher than that of the first robot. Then compared with other tensegrity rolling robots, the proposed two robots show obvious advantages in locomotion performance over their counterparts. Therefore, the proposed robots can have large potential in many fields such as space exploration, urban search, military surveillance, etc.


Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:14
Stability of structures
 01:16
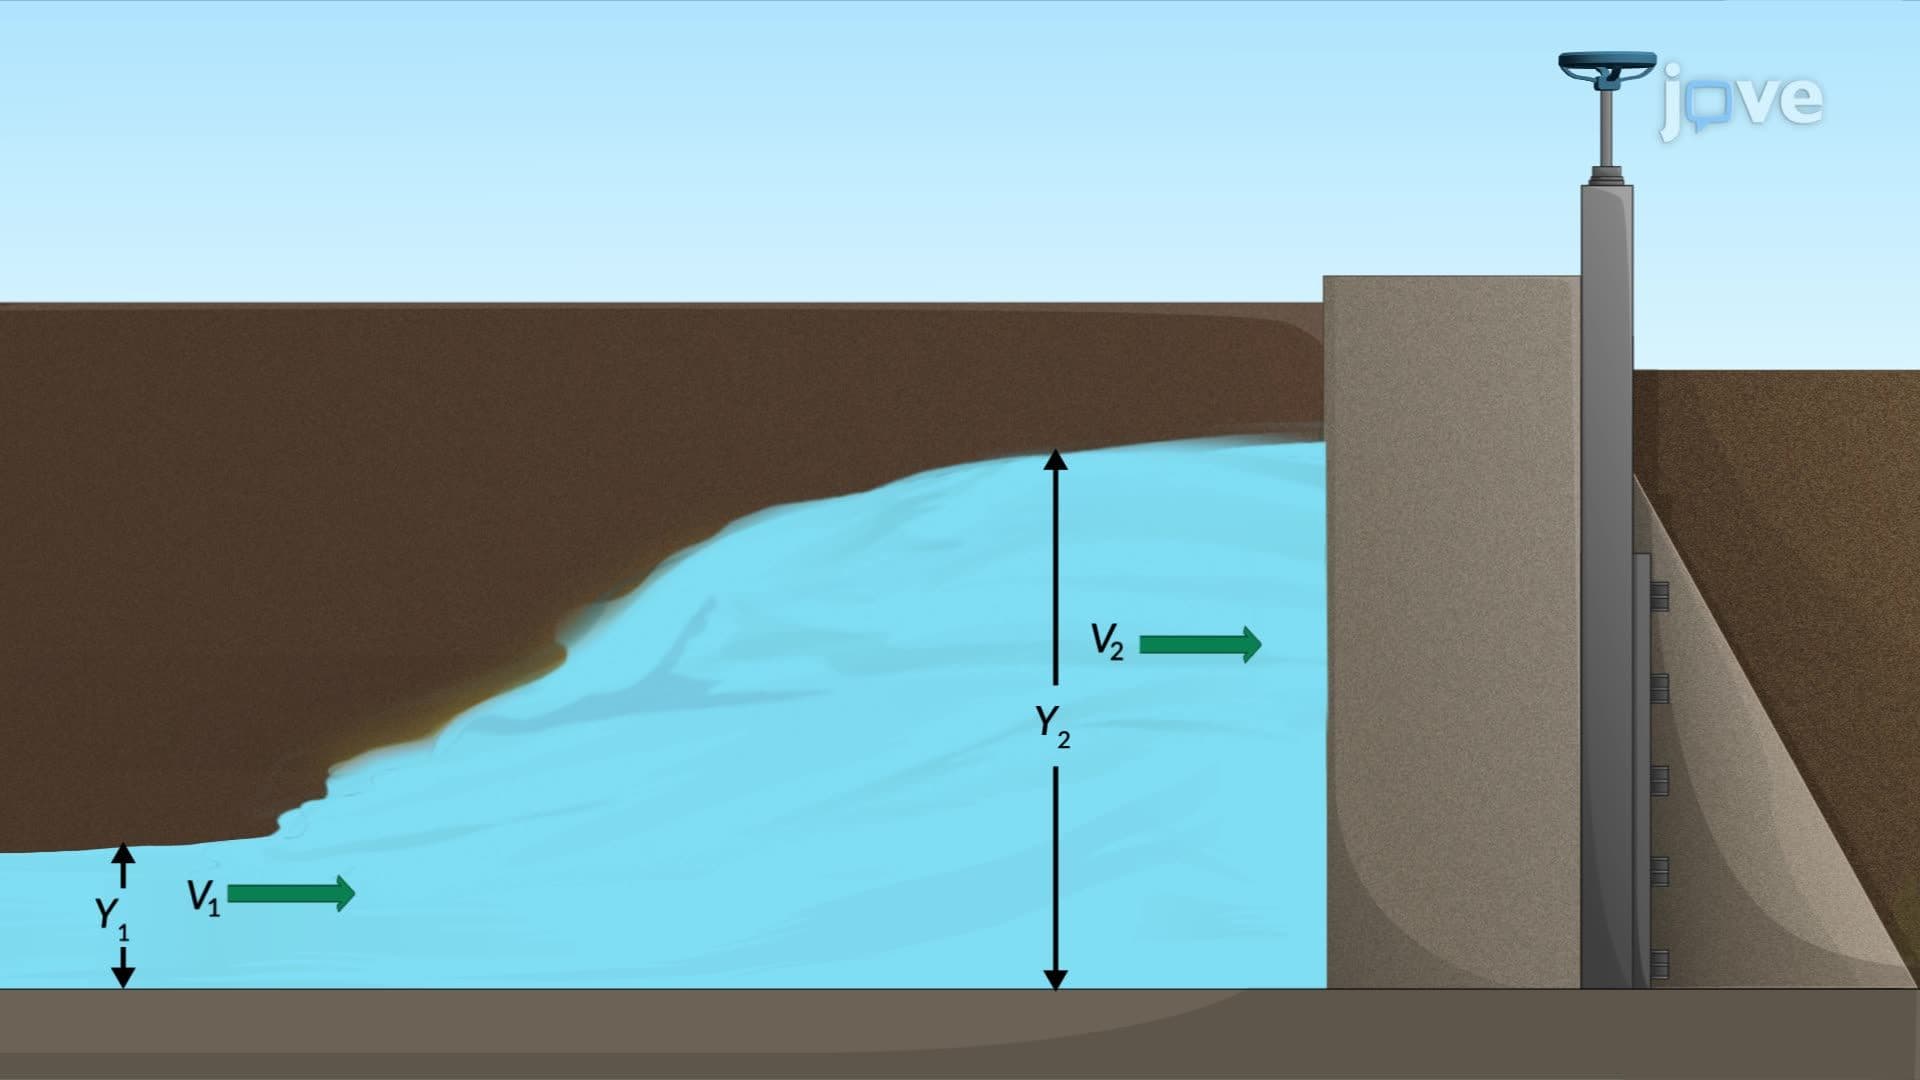
Hydraulic Jump: Problem Solving
 01:18
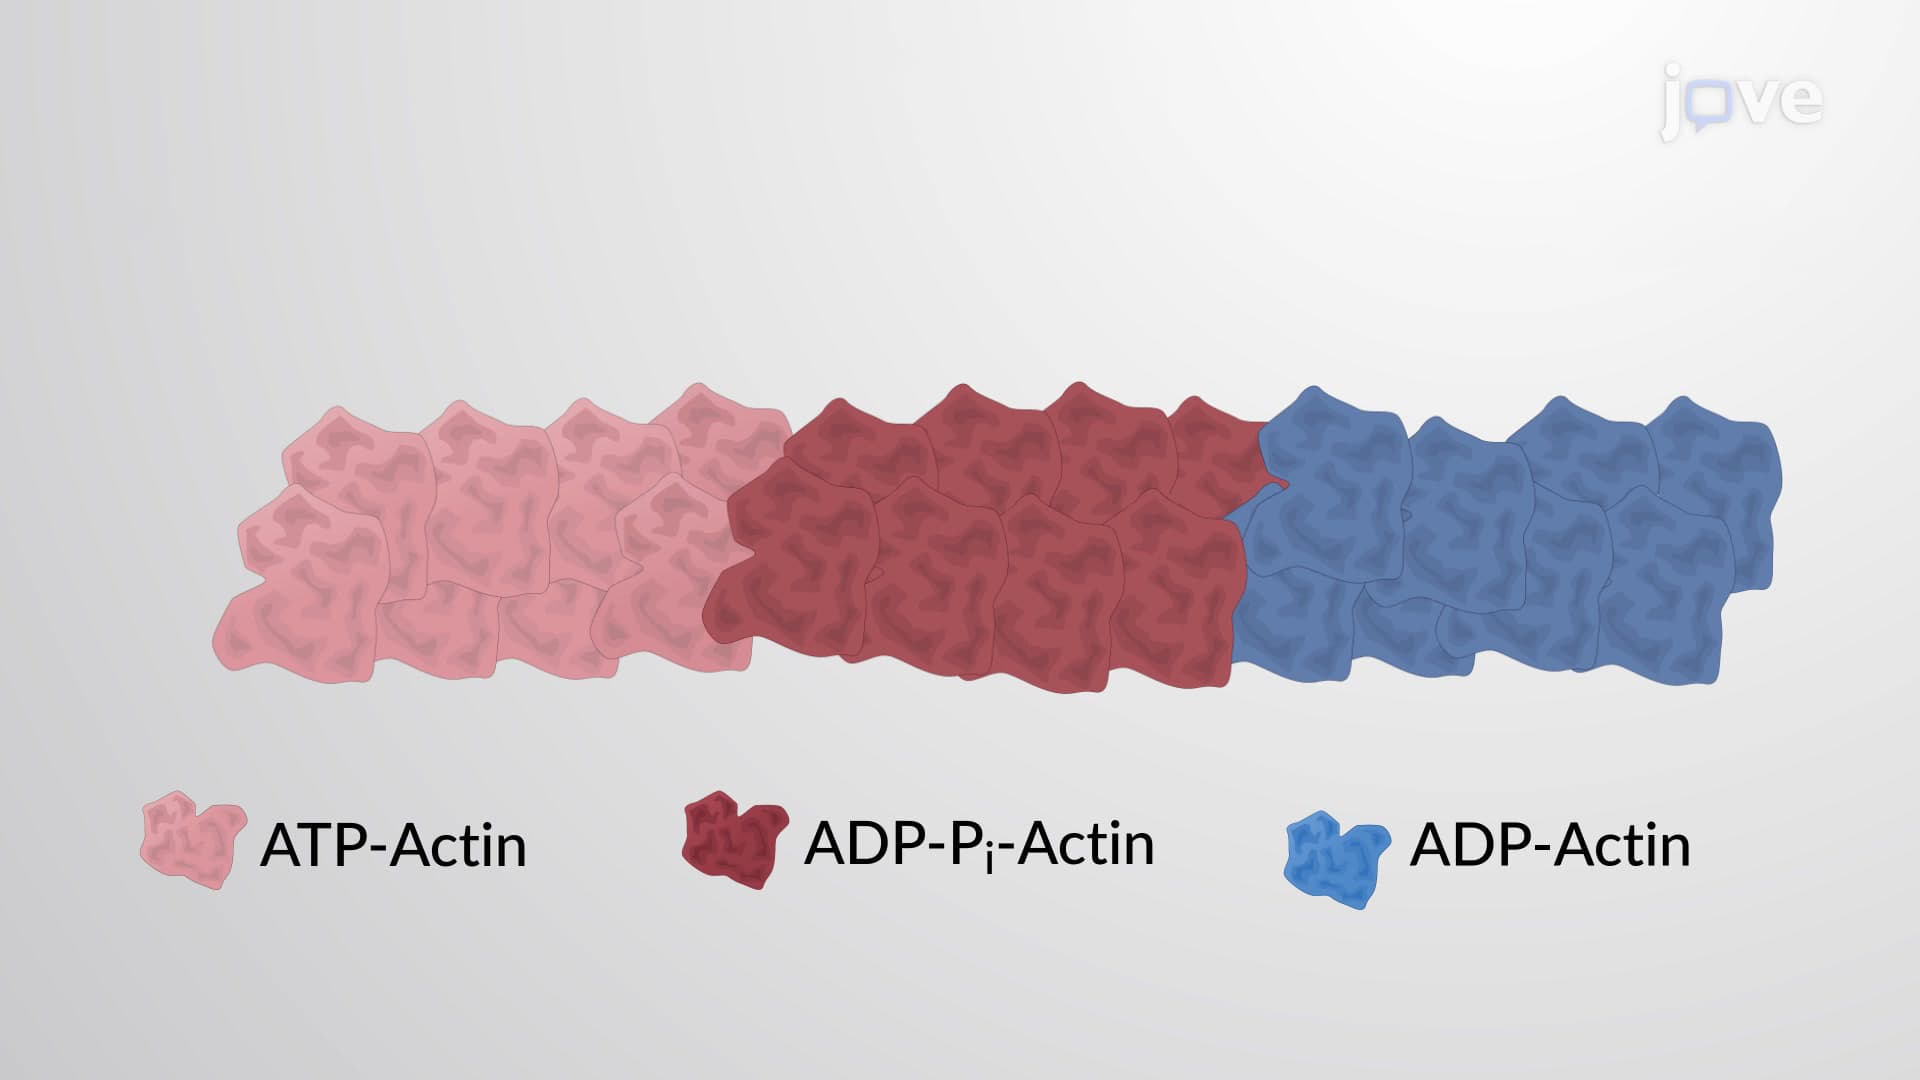
Actin Treadmilling
 01:09
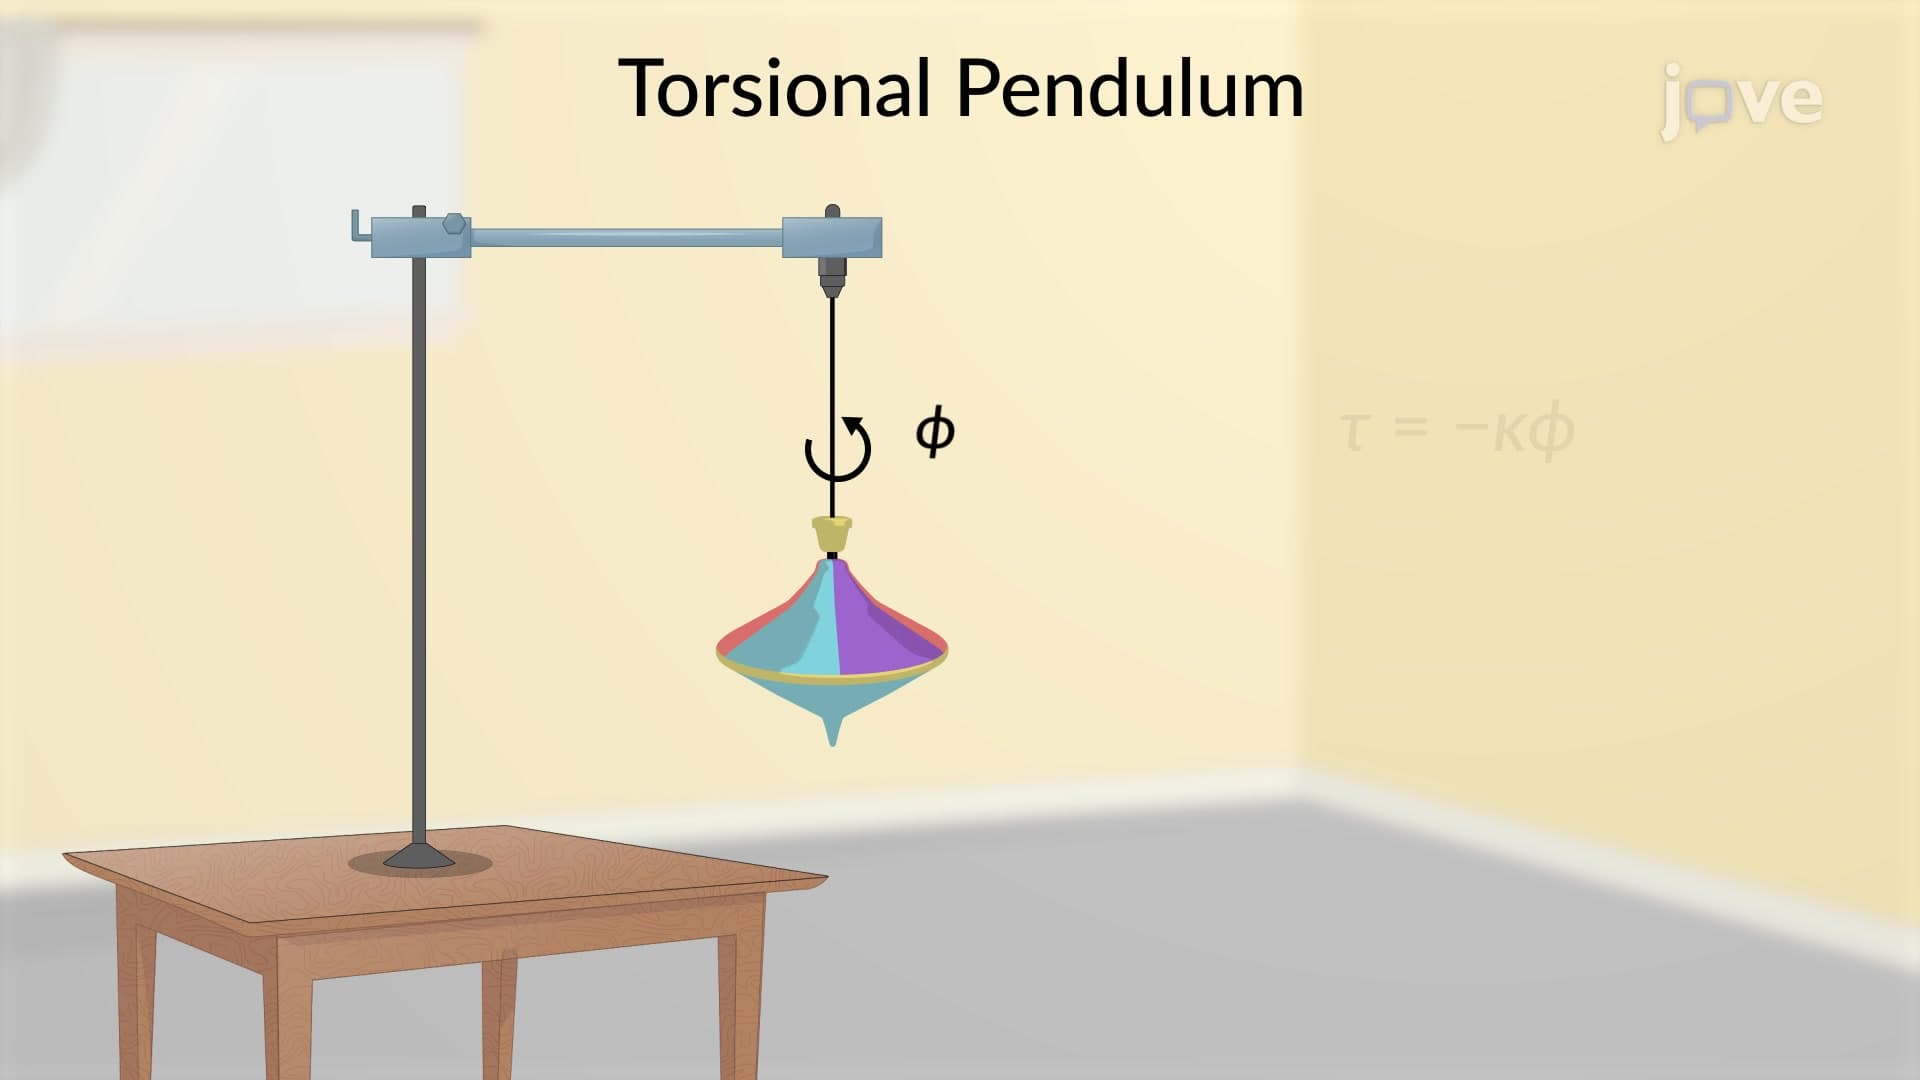
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...