Related Experiment Video
Updated: Jun 30, 2025


Closed-loop Neuro-robotic Experiments to Test Computational Properties of Neuronal Networks
Published on: March 2, 2015
Development of an MRI-compatible robotic perturbation system for studying the task-dependent contribution of the
Rebecca C Nikonowicz1, Fabrizio Sergi1,2
1Department of Biomedical Engineering, University of Delaware, 540 S College Ave, Newark, DE 19713, USA.

Abstract:
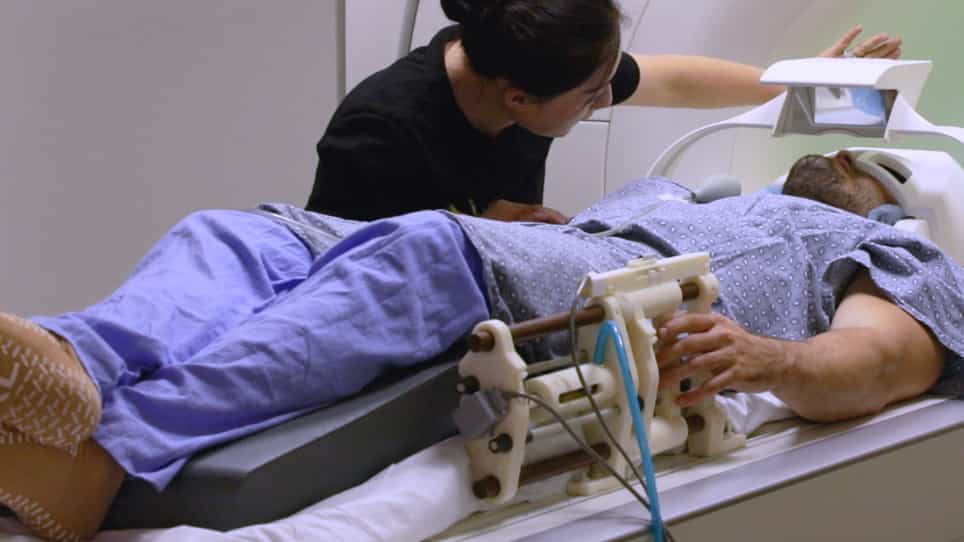
Methodological constraints have hindered direct in vivo measurement of reticulospinal tract (RST) function. The RST is thought to contribute to the increase in the amplitude of a long latency response (LLR), a stereotypical response evoked in stretched muscles, that arises when participants are asked to "resist" a perturbation. Thus, functional magnetic resonance imaging (fMRI) during robot-evoked LLRs under different task goals may be a method to measure motor-related RST function. We have developed the Dual Motor StretchWrist (DMSW), a new MR-compatible robotic perturbation system, and validated its functionality via experiments that used surface electromyography (sEMG) and fMRI. A first study was conducted outside the MRI scanner on six participants using sEMG to measure wrist flexor muscle activity associated with LLRs under different task instructions. Participants were given a Yield or Resist instruction before each trial and performance feedback based on the measured resistive torque was provided after every "Resist" trial to standardize LLR amplitude (LLRa). In a second study, ten participants completed two sessions of blocked perturbations under 1) Yield, 2) Resist, and 3) Yield Slow task conditions (control) during whole-brain fMRI. Statistical analysis of sEMG data shows significantly greater LLRa in Resist relative to Yield. Analysis of functional images shows increased activation primarily in the bilateral medulla and midbrain, and contralateral pons and primary motor cortex in the Resist condition. The results validate the capability of the DMSW to elicit LLRs of wrist muscles with different amplitudes as a function of task instruction, and its capability of simultaneous operation during fMRI.
More Related Videos
 07:34
Functional MRI in Conjunction with a Novel MRI-compatible Hand-induced Robotic Device to Evaluate Rehabilitation of Individuals Recovering from Hand Grip Deficits
Published on: November 23, 2019
 10:51
An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011