Related Experiment Video
Updated: Jun 27, 2025
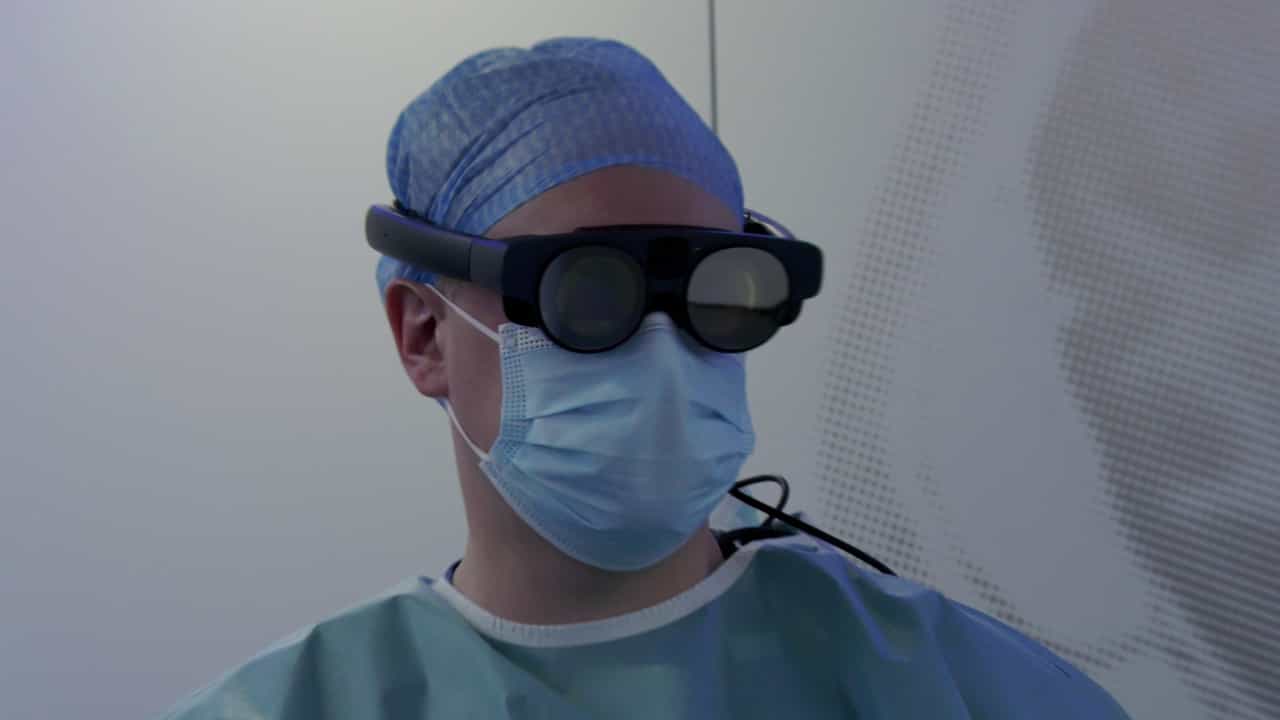
Pedicle Screw Placement Using an Augmented Reality Head-Mounted Display in a Porcine Model
Published on: May 24, 2024
Vision-based estimation of manipulation forces by deep learning of laparoscopic surgical images obtained in a porcine
Kimihiko Masui1, Naoto Kume2, Megumi Nakao3
1Department of Urology, Graduate School of Medicine, Kyoto University, 54 Shogoin-kawahara-cho, Sakyo-ku, Kyoto, 606-8507, Japan.

Abstract:
In robot-assisted surgery, in which haptics should be absent, surgeons experience haptics-like sensations as "pseudo-haptic feedback". As surgeons who routinely perform robot-assisted laparoscopic surgery, we wondered if we could make these "pseudo-haptics" explicit to surgeons. Therefore, we created a simulation model that estimates manipulation forces using only visual images in surgery. This study aimed to achieve vision-based estimations of the magnitude of forces during forceps manipulation of organs. We also attempted to detect over-force, exceeding the threshold of safe manipulation. We created a sensor forceps that can detect precise pressure at the tips with three vectors. Using an endoscopic system that is used in actual surgery, images of the manipulation of excised pig kidneys were recorded with synchronized force data. A force estimation model was then created using deep learning. Effective detection of over-force was achieved if the region of the visual images was restricted by the region of interest around the tips of the forceps. In this paper, we emphasize the importance of limiting the region of interest in vision-based force estimation tasks.