Outline of an evolutionary morphology generator towards the modular design of a biohybrid catheter
Related Experiment Video
Updated: Aug 11, 2026
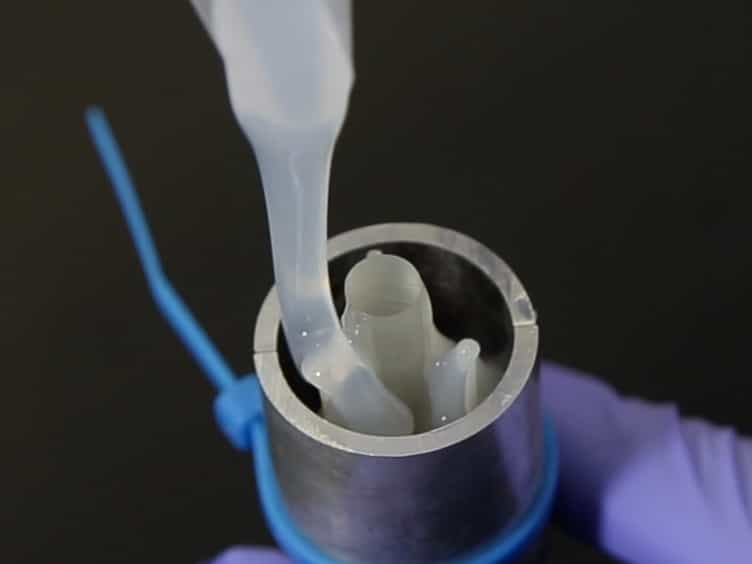
Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
Michail-Antisthenis Tsompanas1,2, Igor Balaz3
1School of Computing and Creative Technologies, University of the West of England, Bristol, United Kingdom.

Abstract:
Biohybrid machines (BHMs) are an amalgam of actuators composed of living cells with synthetic materials. They are engineered in order to improve autonomy, adaptability and energy efficiency beyond what conventional robots can offer. However, designing these machines is no trivial task for humans, provided the field's short history and, thus, the limited experience and expertise on designing and controlling similar entities, such as soft robots. To unveil the advantages of BHMs, we propose to overcome the hindrances of their design process by developing a modular modeling and simulation framework for the digital design of BHMs that incorporates Artificial Intelligence powered algorithms. Here, we present the initial workings of the first module in an exemplar framework, namely, an evolutionary morphology generator. As proof-of-principle for this project, we use the scenario of developing a biohybrid catheter as a medical device capable of arriving to hard-to-reach regions of the human body to release drugs. We study the automatically generated morphology of actuators that will enable the functionality of that catheter. The primary results presented here enforced the update of the methodology used, in order to better depict the problem under study, while also provided insights for the future versions of the software module.
Related Concept Videos
 02:19
Morphogenesis
 01:25
Electric Generator: Alternator
The magnetic flux passing through the coil varies sinusoidally as the loop rotates inside the magnetic field. This...
 01:18
Bioreactor Controls-II