Decentralized triangular relative localization of multiple UAVs based on relative range and inertial measurements
Related Experiment Video
Updated: Jun 27, 2025
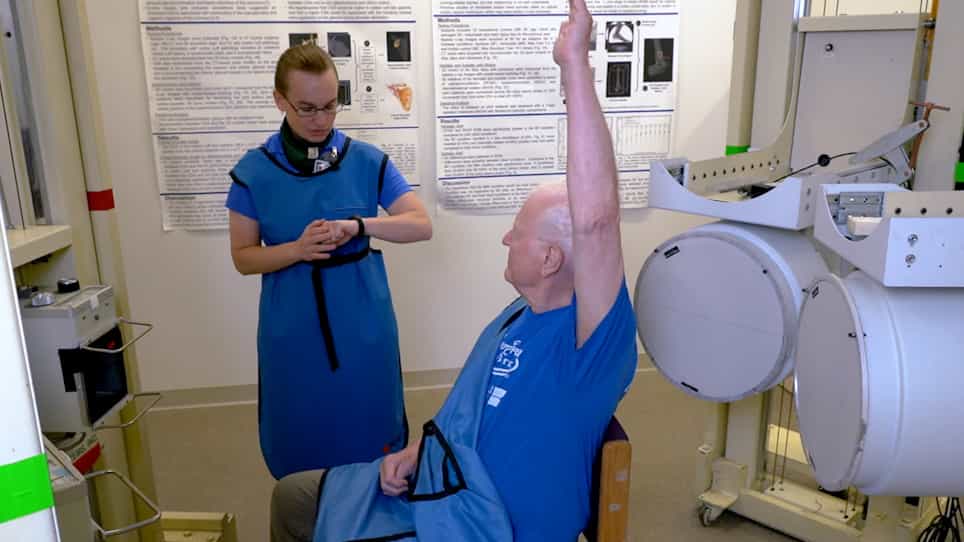
Measuring 3D In-vivo Shoulder Kinematics using Biplanar Videoradiography
Published on: March 12, 2021
Meysam Alizad1, Hadi Nobahari1
1Department of Aerospace Engineering, Sharif University of Technology, Iran.

Abstract:
In this paper, a novel algorithm for cooperative relative localization of multiple Unmanned Aerial Vehicles (UAVs) is proposed based on relative range and inertial measurements. In this algorithm, a relative motion estimation model is established for each group of three UAVs that can form a triangle in space. Each group member estimates the relative position and heading angle of the other group members and shares the estimation results with the other group members. When members satisfy the triangle law among their estimated relative position vectors, they can estimate more accurately. After analyzing the observability of the presented model, the necessary conditions for observability are also given, which are less restrictive compared to previous methods. Then, the presented method is compared with the decentralized consensus-based Kalman filter approach. The results of both methods are analyzed in the presence of noise and disturbances, and under the condition of disconnection between the members.
More Related Videos
Related Concept Videos
 01:30
Types of Global Positioning System Surveys
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:11
Relative Velocity in Two Dimensions
 01:26
Errors in Global Positioning System
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Design Example: Identifying the Locations of Monuments in the Field Using Global Positioning System Device