Leveraging Self-Supervised Vision Transformers for Segmentation-Based Transfer Function Design
Related Experiment Video
Updated: Jun 21, 2026
A Swin Transformer-Based Model for Thyroid Nodule Detection in Ultrasound Images
Published on: April 21, 2023

Abstract:
In volume rendering, transfer functions are used to classify structures of interest, and to assign optical properties such as color and opacity. They are commonly defined as 1D or 2D functions that map simple features to these optical properties. As the process of designing a transfer function is typically tedious and unintuitive, several approaches have been proposed for their interactive specification. In this article, we present a novel method to define transfer functions for volume rendering by leveraging the feature extraction capabilities of self-supervised pre-trained vision transformers. To design a transfer function, users simply select the structures of interest in a slice viewer, and our method automatically selects similar structures based on the high-level features extracted by the neural network. Contrary to previous learning-based transfer function approaches, our method does not require training of models and allows for quick inference, enabling an interactive exploration of the volume data. Our approach reduces the amount of necessary annotations by interactively informing the user about the current classification, so they can focus on annotating the structures of interest that still require annotation. In practice, this allows users to design transfer functions within seconds, instead of minutes. We compare our method to existing learning-based approaches in terms of annotation and compute time, as well as with respect to segmentation accuracy. Our accompanyingvideo showcases the interactivity and effectiveness of our method.


Related Concept Videos
 01:17
Properties of the z-Transform I
 01:21
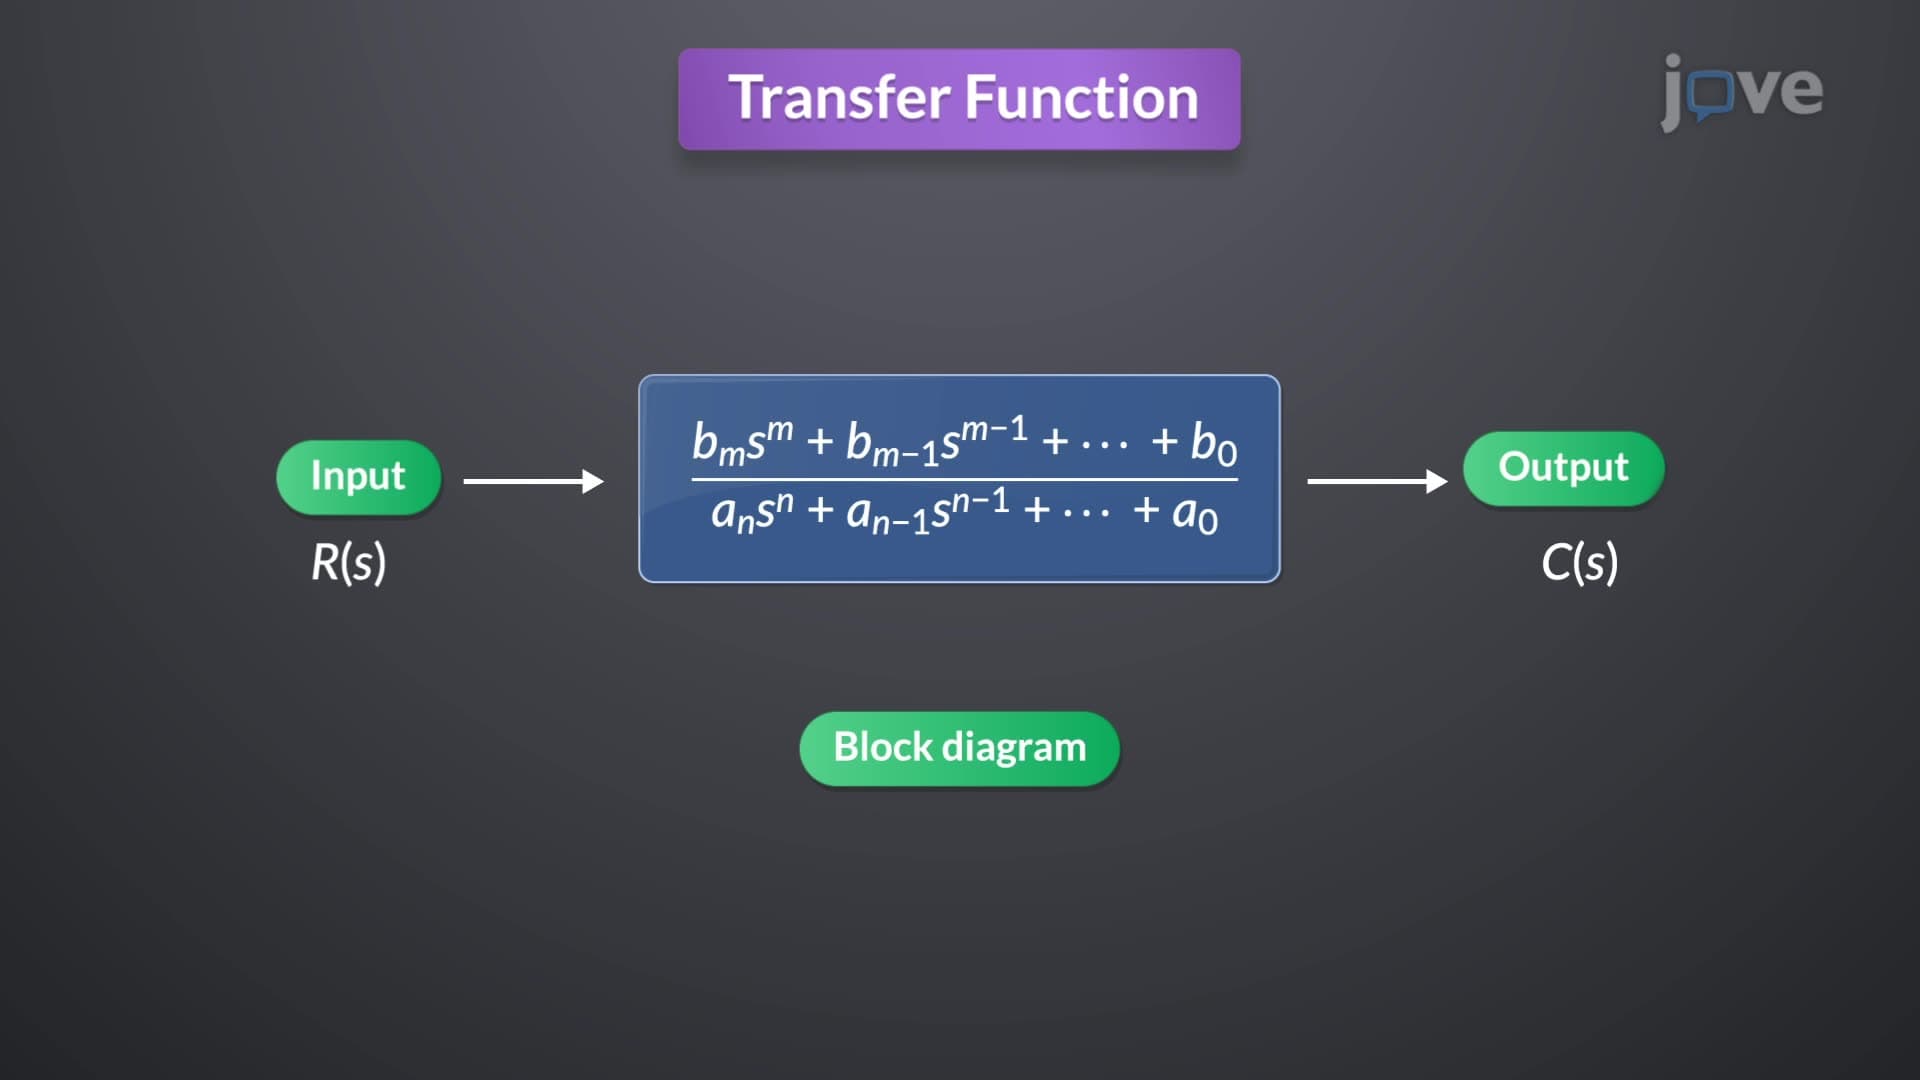
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:21
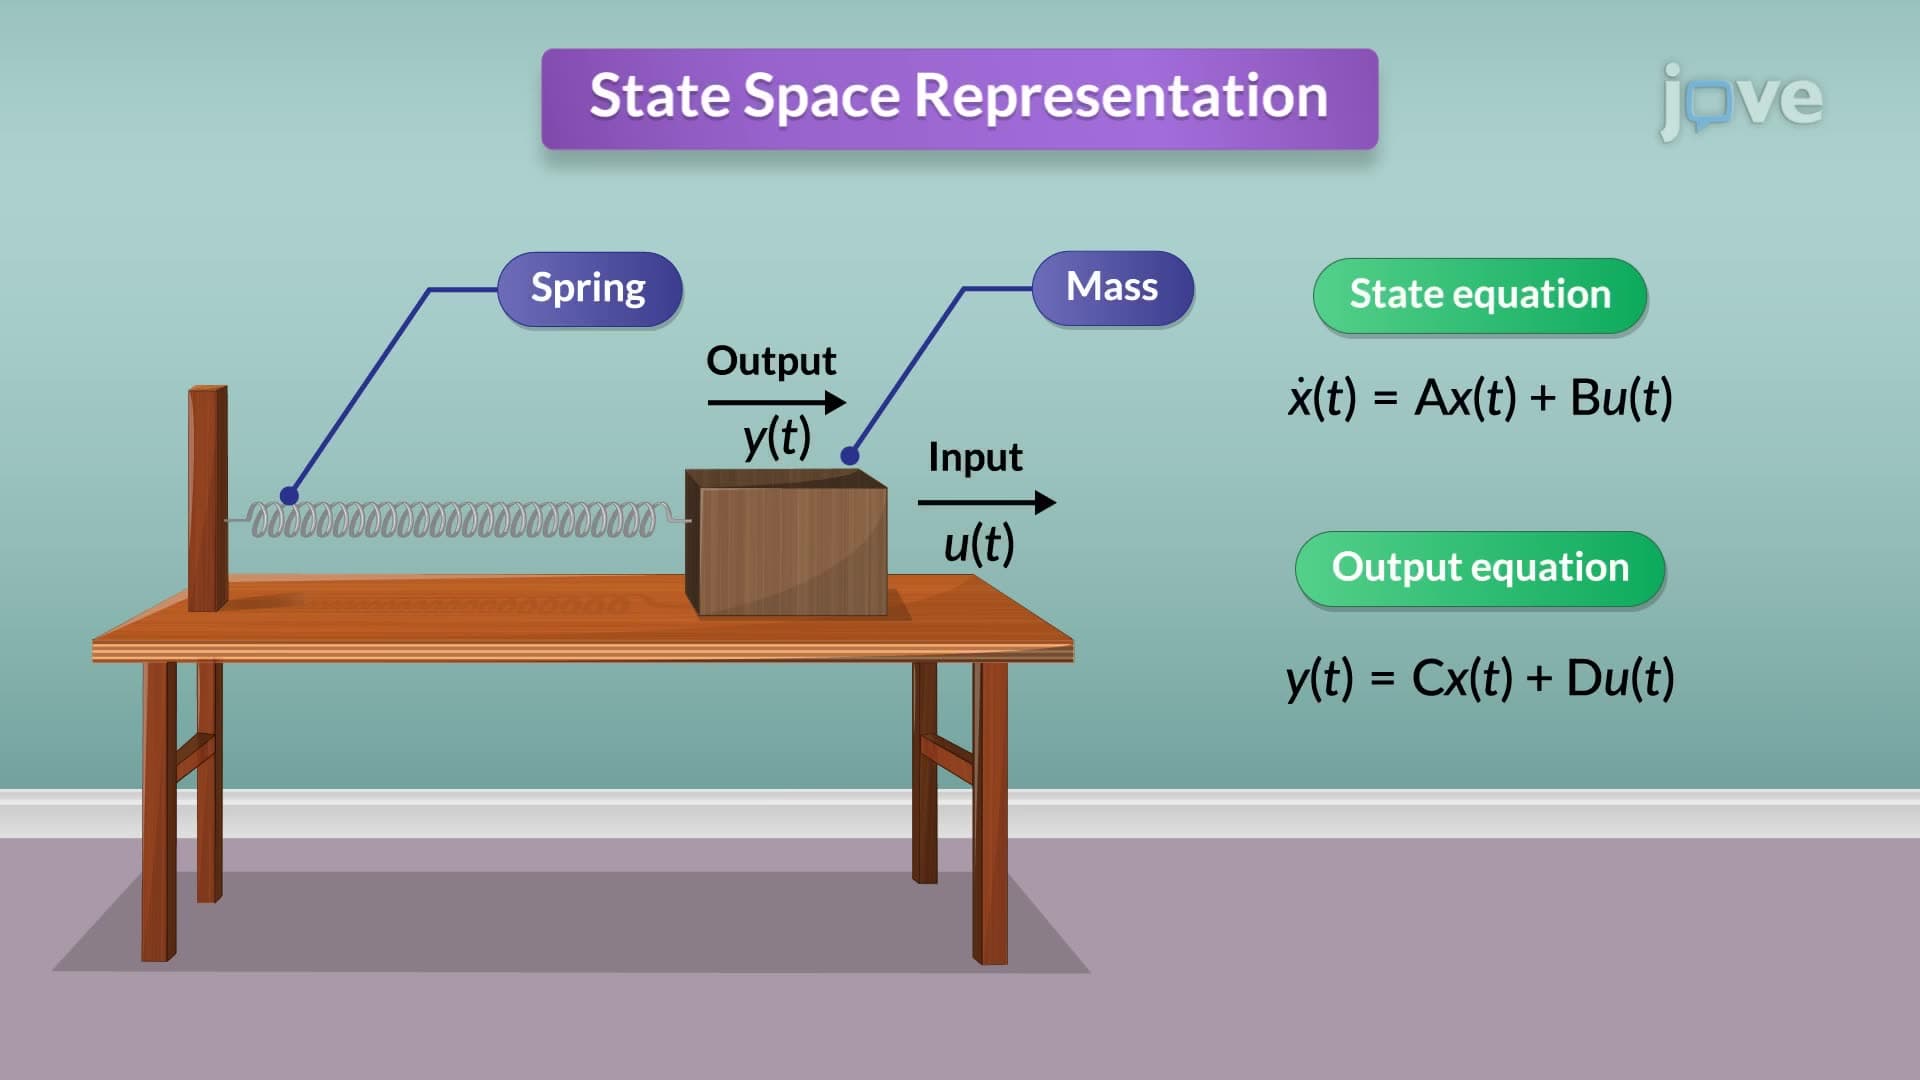
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:22
Phase-lead and Phase-lag Controllers
 01:20
Transformations of Functions III