Related Experiment Video
Updated: May 3, 2026
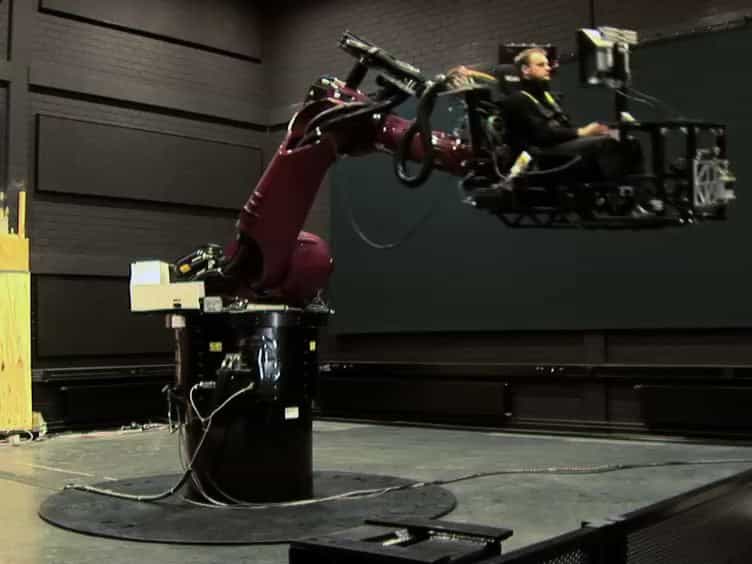

MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
A novel distributed meta-module motion design for modular robotic systems based on grid partition method
Enguang Guan1, Yao Wang1, Yulong Zhang2
1Logistics Engineering College, Shanghai Maritime University, Shanghai, China.

Abstract:
This article studies a meta-module motion design approach for homogenous modular robotic systems in self-configuration. By utilizing configuration diversity, scalability and unit-substitutability, homogenous modular robotic systems can be a promising approach to life detection and space exploration in the future. Based on the requirements of the potential applications, self-configuration can be considered as the precondition. As similar to swarm robotic systems, the distributed control strategy in which the modular robots are operated in a sequence of motion circles consist of 'detection'- 'decision'- 'execution' is of great significance. However, there is a limitation to the applicability of previously proposed work on the self-configuration topic, due to the fact that the self-configuration strategy execution suffers from the motion constraints of modular robots. In order to solve the problem, we propose a grid partition method that removes the gap between the locomotion of a single modular robot and the reconfiguration of the whole system. Under the analysis of the grid partition, the meta-module motion design is proposed to realize the distributed self-configuration strategy. We simulated the self-configuration in M-Lattice, a two-dimensional homogenous modular robotic system.


Related Concept Videos
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:30
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:21
Distributed Loads: Problem Solving
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:13
Motor Units
Motor units come in different sizes, with smaller units...