Effective action for dissipative and nonholonomic systems
Related Experiment Video
Updated: Jun 23, 2025

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Afshin Besharat1, Jury Radkovski1, Sergey Sibiryakov1
1Department of Physics and Astronomy, McMaster University, 1280 Main Street West, Hamilton, Ontario, Canada L8S 4M1 and Perimeter Institute for Theoretical Physics, Waterloo, Ontario, Canada N2L 2Y5.

Abstract:
We show that the action of a dynamical system can be supplemented by an effective action for its environment to reproduce arbitrary coordinate dependent ohmic dissipation and gyroscopic forces. The action is a generalization of the harmonic bath model and describes a set of massless interacting scalar fields in an auxiliary space coupled to the original system at the boundary. A certain limit of the model implements nonholonomic constraints. In the case of dynamics with nonlinearly realized symmetries the effective action takes the form of a two-dimensional nonlinear σ model. It provides a basis for application of path integral methods to general dissipative and nonholonomic systems.
Related Concept Videos
 01:22
Mechanical Systems
 01:18
First Law: Particles in Two-dimensional Equilibrium
Newton's first law tells us about...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:20
Types of Damping
 00:49
Rigid Body Equilibrium Problems - I
 01:21
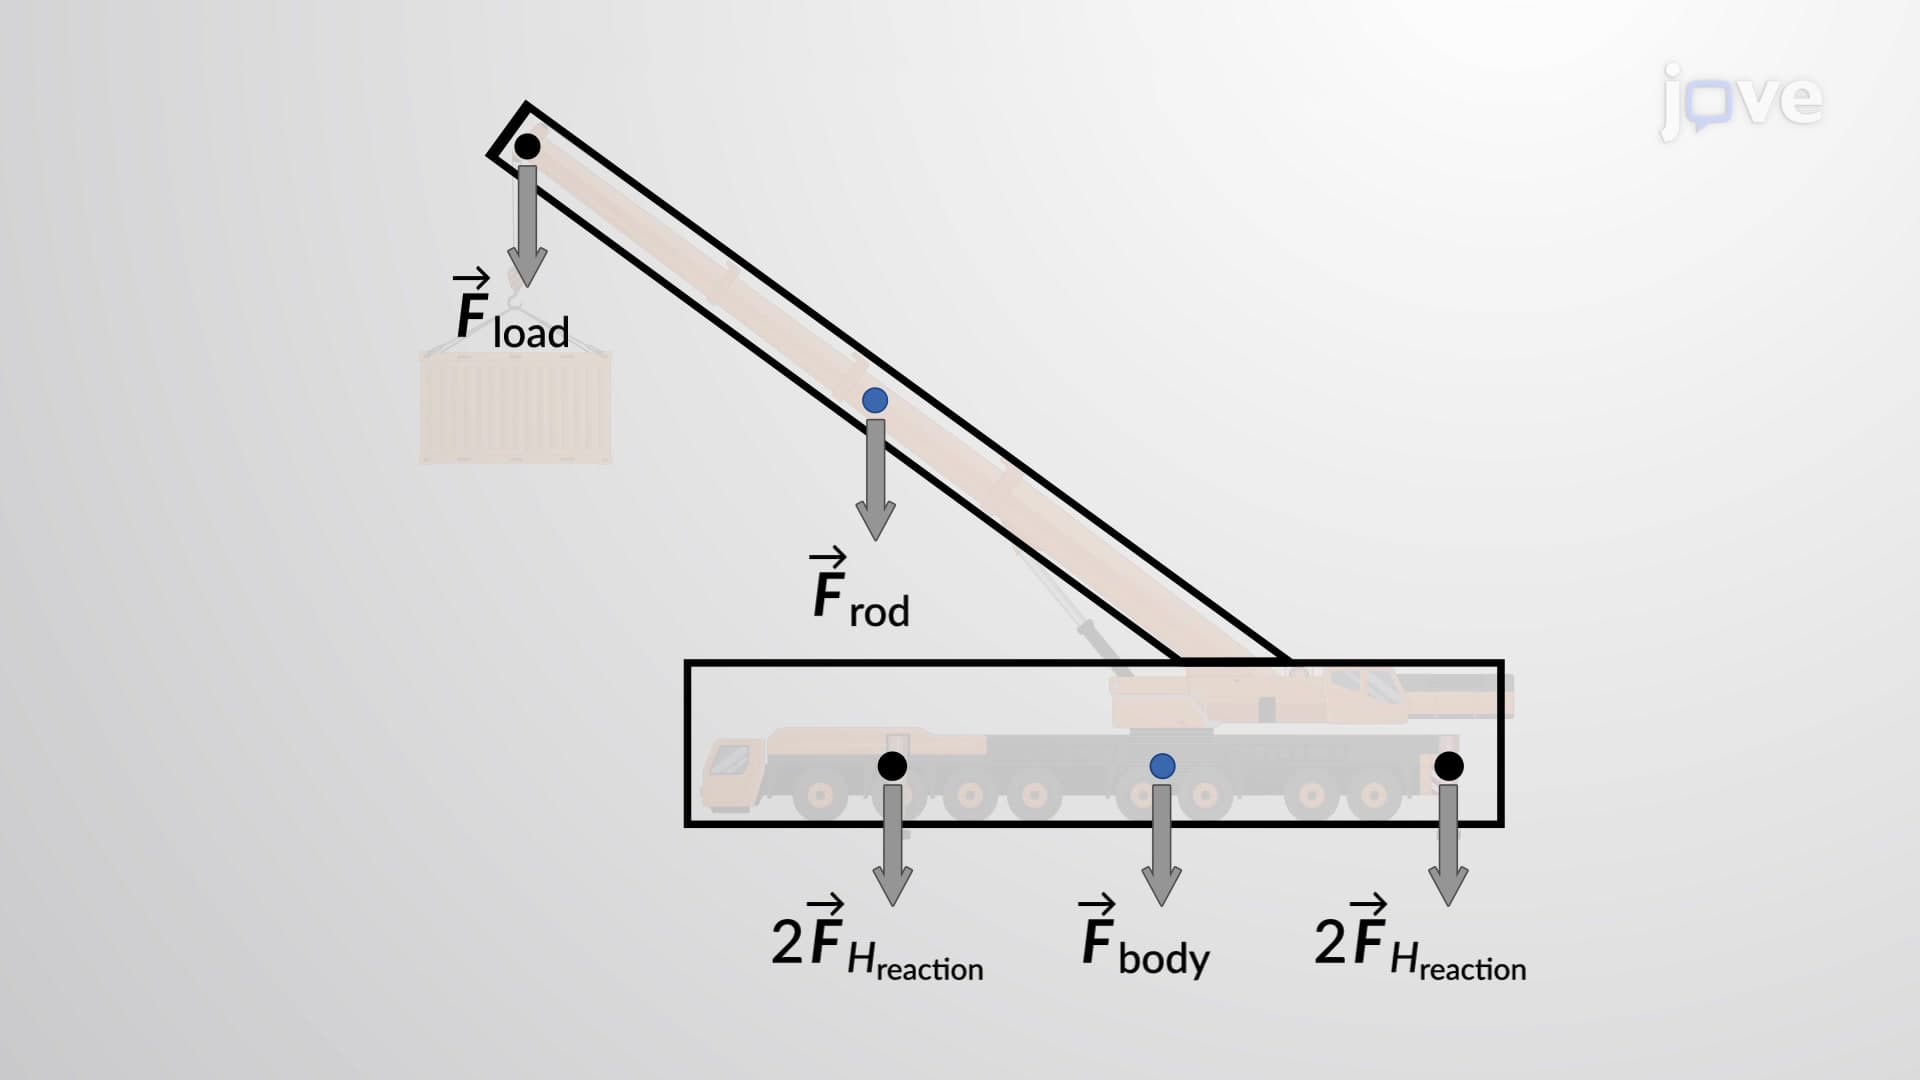
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?