
Null space-based control with gain modulation applied to a MARV in backward movement
Diego Nunes Bertolani1, Vinícius Pacheco Bacheti2, Mário Sarcinelli-Filho2
1Universidade Federal do Espírito Santo - UFES, Av. Fernando Ferrari, 514 - Goiabeiras, Vitória, 29075-910, Espírito Santo, Brazil; Federal Institute of Espírito Santo, IFES campus Guarapari, Alameda Francisco Vieira Simões, 720 - Aeroporto, Guarapari, 29216-795, Espírito Santo, Brazil(1).

Abstract:
A controller is proposed to guide a multi-articulated robot vehicle (MARV) moving backwards, following a certain path. The ability to avoid fixed and moving obstacles is included, using the null space-based control technique to manage the conflicting tasks of following a path and avoiding obstacles. Additionally, control gains are modulated, thus reducing the risk of jackknifing. These new approaches are the contributions of the article. Results of laboratory-scale experiments with a MARV pushing one and two trailers are presented and discussed, which validate the proposed controller. Simulation results are also presented considering a MARV with three trailers, showing that the proposed controller can be adopted for larger articulated chains and another experiment that shows that it is possible to avoid moving obstacles.
More Related Videos


Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
 01:21
Generator Voltage Control
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
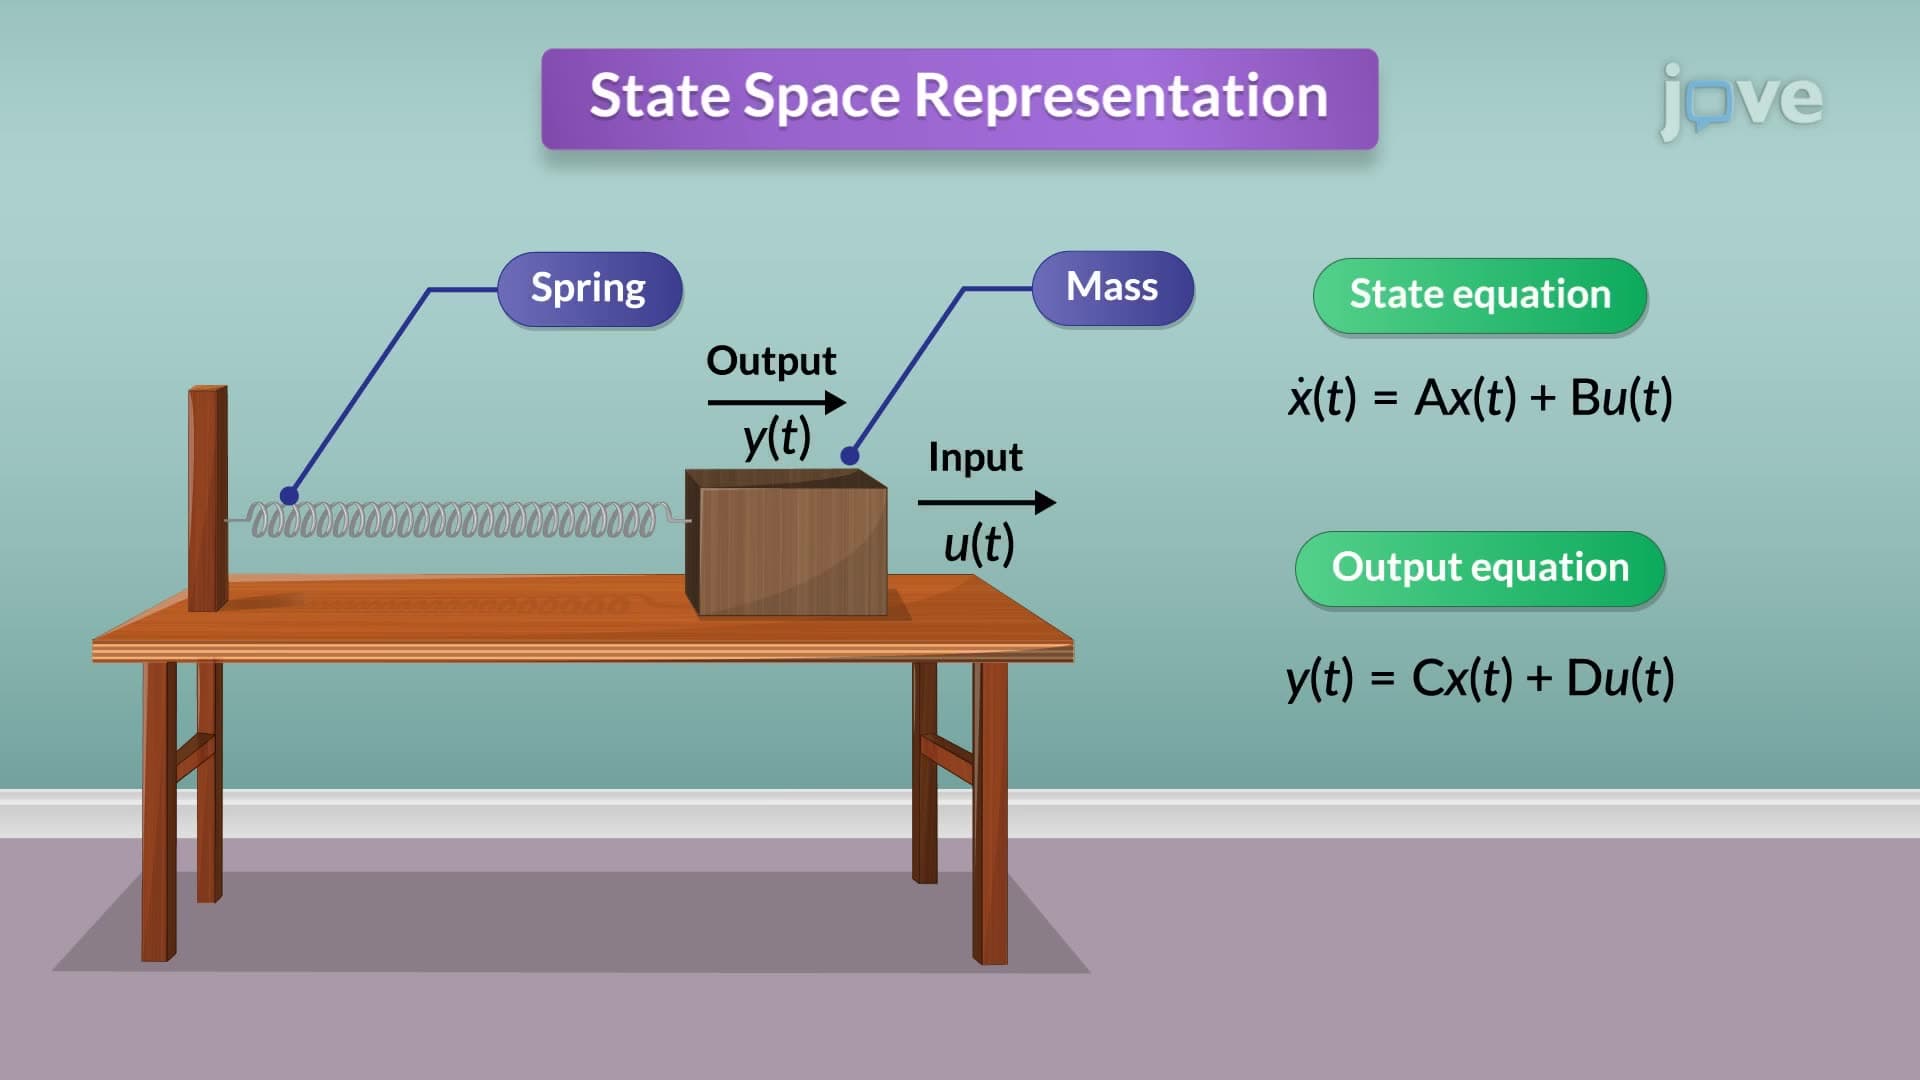
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:13
Linear Momentum in Control Volume