Related Experiment Video
Updated: Jun 21, 2025
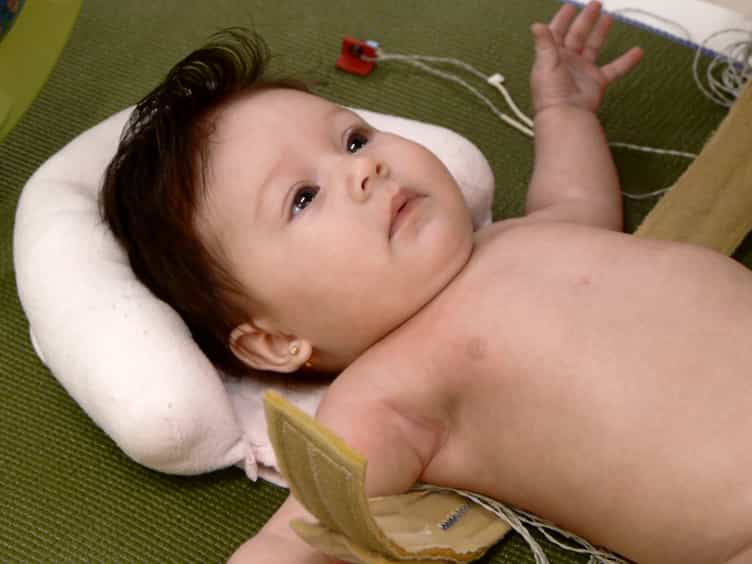

Quantifying Learning in Young Infants: Tracking Leg Actions During a Discovery-learning Task
Published on: June 1, 2015
Reaching While Learning to Sit: Capturing the Kinematics of Co-Developing Skills at Home
Jana M Iverson1, Emily R Britsch1, Joshua L Schneider1
1Department of Psychology, University of Pittsburgh, Pittsburgh, Pennsylvania, USA.

This study examined the co-development of infant reaching and postural control across the transition to arms-free sitting at home. We observed infants with typical likelihood (TL; n = 24) and elevated likelihood (EL; n = 20) for autism at four biweekly sessions spanning the transition to arms-free sitting (infant age = 4.5-8 months at first session). At each session, infants sat on a pressure-sensitive mat with external support or independently, wore magneto-inertial sensors on both wrists, and reached for toys presented at midline. Analyses focused on characterizing and comparing control of sitting during reaching actions and standard kinematic metrics of reaching during Supported versus Independent Sitting. Although EL infants achieved arms-free sitting later than TL peers, there were no group differences on any measures. Across sessions, infants' control of the sitting posture during concurrent reaching movements improved in both contexts, though they were less stable as they reached when sitting independently compared to when sitting with support. A similar effect was apparent in the kinematics of reaches, with overall improvement over time, but evidence of poorer control in Independent relative to Supported Sitting. Taken together, these findings underscore the mutually influential and dynamic relations between emerging skills and well-established behaviors.
This study examined the co-development of infant reaching and postural control across the transition to arms-free sitting at home. We observed infants with typical likelihood (TL; n = 24) and elevated likelihood (EL; n = 20) for autism at four biweekly sessions spanning the transition to arms-free sitting (infant age = 4.5-8 months at first session). At each session, infants sat on a pressure-sensitive mat with external support or independently, wore magneto-inertial sensors on both wrists, and reached for toys presented at midline. Analyses focused on characterizing and comparing control of sitting during reaching actions and standard kinematic metrics of reaching during Supported versus Independent Sitting. Although EL infants achieved arms-free sitting later than TL peers, there were no group differences on any measures. Across sessions, infants' control of the sitting posture during concurrent reaching movements improved in both contexts, though they were less stable as they reached when sitting independently compared to when sitting with support. A similar effect was apparent in the kinematics of reaches, with overall improvement over time, but evidence of poorer control in Independent relative to Supported Sitting. Taken together, these findings underscore the mutually influential and dynamic relations between emerging skills and well-established behaviors.
More Related Videos
Related Concept Videos
 01:15
Kinematic Equations: Problem Solving
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
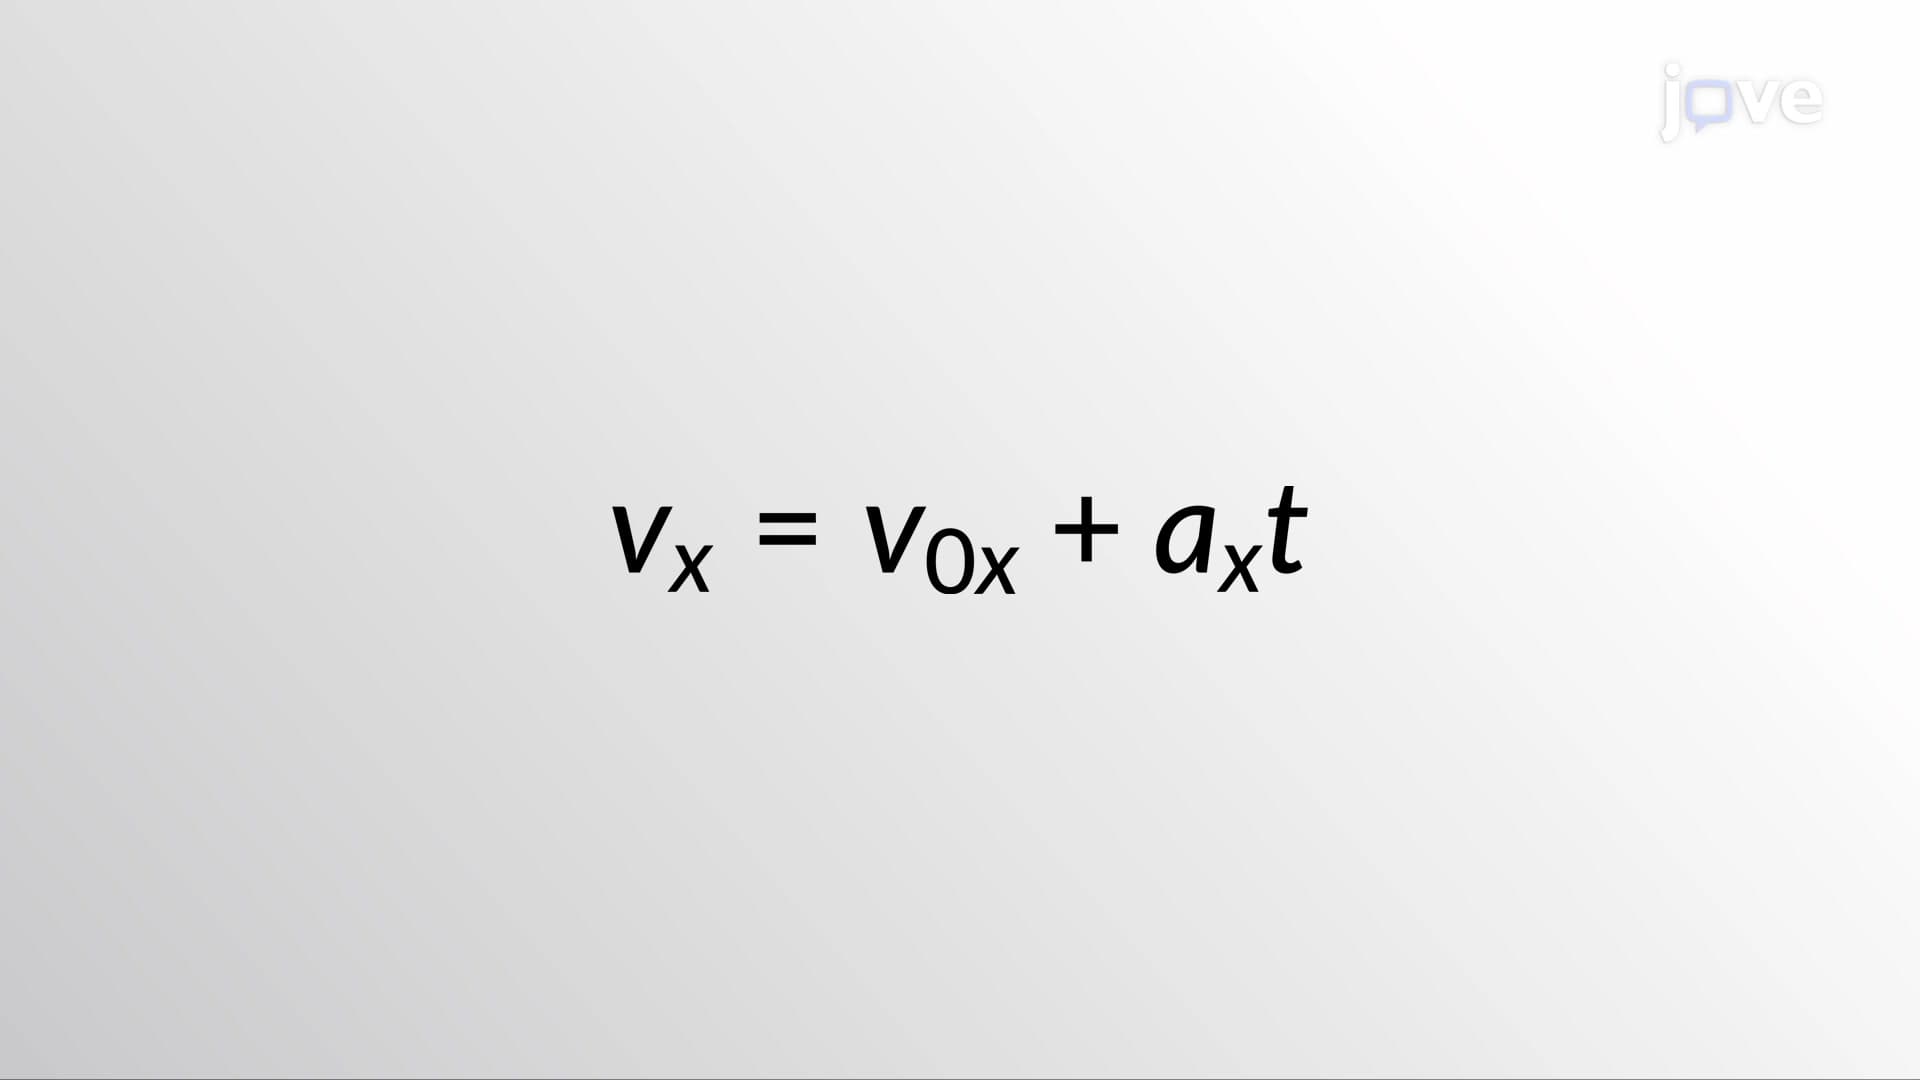 01:26
Kinematic Equations - I
 01:24
Normal and Tangetial Components: Problem Solving
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...