Related Experiment Video
Updated: Jul 21, 2026


Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
Multivariate analysis of the kinematics of an upper limb rehabilitation robot
Mariusz Sobiech1,2,3, Andrzej Michnik1,2,3, Iwona Chuchnowska2
11Łukasiewicz Research Network - Krakow Institute of Technology, Zabrze, Poland.

Abstract:
Purpose: The purpose of this work is to present a multivariate analysis of the kinematics of an upper limb rehabilitation robot. Comparing multiple concepts of kinematic chains makes it possible to identify advantages and disadvantages and, as a consequence, choosing the optimal solution to create a physical device. Such actions shall contribute towards automation of the rehabilitation process, bringing benefits to both therapists and patients in comparison with conventional rehabilitation. Methods: Multivariate analysis of kinematics was performed on the basis of three concepts of the kinematic chain of an exoskeleton, enabling the rehabilitation of both right and left upper limb within the area of the shoulder joint, elbow joint and wrist. The kinematic chain allows the performance of simple and complex movements. Results: The results of the conducted multivariate kinematic analysis define specific movements and angular ranges, which may be performed while applying one of the proposed concepts of the robot design. The results made it possible to determine the optimum solution to the kinematic diagram and construction design, which best satisfy the expectations for effective rehabilitation. Conclusions: The analysis of the kinematic diagram concept of the exoskeleton should be done in relation to its design (construction form). Considering the obtained parameters, it is necessary to find an optimum concept and wisely manoeuvre the values, in order to avoid a situation in which one significant parameter influences another, equally important one. It is noteworthy that the introduction of changes into particular segments of the kinematic chain often has a significant impact on other segments.
More Related Videos
 05:25
Author Spotlight: Assessing Brain Activity in Robotic-Assisted Lower Limb Rehabilitation Using fNIRS
Published on: June 7, 2024
 04:49
Author Spotlight: Enhancing Post-Stroke Upper Limb Rehabilitation with Robotic Technologies for Improved Motor Recovery and Functional Outcomes
Published on: September 6, 2024
Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:14
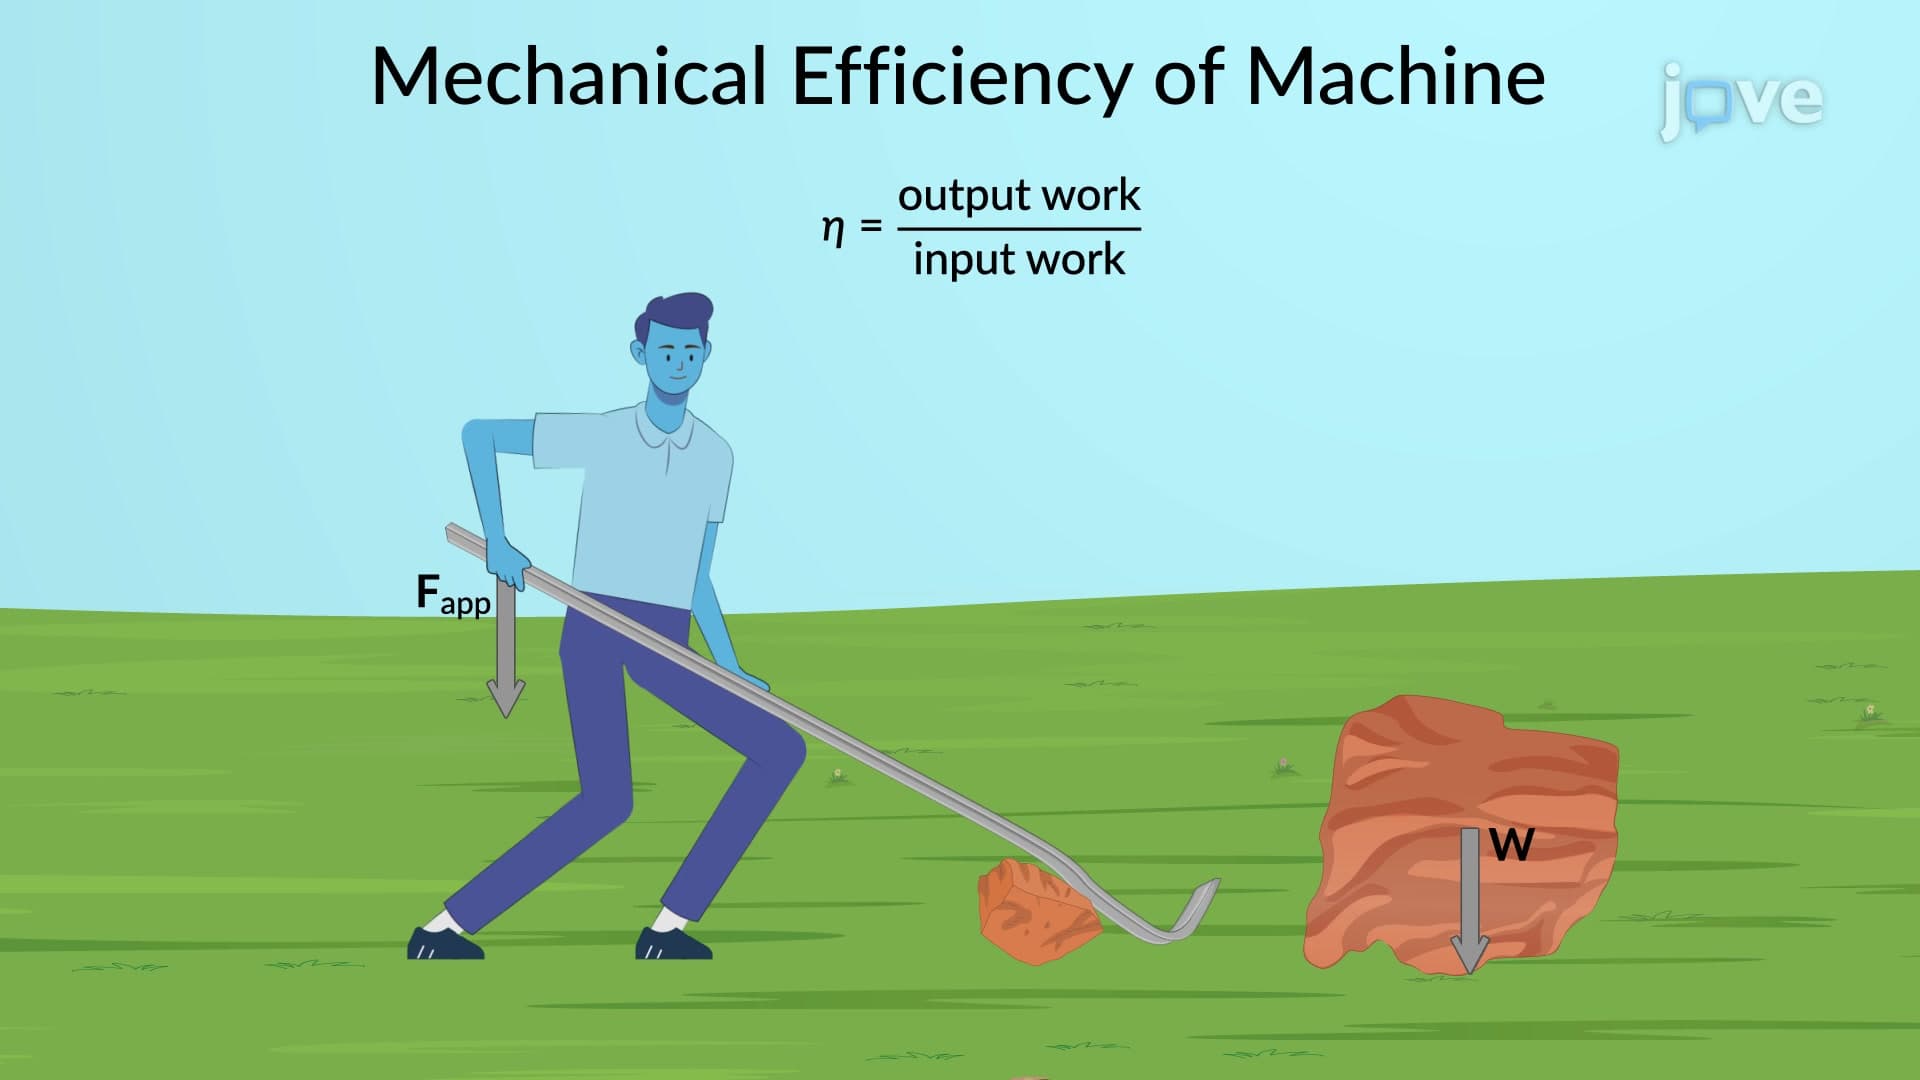
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:23
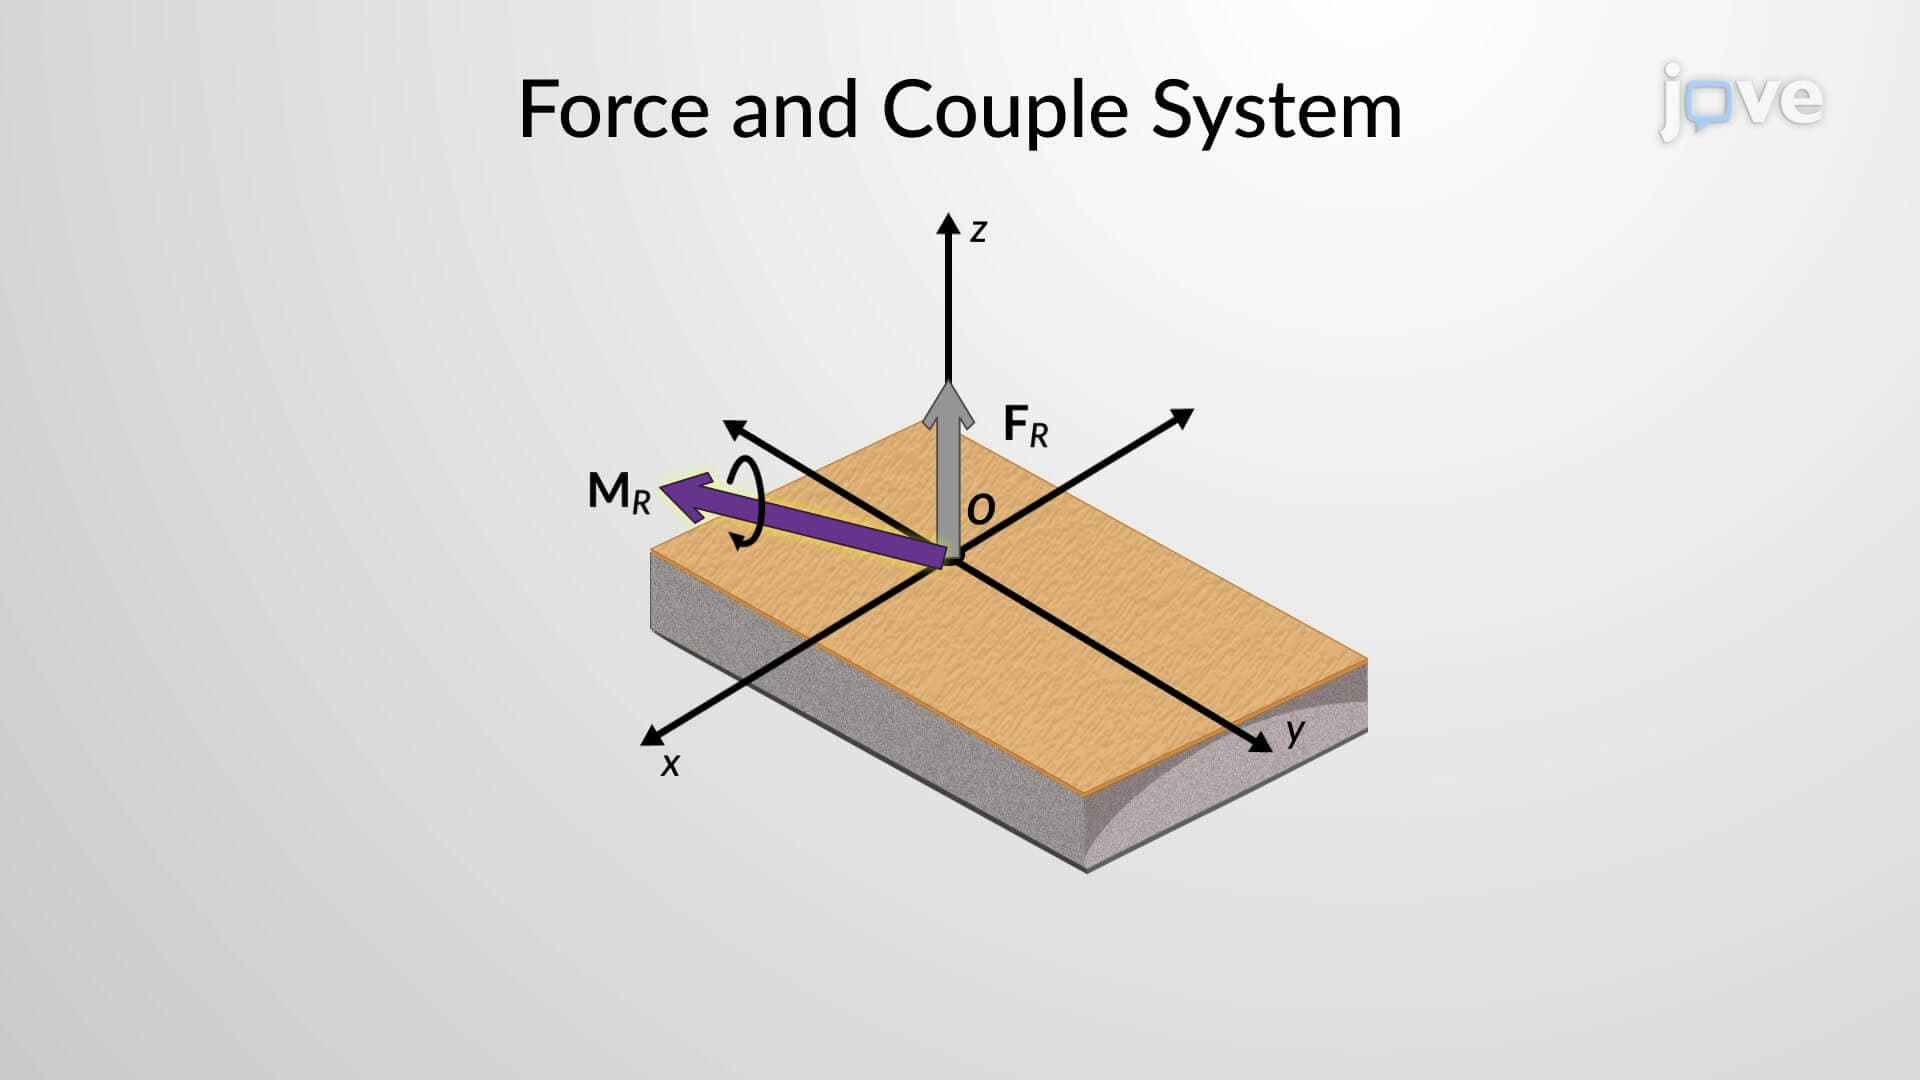
Simplification of a Force and Couple System: II
 01:19
Machines
A free-body diagram of the...
 01:30
Machines: Problem Solving II
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by: