Related Experiment Video
Updated: May 5, 2026


Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
Electrohydraulic musculoskeletal robotic leg for agile, adaptive, yet energy-efficient locomotion
Thomas J K Buchner1, Toshihiko Fukushima2, Amirhossein Kazemipour1
1Soft Robotics Lab, D-MAVT, ETH Zurich, 8092, Zurich, Switzerland.

Abstract:
Robotic locomotion in unstructured terrain demands an agile, adaptive, and energy-efficient architecture. To traverse such terrains, legged robots use rigid electromagnetic motors and sensorized drivetrains to adapt to the environment actively. These systems struggle to compete with animals that excel through their agile and effortless motion in natural environments. We propose a bio-inspired musculoskeletal leg architecture driven by antagonistic pairs of electrohydraulic artificial muscles. Our leg is mounted on a boom arm and can adaptively hop on varying terrain in an energy-efficient yet agile manner. It can also detect obstacles through capacitive self-sensing. The leg performs powerful and agile gait motions beyond 5 Hz and high jumps up to 40 % of the leg height. Our leg's tunable stiffness and inherent adaptability allow it to hop over grass, sand, gravel, pebbles, and large rocks using only open-loop force control. The electrohydraulic leg features a low cost of transport (0.73), and while squatting, it consumes only a fraction of the energy (1.2 %) compared to its conventional electromagnetic counterpart. Its agile, adaptive, and energy-efficient properties would open a roadmap toward a new class of musculoskeletal robots for versatile locomotion and operation in unstructured natural environments.


Related Concept Videos
 01:23
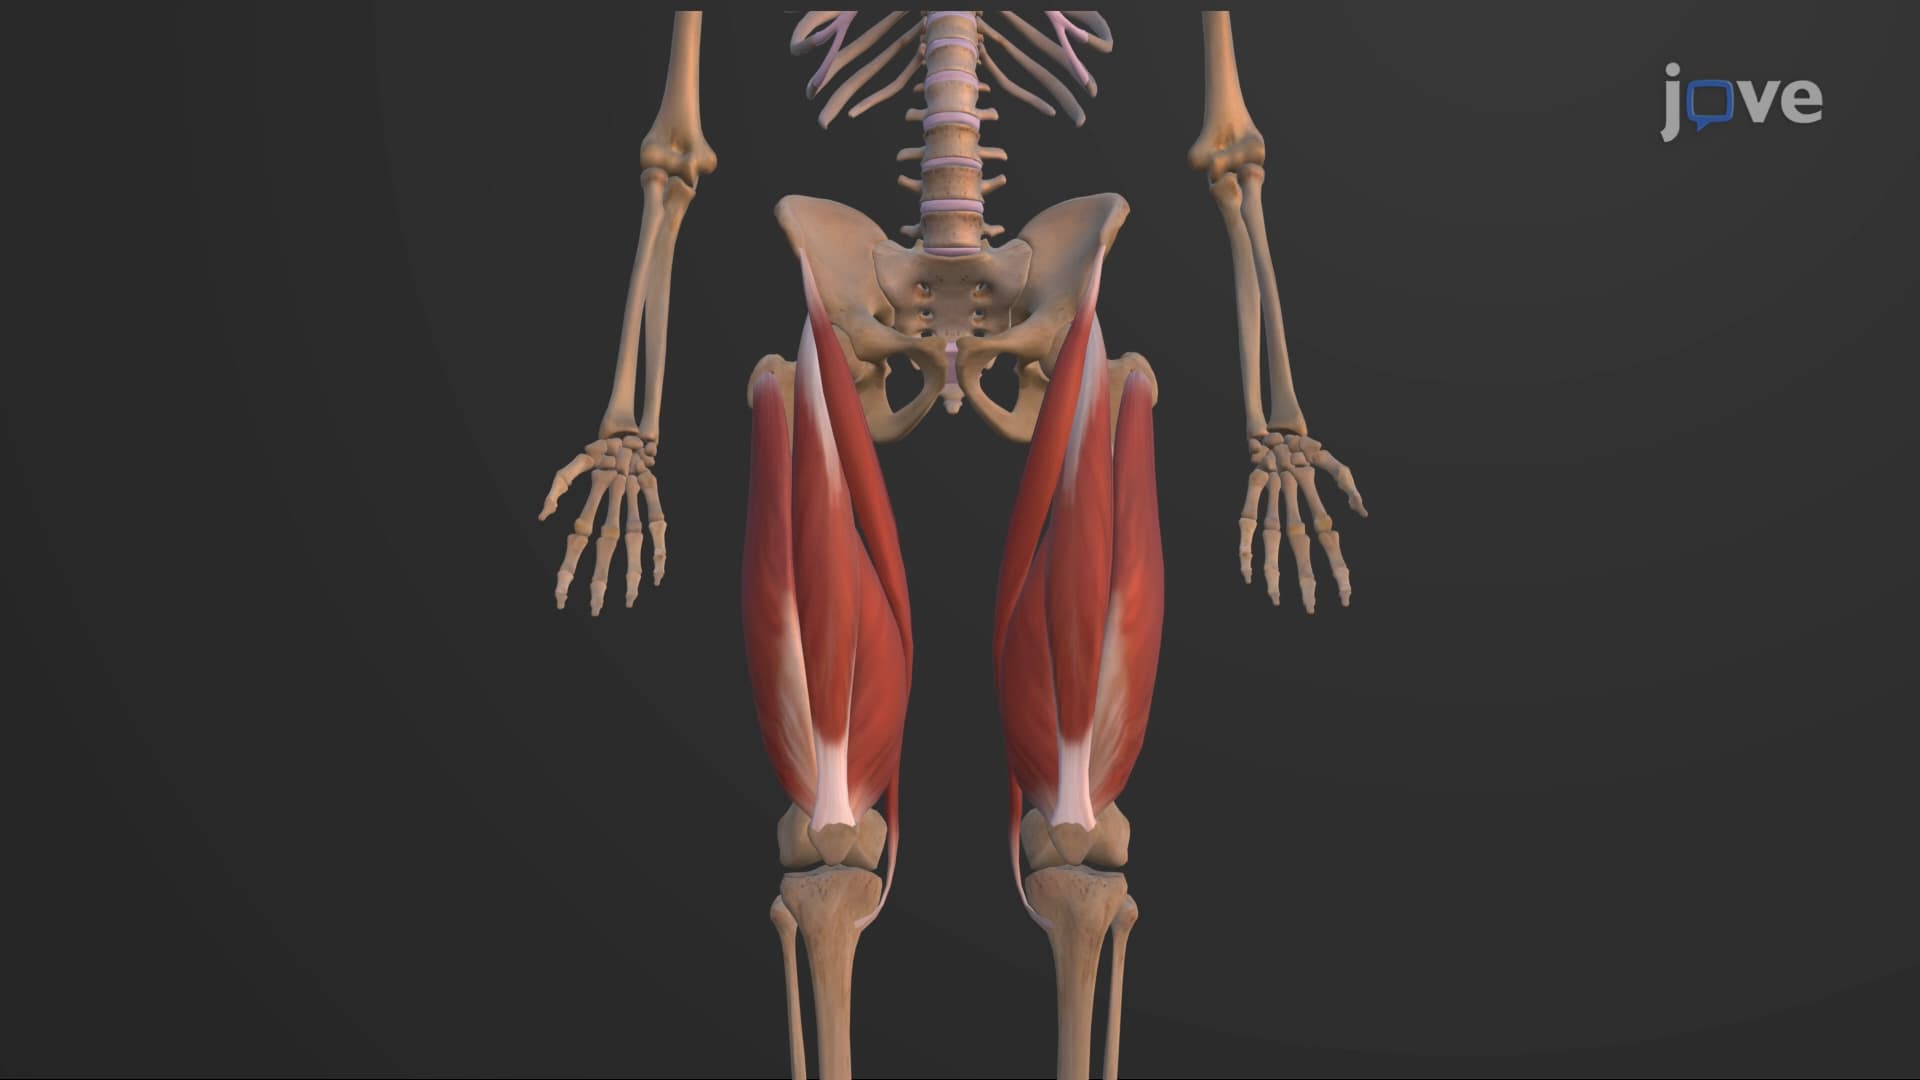
Muscles that Move the Leg
Anterior Compartment
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed...
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...